ETH Zurich logoETH Zurich

Faive Hand

Price
Unknown
Type
Components · Dexterous Hands
Status
Prototype
Availability
Not released
Release Date
Unknown
Country/Region
Switzerland
Latest parameter verification
2026-10-31
11 DoF
Active degrees of freedom
16
Mechanical joint count
1.1 kg
Hand weight
5
Finger count

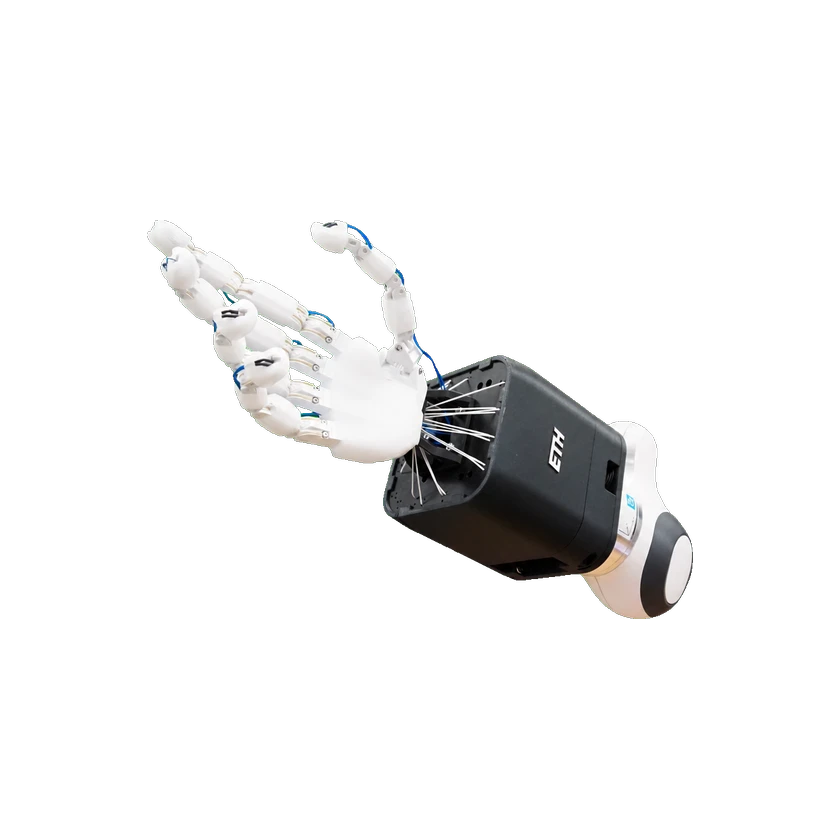
FAIVE Hand is a five-finger tendon-driven robotic hand developed by the Soft Robotics Lab at ETH Zurich. The research configuration has 11 actuated degrees of freedom and 16 joints, driven by 16 Dynamixel servomotors at the wrist. Crossed ligament strings constrain its rolling-contact joints, while low-level control estimates joint angles from tendon lengths. The researchers trained an in-hand sphere-rotation policy in simulation and transferred it to physical experiments, combining mechanism modelling with reinforcement learning.

1 / 1FAIVE Hand

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator count
16
Actuator technology
Dynamixel servo motors
Active degrees of freedom
11 DoF
Mechanical joint count
16
Soft Padding
Silicone padding
Transmission mechanism
Tendon drive
Actuator Model
Dynamixel XC330-T288-T

Mobility & Payload

Hand Payload
Up to 10 kg

Mechanical and mounting

Hand weight
1.1 kg

The original Proto 0 paper reports 1.1 kg for the total hand system. This is not a measured weight for the later ICRA 2024 sensorized-skin setup; that paper does not give its total hand weight.

Mechanical Structure

Joint Encoder
No internal joint-angle encoders (Proto 0)
Joint Sensor Type
Tendon-length measurements with extended Kalman filter estimation
Joint Type
Rolling-contact joints
Joint Type
Two hinge joints at the thumb carpometacarpal joint

Sensors

Sensors
Tendon-length measurements

Compute Platform

Software Algorithm
Reinforcement learning with A2C

Development and Expansion

Integration Interface
Isaac Gym / IsaacGymEnvs
Secondary Development (SDK)
faive_gym

Configurations

FAIVE Hand — ICRA 2024 sensorized-skin experiment

Sensing

Has tactile sensing
Supported

ICRA 2024 research setup: piezoresistive sensors and cast silicone skin added to the FAIVE hand. This does not establish tactile sensing on every Proto 0 hand or a standard delivery SKU. The 20 Hz rate is the experimental ADC readout of the tactile sensors, not hand-control frequency.

Tactile configuration
46 piezoresistive pressure sensors on fingers and palm, beneath cast silicone skin; experimental ADC readout at 20 Hz.

ICRA 2024 research setup: piezoresistive sensors and cast silicone skin added to the FAIVE hand. This does not establish tactile sensing on every Proto 0 hand or a standard delivery SKU. The 20 Hz rate is the experimental ADC readout of the tactile sensors, not hand-control frequency.

Commercial Status

Status
Prototype
Price
Unknown
Release Date
Unknown
Submit a source or correction