DOBOT Robotics logoDOBOT Robotics

PULSA

Price
Price not disclosed
Type
Robot Arms · Single Arm
Status
Commercial
Availability
Not disclosed
Release Date
Oct 12, 2026
Country/Region
China
91 cm
Reach
±0.02 mm
Repeatability
44 kg
Weight

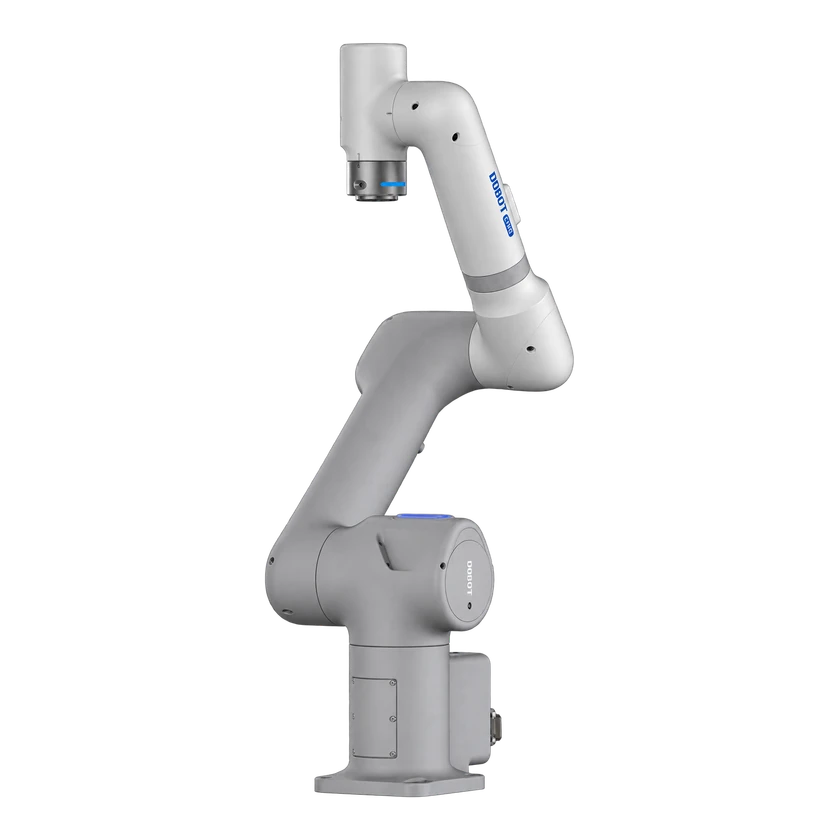
PULSA 7 is DOBOT’s six-axis industrial collaborative arm for high-cycle production. Rated payload is 7 kg, reach is 910 mm, and repeatability is ±0.02 mm. The sixth axis reaches 790°/s. The arm supports mounting at any angle and routes air and I/O internally.

PULSA 7

Configurations

Factory specifications

Mechanical and mounting

Components included in weight
Robot arm body

Communication and control

Communication interface
Ethernet

hpc1026

Communication interface
RS485

hpc1026

Communication interface
USB

hpc1026

Communication interface
ABZ

hpc1026

Communication protocol
TCP/IP

hpc1026

Communication protocol
Modbus TCP

hpc1026

Communication protocol
EtherNet/IP

hpc1026

Communication protocol
PROFINET

hpc1026

Communication protocol
Modbus RTU

hpc1026

Hardware Specification

Physical specifications and power

Mounting or wearing method
Any angle

Degrees of freedom and drive

Ingress Protection (IP)
Robot arm body · IP67
Ingress Protection (IP)
HPC1026 Control cabinet · IP20
Ingress Protection (IP)
HPC1026 Control cabinet · IP54 (optional)
Mechanical joint count
6
Materials
Aluminum alloy

Mobility & Payload

Single-arm Payload
7 kg
Reach
91 cm

Mechanical and mounting

Weight
44 kg

Mechanical Structure

Internal Wiring
4 × Ø4 mm air tubes and 12-pin I/O, routed from J1 to J4
Joint Motion Range
-180° – 180°
Joint Motion Range
-165° – 165°
Joint Motion Range
-160° – 160°
Joint Motion Range
-200° – 200°
Joint Motion Range
-360° – 360°
Joint Motion Range
-360° – 360°
Operating voltage
Control cabinet · 220–240 V

Battery and Runtime

Power Supply
HPC1026 Control cabinet · 24 V; 3 A total maximum; 0.5 A maximum per channel

Performance and tasks

Repeatability
±0.02 mm

Reliability and environment

Operating temperature
0–50 °C
Safety System
High-speed and safe operation modes; ISO 13849-1 PL d, Category 3

Interaction and Communication

External Port
2 DI, 2 DO, 2 AI (shared with RS485)

Development and Expansion

Configuration Options
Arm-to-cabinet cable: 5 m standard, 10 / 15 / 20 m optional
Graphic Programming
Graphical block programming
Integration Interface
HPC1026 Control cabinet · 24 DI and 24 DO (NPN/PNP); 2 analog inputs (0–10 V or 4–20 mA)
Integration Interface
16 safety inputs and 16 safety outputs(PULSA series, confirm HPC1026 applicability)
Integration Interface
HPC1026 Control cabinet · One ABZ incremental encoder port
Integration Interface
HPC1026 Control cabinet · Two USB ports
Integration Interface
HPC1026 Control cabinet · PC, Android app or teach pendant

Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Oct 12, 2026

Timeline

  1. Robot release
    PULSA 7
Submit a source or correction