
Robot Data Collection Systems
Explore source-backed systems for robot demonstration, teleoperation, motion capture, and training-data collection.
Showing 2 robot data collection systems models
| Component | Organization | Country | Device form factor | Collection method | Captured data | Robot required during capture | Actions |
|---|---|---|---|---|---|---|---|
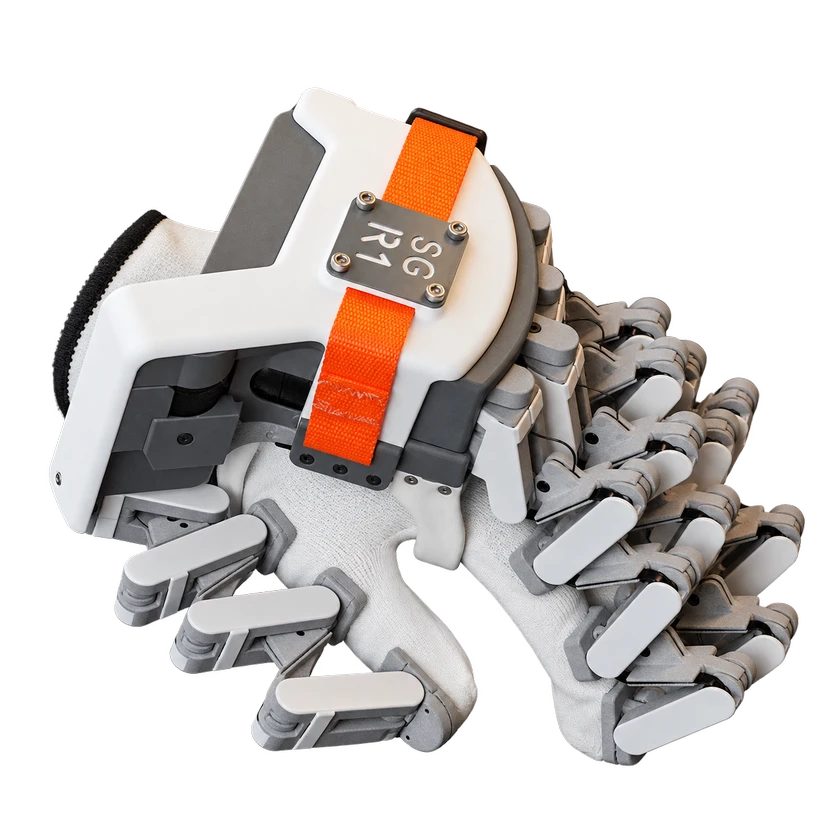 SenseGlove R1SenseGlove R1 | SenseGlove | Netherlands | Hand wearable | Teleoperation | Force feedback · Pressure | Depends on configuration | |
 DOGloveDOGlove | Tsinghua University | — | Hand wearable | Human demonstration · Teleoperation | Hand motion · Force feedback | Depends on configuration |
Submit a source or correction