
Standard
Communication and control
Communication interface
CAN
Communication protocol
CAN
Control mode
Torque-controlled
Sensing
Proprioceptive feedback
Potentiometer
 Wonik Robotics
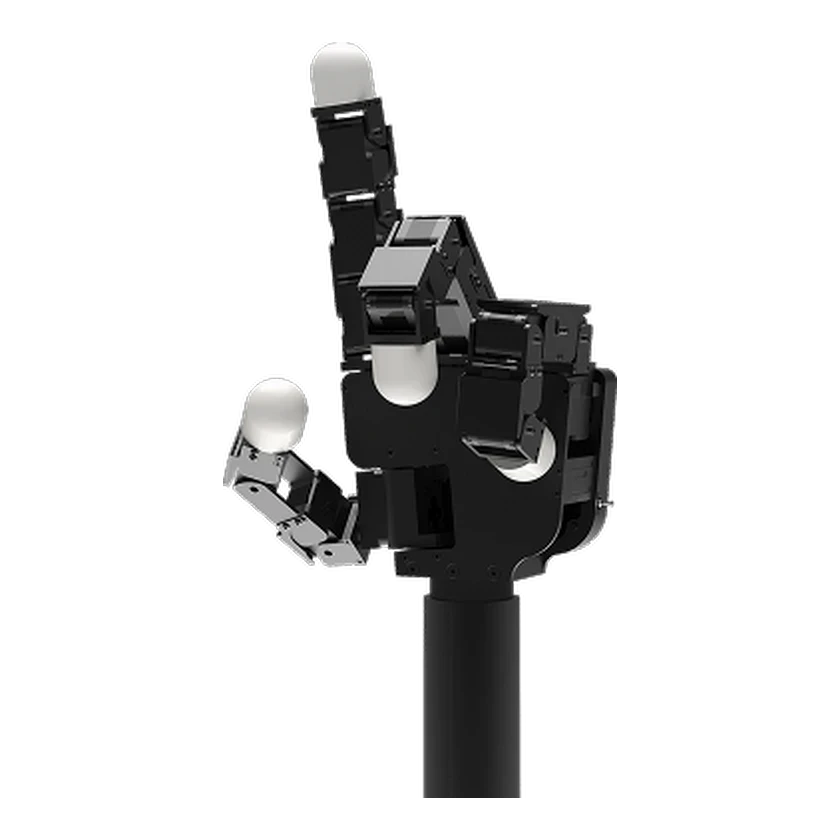
 Allegro Hand V4 is an anthropomorphic dexterous hand for research and industrial grasping. It has four fingers, 16 independent torque-controlled joints, DC-motor actuation, CAN communication, 24 V and 100 W power requirements, and ready-to-use grasping algorithms.
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
No related products recorded yet.