Shadow RobotShadow Dexterous Hand
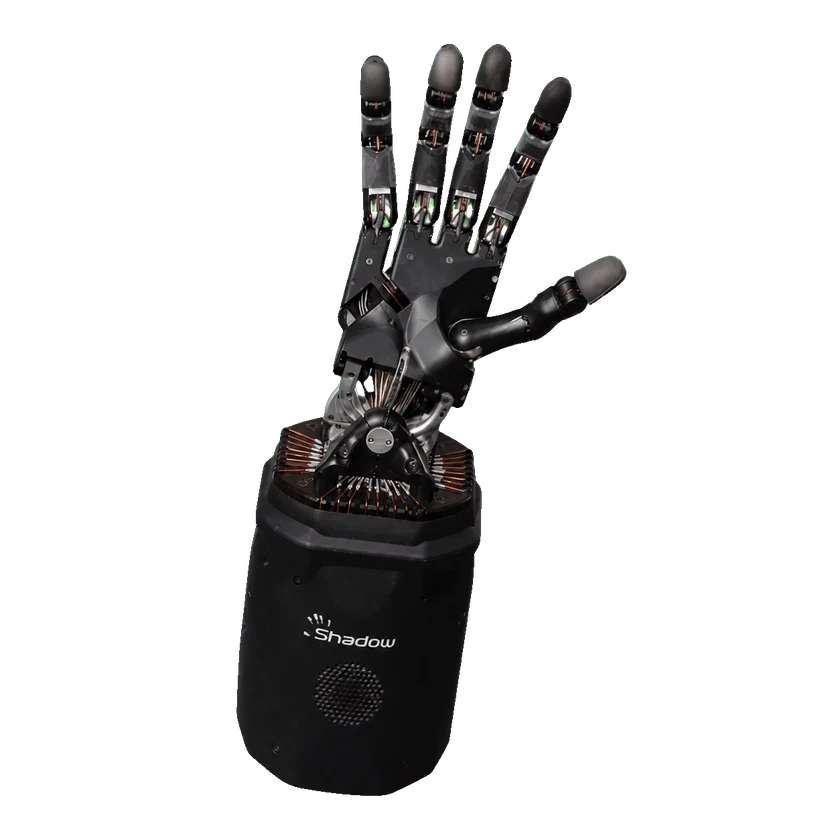
Shadow Dexterous Hand is a five-finger research hand with 20 active degrees of freedom and 24 joints, including two wrist joints. Twenty DC motors drive tendons. The hand and forearm weigh 4.3 kg. EtherCAT, ROS integration and tactile fingertips support manipulation research.

Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Degrees of freedom and drive
Official source: No. of Actuators 20 DC motors
Under-actuated movements; coupled distal finger joints.
Manufacturer reports 24 degrees of freedom, including 20 actuated degrees and four under-actuated movements.
Mechanical and mounting
Communication and control
Official source: Control loop rate through host 1kHz (EtherCat protocol)
Software and resources
Official source: Fully ROS integrated, for use as a research and development tool and as testing hardware for AI and Machine Learning.
Sensing
Official source: Multiple tactile sensing options A range of different finger tactile tips are available depending on your dexterity needs
Official source: Shadow Tactile Fingertip (STF) fitted as standard in some fingertips with the option to upgrade to more.
Configurations
Open source & build resources
Software
Partially availableExamples or supporting tools are available; this does not establish access to the core system.
Hardware design
Not verifiedThere is not enough verified evidence to establish this dimension.
Build resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Simulation | Shadow Dexterous Hand official robot-description and simulation assets GitHub · shadow-robot/sr_common Official robot model files for visualization and simulation. Select the matching variant and configuration; model assets do not establish that manufacturing drawings or the complete onboard system are published. | BSD-3-Clause | Shadow Dexterous Hand | Open GitHub |