Price
Unknown
Type
Mobile Manipulators
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
2023
Country/Region
China
Last Verified
2026-10-13
800 kg
Weight

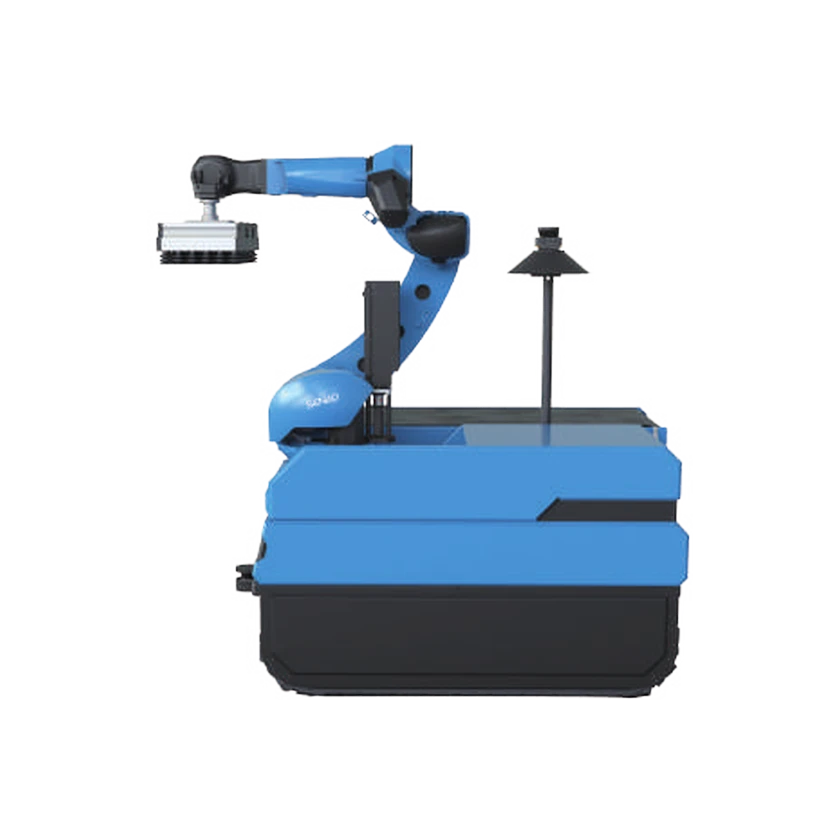
iLoabot-M is a SENAD tracked autonomous loading and unloading robot combining 3D vision, LiDAR and structured-light navigation. The default arm supports cargo weights of 2–35 kg. It handles containers and box trucks, mobile unstacking, sorting and palletizing, with low-code workflow configuration and warehouse-system integration.

1 / 1iLoabot-M

Hardware Specification

Physical Specifications

Locomotion Type
Differential tracked drive

Mobility & Payload

Single-arm Payload
≤35 kg

Mechanical and mounting

Weight
800 kg

Mechanical Structure

End-Effector
Interchangeable fixtures compatible with boxed and bagged goods

Sensors

Sensors
LiDAR; structured light
Vision Sensor
3D machine vision

Battery and Runtime

Power Supply
External AC power supply, 220–240 V

Reliability and environment

Operating temperature
-20–60 °C

Interaction and Communication

Smart Navigation
Integrated LiDAR and structured-light navigation; SLAM and path planning

Development and Expansion

Integration Interface
WMS; WCS
Workflow Integration
Low-code delivery platform with flexible workflow configuration

Commercial Status

Status
Unknown
Price
Unknown
Release Date
2023

Deployment records

Progress, changes and sources from real-world projects.

Partner
Mitsui Bussan Global Logistics Co., Ltd. · Operator
Scenario
Warehouse & Logistics
Primary task
Autonomously load and unload freight in consumer-goods logistics, including mixed-SKU and irregularly stacked cargo.
Location
A Mitsui Bussan Global Logistics warehouse in Chiba, Japan; the specific facility is undisclosed.
Started
2026-05
Last verified
2026-10-13

Deployment timeline · 1

  1. iLoabot-M enters daily warehouse operations at Mitsui Global Logistics in Chiba
As of the verified evidence; this is not live operating status.2026-10-13

Timeline

  1. Robot release
    iLoabot-M
Submit a source or correction