

 Robotis
DYNAMIXEL-Q
Price
Unknown
Type
Components · Integrated Joints
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
South Korea
- Outer diameter
- 78 mm
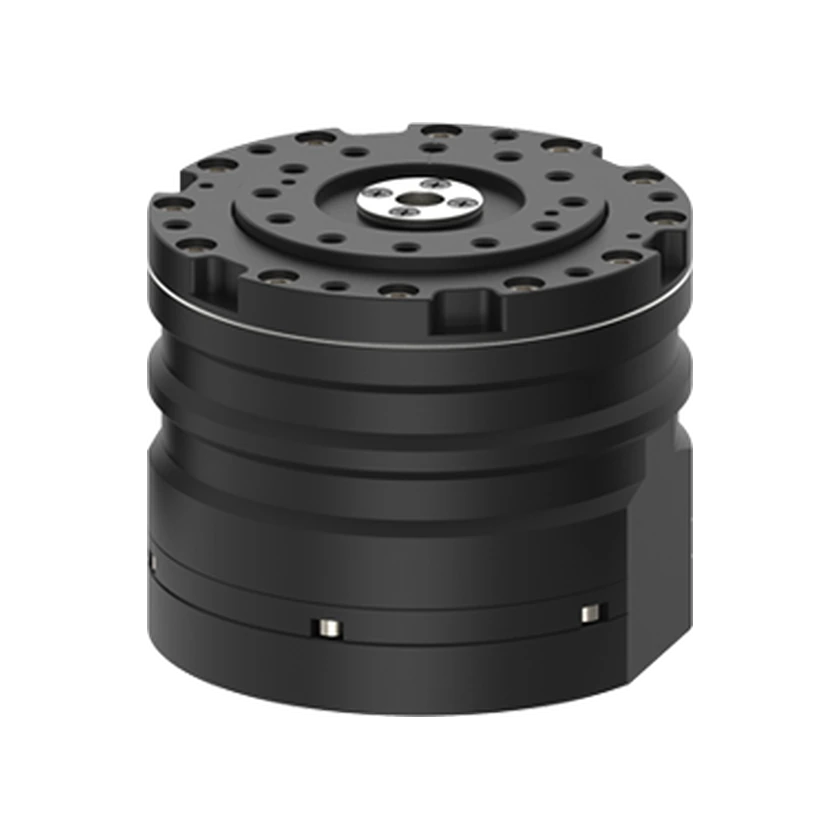
The QM-080 is an integrated quasi-direct-drive joint in the ROBOTIS DYNAMIXEL-Q family. It uses an inner-rotor motor and a 48 V input. ROBOTIS lists a 78 mm outer diameter, 65 mm axial length, 850 g mass and a 7 mm hollow bore. The AI Sapiens K0 uses nine units. ROBOTIS lists 12:1, 16:1 and 20:1 ratios for the QM-080.
Technical specifications
Dimensions & installation
- Outer diameter
78 mm
Scope not bound
- Axial length
65 mm
Scope not bound
- Hollow bore diameter
7 mm
Scope not bound
Construction & components
- Motor type
Inner rotor
Scope not bound
- Motor integration
Integrated
Scope not bound
- Reducer integration
Integrated
Scope not bound
- Controller integration
Integrated
Scope not bound
Model-level records · configuration applicability unverified
- Weight
- 0.85 kg
- Gear Ratio
- 12:1
- Gear Ratio
- 16:1
- Gear Ratio
- 20:1
- Joint Type
- Quasi-direct drive (QDD)
- Operating voltage
- 48 V
Source · 1
ai.robotis.com
2026-11-22
Axial length · Ø78 x 65 mm · Specification / Actuators / QM-080
Hollow bore diameter · Ø7 mm · Specification / Actuators / QM-080
Controller integration · integrated control electronics · Specification / Actuators / QM-080
Motor integration · high-torque motor · Specification / Actuators / QM-080
Reducer integration · low gear reduction ratio · Specification / Actuators / QM-080
Motor type · Inner Rotor · Specification / Actuators / QM-080
Outer diameter · Ø78 x 65 mm · Specification / Actuators / QM-080
Weight · 850 g
Gear Ratio · 12:1 / 16:1 / 20:1
Joint Type · QDD (Quasi-Direct Drive)
Operating voltage · 48 V
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | QC050-110-R025-RE25:1 configuration | QC060-200-R020-RE20:1 preview |
|---|---|---|
| Weight · Manufacturer reported | 0.25 kg | — |
| Operating voltage · Supported point | 48 V | — |
| Communication interface · Manufacturer reported | RS-485 multidrop bus | — |
| Communication protocol · Manufacturer reported | Digital packets | — |
| Communication protocol · Manufacturer reported | Proprietary | — |
| Backlash | ≤10 arcmin | — |
| Outer diameter · Manufacturer reported | 46 mm | — |
| Output speed · Continuous | 120 rpm | — |
| Output speed · No load | 240 rpm | — |
| Output torque · Continuous | 2.5 N·m | — |
| Output torque · Maximum | 8 N·m | — |
| Communication interface | — | RS-485Scope not bound |
| Communication protocol | — | Digital packetsScope not bound |
| Communication protocol | — | Asynchronous serial (8N1)Scope not bound |
| Backlash · Less than | — | <10 arcminScope not bound |
| Outer diameter | — | 58 mmScope not bound |
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Products related to “QM-080”
Related robots
Submit a source or correction