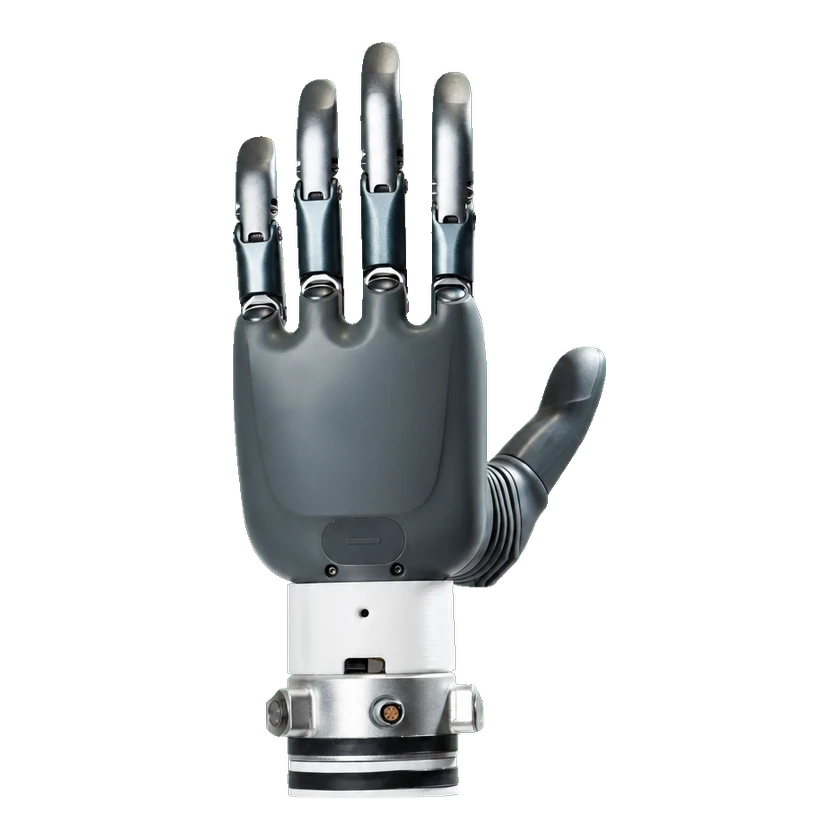
Revo 1 Basic
Communication and control
Current official specification for Basic MRL1/MRR1 and Basic Touch MTL1/MTR1; complements the RS485 interface documented in the older manual.
BrainCoRevo 1 Basic is BrainCo’s five-finger anthropomorphic hand configuration with 6 active joints and passive joints forming 10 total degrees of freedom; the official maximum whole-hand payload is 30 kg. Position and current feedback and RS485 commands support finger flexion, thumb-opposition adjustment and grasp holding. Official SDKs and examples support robotic hand-control development, while the basic configuration excludes the tactile version’s fingertip sensing modules.

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Current official specification for Basic MRL1/MRR1 and Basic Touch MTL1/MTR1; complements the RS485 interface documented in the older manual.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | Revo1 C++ SDK examples GitHub · BrainCoTech/brainco-hand-sdk Official SDK examples for Revo1 Basic and Touch. The example repository uses MIT; separately downloaded SDK libraries and dependencies may have their own terms. Match communication protocol and firmware to the device. Embedded hand firmware and hardware manufacturing files are not covered. | MIT | Revo1 Basic | Open GitHub |
| Code | Revo1 Python SDK examples GitHub · BrainCoTech/brainco-hand-sdk Official SDK examples for Revo1 Basic and Touch. The example repository uses MIT; separately downloaded SDK libraries and dependencies may have their own terms. Match communication protocol and firmware to the device. Embedded hand firmware and hardware manufacturing files are not covered. | MIT | Revo1 Basic | Open GitHub |