qbrobotics logoqbrobotics

qb SoftHand Research

Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
Italy
Latest parameter verification
2026-10-30
1 DOF
Active degrees of freedom
19
Mechanical joint count
0.77 kg
Hand weight
5
Finger count

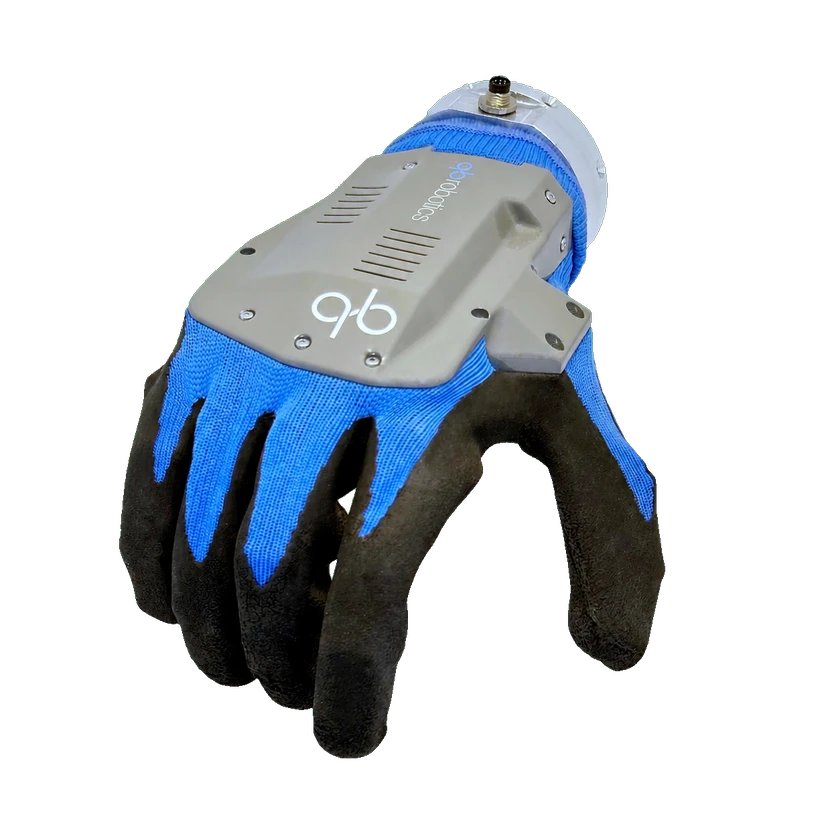
qb SoftHand Research is a five-finger adaptive hand with one motor, 19 mechanical degrees of freedom and tendon transmission. It weighs 0.77 kg and supports USB and RS485.

1 / 1qb SoftHand Research

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator count
1
Active degrees of freedom
1 DOF
Mechanical joint count
19
Total degrees of freedom
19 DOF

Official source: 19 anthropomorphic DOFs, one synergy, one motor

Transmission mechanism
Tendon transmission

Motion and coordination

Synergy count
1

Official source: 19 anthropomorphic DOFs, one synergy, one motor

Mechanical and mounting

Depth
71 mm

Official user manual, technical-dimensions drawing.

Height
242 mm

Official user manual, technical-dimensions drawing.

Length
191 mm

Official user manual, technical-dimensions drawing.

Mounting interface
Ø50, 4 holes Ø6H7, 4 Ø6.4 through-holes, Ø63H7

Official user manual, technical-dimensions drawing.

Hand weight
0.77 kg
Width
56 mm

Official user manual, technical-dimensions drawing.

Communication and control

Communication interface
USB / RS485
Feedback signals
motor position, motor current

Official source: Feedback: motor position and motor current

Software and resources

CAD availability
STL, STEP

Official source: CAD - STL CAD - STEP

ROS compatibility
ROS, ROS2

Official source: ROS ROS2 compatible

SDK languages
C++

Official source: C++ API Library

Performance and tasks

Open-close time
1.1

Official source: From wide open to clenched fist in 1.1 s

Pinch force
62 N
Pinch payload
1.1

Official source: Nominal payload 1.1kg (pinch configuration)

Sensing

Proprioceptive feedback
Motor position and motor current

Configurations

Standard

Sensing

Has tactile sensing
Not supported
Commercial Status

Status
Commercial
Price
Unknown
Release Date
Unknown
Submit a source or correction