
 Tesla
Tesla Optimus Hand (2022)
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Prototype
Availability
Not released
Release Date
Sep 30, 2022
Country/Region
United States
Latest parameter verificationLatest individual parameter check, not a full-model review or edit date.
2026-11-01
Active degrees of freedom not independently confirmed
Active degrees of freedom
5 fingers
Finger count
Tesla's Optimus prototype hand shown at AI Day 2022. Each hand has six actuators and 11 degrees of freedom. An in-hand controller drives the fingers and receives sensor feedback. Its adaptive mechanism conforms to grasped objects, and its non-backdrivable finger drive can hold objects with the hand motors off.
1 / 1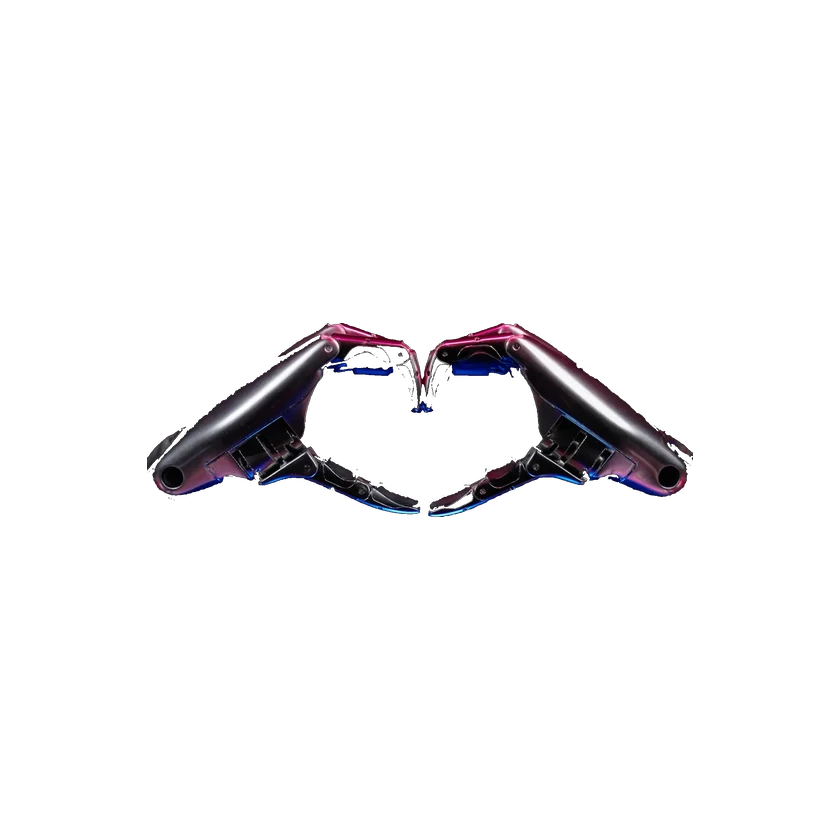
Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Physical Specifications
Finger count
5 fingers
Actuator count
6 actuators
Six actuators per hand are stated separately from the 11 DoF. Actuator count alone does not establish the active control count.
Actuator technology
Tendon-driven, spring-loaded
The inherited classification describes tendon/spring transmission, not a confirmed motor type. Transmission is recorded separately; motor technology remains unconfirmed.
Active degrees of freedom
Active degrees of freedom not independently confirmed
The 2022 presentation states 11 DoF and six actuators without distinguishing active and passive coordinates. The active count remains unconfirmed.
Materials
Metallic finger tendons
Material applies only to the metallic finger tendons. Alloy, steel grade, frame and finger-shell materials are not specified.
Total degrees of freedom
11 DOF
The presentation gives 11 DoF without identifying 11 independently actuated coordinates. Do not use this value as the active control count.
Transmission mechanism
Tendon-driven with passive spring extension
2022 design: tendons close the fingers and springs passively extend them. This does not establish a gearbox ratio or active DoF count.
Motion and coordination
Coordination architecture
Adaptive mechanism for grasping objects
Mechanical Structure
Dexterous Hand
Human-like adaptive hand
End-Effector
Human-like hand for grasping objects designed for human hands
Joint Type
Non-backdrivable finger drive with clutching mechanism
Sensors
Sensors
In-hand controller receives sensor feedback
Sensor types, layout and quantities are unspecified. The introductory tactile-sensing comparison describes human hands and does not establish robot tactile hardware.
Compute Platform
Onboard Compute
In-hand controller for finger drive and sensor feedback
The presentation identifies an in-hand controller but does not specify its CPU, memory or physical communication interface.
Development and Expansion
Operating Modes
Adaptive grasping
Commercial Status
Status
Prototype
Price
Price not disclosed
Release Date
Sep 30, 2022
Related Entities
Robots related to “Optimus Gen 1 Hand”
Related robots
Video
Tesla AI Day 2022 — Hands
Tesla · 2022-10-01Submit a source or correction