
Noetix Robotics logoNoetix Robotics

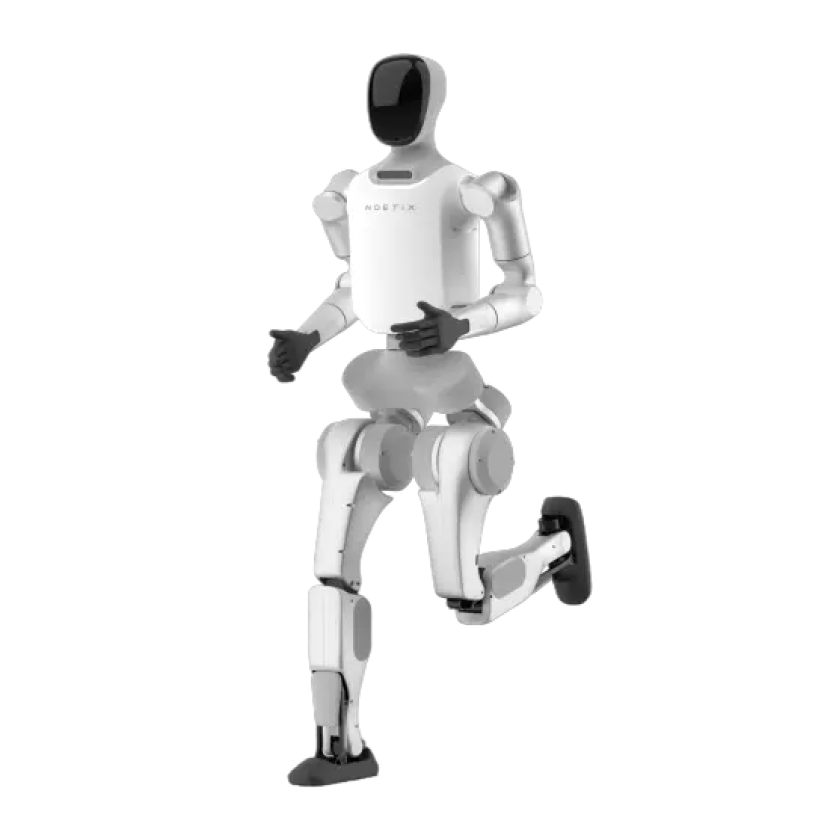
E1

Price
Price not disclosed
Type
Humanoid Robots · Compact Humanoid
Applications
Research & Education · Developer Kit / Research & Education · Education Platform / Research & Education · Research Platform
Status
Available for sale
Availability
On sale
Purchase
Not disclosed
Release Date
Unknown
Country/Region
China
Last Verified
2026-08-30
How classification and status work

Category describes physical structure and function; wheels alone do not determine whether a robot is humanoid. Product stage describes demonstrated maturity. Commercial availability describes current access: a commercial product may still be limited to pilot customers. Neither stage nor availability alone proves that a product can be purchased. Unknown facts remain unknown.

23–28
Total degrees of freedom
140 cm
Height
40 kg
Weight
2–3 h
Runtime

E1 is a Noetix humanoid robot for research, education, family companionship, elderly care, exhibitions, guidance and enterprise service. It has a composite body, 23–28 degrees of freedom, a modeled five-finger hand with an optional dexterous hand, depth camera, circular microphone, large-model support, 6 TOPS base computing and a 2–3 hour runtime.

1 / 1E1

Hardware Specification

Physical Specifications

Dimensions (Standing)
140 cm
Dimensions (Standing)
49 cm
Dimensions (Standing)
32 cm
Total degrees of freedom
23–28

Mobility & Payload

Continuous Walking Payload
5 kg

Mechanical and mounting

Controllable DOF per Arm
5 DOF
Height
140 cm
DOF per Leg
6 DOF
Waist DOF
1 DOF
Waist Rotation Range
90 °
Weight
40 kg

Mechanical Structure

Dexterous Hand
Five-finger modeled hand; optional dexterous hand available
Internal Wiring
Internal cable routing
Joint Bearing
Crossed-roller bearing + deep-groove ball bearing
Joint Encoder
Dual encoders

Sensors

Sensors
Depth camera

Battery and Runtime

Power Supply
Lithium battery
Runtime
2–3 h

Compute Platform

Onboard Compute
6 TOPS

Interaction and Communication

Communication
Wi-Fi 6; Bluetooth 5.2
Microphone
Circular microphone
OTA Update
Smart OTA updates
Voice Interaction
Supports large models

Development and Expansion

Secondary Development (SDK)
Technical guidance for development and SDK documentation provided

Open source & build resources

Software

Not verified

There is not enough verified evidence to establish this dimension.

Hardware design

Partial hardware documentation

Official documentation describes E1 external interfaces and board roles, distinguishing the education-only development compute board. These are partial integration materials, not board schematics, a complete BOM or manufacturing drawings. A hardware license has not been verified.

View explanation

Build resources

Not verified

There is not enough verified evidence to establish this dimension.

TypeResourceLicenseApplicable versionOpen
HardwareE1 electrical interfaces and board reference

web.noetixrobotics.com

Official documentation describes E1 external interfaces and board roles, distinguishing the education-only development compute board. These are partial integration materials, not board schematics, a complete BOM or manufacturing drawings. A hardware license has not been verified.

—E1Open documentation

Commercial Status

Status
Available for sale
Price
Price not disclosed
Release Date
Unknown

Deployment records

Progress, changes and sources from real-world projects.

Partner
Noetix Robotics · Operator
Scenario
Events & Exhibitions
Primary task
Compete in the standing long jump at the 2025 World Humanoid Robot Games; Noetix Robotics reported that E1 won with a 1.25 m result. This is a completed one-off competition and technology-validation use, not a claim of customer production operation.
Location
National Speed Skating Oval (Ice Ribbon), Beijing, China
Started
Undisclosed
Last verified
2026-10-12
Operating sites
1

Deployment timeline · 1

  1. E1 wins the 2025 Games standing long jump with 1.25 m
As of the verified evidence; this is not live operating status.2026-10-12
Submit a source or correction