
 Elephant Robotics
MS Joint Modules
- Output speed
- 30 rpm
- Outer diameter
- 82 mm
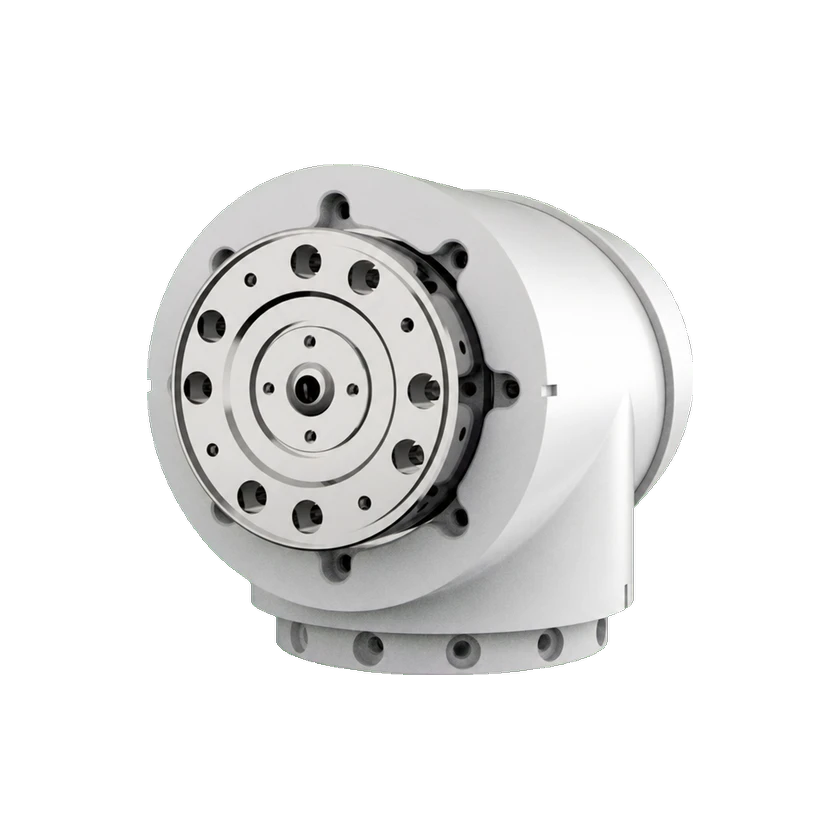
MS14 is Elephant Robotics' official-shell integrated joint module. Its product page positions the MS series for customizable collaborative-robot builds across industrial, research, education and commercial applications.
Technical specifications
Values use consistent engineering units.
Output & transmission
- Output torque
14.25 N·m
- Output torque
53.2 N·m
- Output speed
30 rpm
Dimensions & installation
- Outer diameter
82 mm
- Axial length
121.7 mm
- Hollow bore diameter
6.5 mm
- Tilting moment
40 N·m
- Tilting moment
80 N·m
Electrical
- Operating current
1.15 A
- Operating current
4.3 A
Encoders & feedback
- Encoder resolution
19 bit
- Encoder counts per revolution
20000 count/rev
Construction & components
- Motor integration
Integrated
- Reducer integration
Integrated
- Encoder integration
Integrated
- Brake integration
Integrated
Open source & build resources
Software
Not verifiedThere is not enough verified evidence to establish this dimension.
Hardware design
Partial hardware documentationThe official page provides “MS Module User Manual” V1.0 in Downloads. Covers MS14/17/20/25/32 mounting dimensions, drive connectors and module integration. Match the delivered driver/configuration. Copyright is reserved; copying or translation requires written permission. Not module manufacturing CAD, firmware or a complete robot-build package.
View explanationBuild resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Hardware | MS-series installation, wiring and dimension manual elephantrobotics.com The official page provides “MS Module User Manual” V1.0 in Downloads. Covers MS14/17/20/25/32 mounting dimensions, drive connectors and module integration. Match the delivered driver/configuration. Copyright is reserved; copying or translation requires written permission. Not module manufacturing CAD, firmware or a complete robot-build package. | — | MS14 (MS-series user manual V1.0) | Open documentation |
Commercial Status
Related Entities
No related products recorded yet.