MagicLab logoMagicLab

MagicHand

MagicHand S01 · 第一代

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Feb 19, 2025
Country/Region
China
Latest parameter verification
2026-10-30
Including pressure sensors: 0.58 kg
Hand weight
5
Finger count

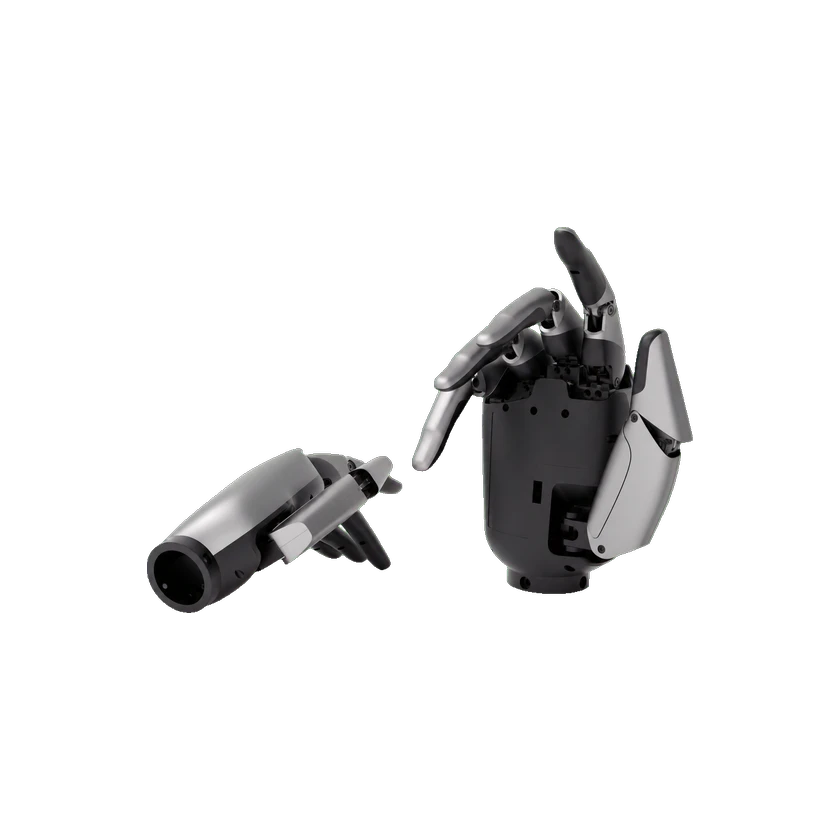
MagicHand S01 is a five-finger robotic hand developed by MagicLab. The official brochure specifies 11 total degrees of freedom, including 6 active degrees, and a rated pulling payload of 5 kg per hand. Modular fingers and linkage actuation work with current-and-tactile fusion for hybrid force–position control; the company specifies force resolution as fine as 0.1 N. It identifies grasping, two-finger manipulation, part handling and screw turning as applications for robotic assembly, transport and inspection.

1 / 1MagicHand S01

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator technology
Electric
Materials
Integrated die-cast load-bearing structure; lighter non-load-bearing structure
Total degrees of freedom
11 DOF
Transmission mechanism
Electric pushrod
Actuator Model
In-house micro electric pushrods
Actuator Model
Micro electric pushrod designed with 30% thrust reserve

Mobility & Payload

Coordination architecture
In-house six-axis motor driver and dexterous-hand controller
Hand Payload
5 kg
General Payload
5 kg

Mechanical and mounting

Mounting interface
End effector interface for humanoid robots
Hand weight
Including pressure sensors: 0.58 kg

Electrical and integration

Dexterous Hand
Five-finger dexterous hand
Dexterous Hand Model
MagicHand S01
Joint Encoder
Multi-turn absolute encoders
Joint Sensor Type
Multi-turn absolute encoder
Joint Type
Micro electric pushrod
Maximum current
3 A
Operating voltage
12 V
Static current
0.2 A

Sensors

Force/Torque Sensor
Force perception combines current sensing and high-sensitivity multipoint tactile sensing
Sensors
Current sensing and high-sensitivity multi-point tactile sensing
Tactile Sensor
Five tactile sensors

Battery and Runtime

Power Supply
12 V

Performance and tasks

Repeatability
End effector: 0.2 mm
Software Algorithm
Hybrid force-position control combining motor current and tactile input

Interaction and Communication

Communication
100 Hz control-frequency interface with the humanoid robot
Tactile Feedback
Tactile force resolution: 0.1 N

Configurations

MagicHand S01

Sensing

Has tactile sensing
Supported
Commercial Status

Status
Unknown
Price
Price not disclosed
Release Date
Feb 19, 2025
Submit a source or correction