Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-10-30
6 DOF
Active degrees of freedom
11
Mechanical joint count
≤ 0.8 kg
Hand weight
5
Finger count

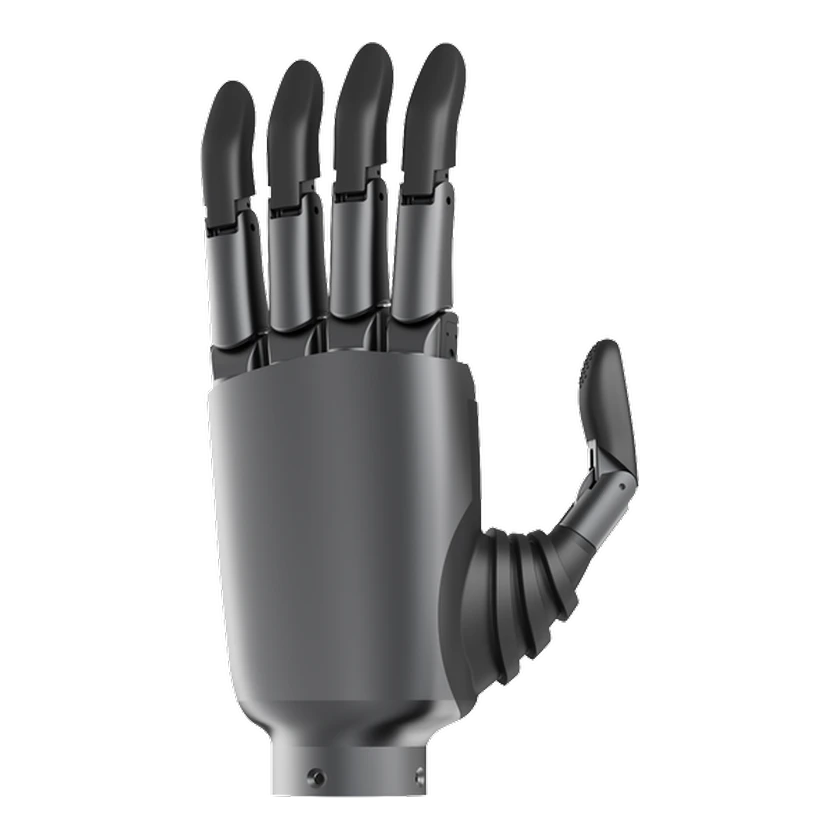
IN100 is a five-finger robotic hand from HeymanDex for commercial and industrial manipulation. It has six independent degrees of freedom, eleven mechanical joints and a modular design with position and current feedback. Software development and teleoperation support integration with humanoid robots and manipulators.

1 / 1IN100

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Coupled degrees of freedom
5 DOF
Active degrees of freedom
6 DOF
Ingress Protection (IP)
IP68
Mechanical joint count
11
Materials
Aluminum alloy; silicone
Joint Motion Range
PIP coupled joint: 0–90 °

The official page specifies a coupling factor of 0.94.

Joint Motion Range
MCP joint: 0–95 °

Mechanical and mounting

Hand weight
≤ 0.8 kg

Electrical and integration

Operating voltage
12–48 V

Battery and Runtime

Power Supply
12–48 V / 5 A

Performance and tasks

Repeatability
±0.2 mm

Development and Expansion

App Platform
Windows / Linux (x86 / ARM)
Integration Interface
Standard wrist flange; quick-change and custom adapters supported
Secondary Development (SDK)
C++ SDK
Teleoperation
Monocular hand tracking; Apple Vision Pro, Meta Quest 3

Configurations

IN100

Communication and control

Communication interface
RS485

Variant not bound

The official source lists RS485 / CAN but does not bind interfaces to a specific hardware variant.

Communication interface
CAN

Variant not bound

The official source lists RS485 / CAN but does not bind interfaces to a specific hardware variant.

Feedback signals
Position
Feedback signals
Current

Commercial Status

Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction