
OpenArm Teleoperation
Open-source hardware design with purchasable development kits. A 1:1 leader–follower arm teleoperation setup with unilateral and bilateral force-feedback modes.
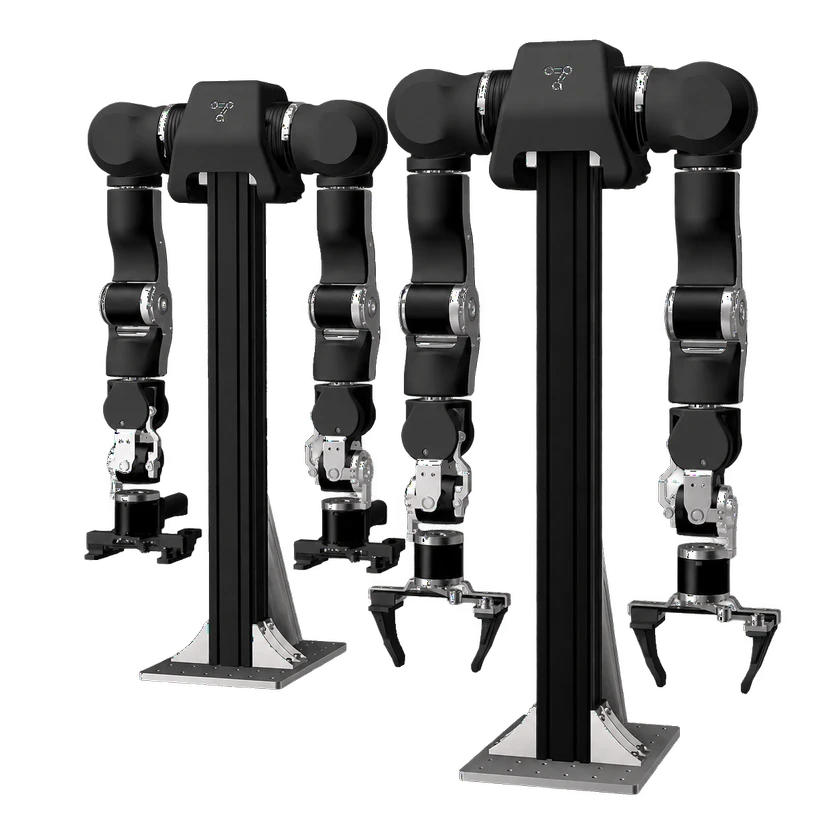
Technical specifications
Collection capabilities
Sensing and data flow
Software and export
Development support
OpenArm TeleoperationCurrent model
OpenOne active follower arm executes motion and one leader supplies operator input; the leader is excluded from execution-arm count. Select the correct arm side and independent CAN interfaces, generate the matching v10 URDFs, and calibrate both arms independently at the documented downward zero pose. Unilateral control has no returned force feedback; bilateral force feedback requires a real-time rate of at least500Hz and tuned gains.
Development capabilities
Sources · 2
- Officialdocs.openarm.dev ↗Verified: 2026-11-06
- Officialdocs.openarm.dev ↗Verified: 2026-11-06

Open source & build resources
Software
Partially availableExamples or supporting tools are available; this does not establish access to the core system.
Hardware design
Open sourceDesign files and a verified open license are available. Follow the terms of each resource.
Build resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | OpenArm 1.0 leader–follower control GitHub · enactic/openarm_teleop Official 1:1 teleoperation software for OpenArm 1.0. OpenArm 2.0 needs adaptation and testing according to the project's compatibility table. | Apache-2.0 | OpenArm 1.0 | Open GitHub |
| Hardware | OpenArm 1.0 CAD, STL and wiring GitHub · enactic/openarm_hardware Official v1 hardware files include leader and follower STEP assemblies, printable STL parts, attachments and wiring diagrams. CERN-OHL-S-2.0 requires compliance with its reciprocal terms. | CERN-OHL-S-2.0 | OpenArm 1.0 | Open GitHub |