
 DAMIAO
DM-JH Harmonic Joint Motors
- Output torque · Rated
- 3.2 N·m
- Outer diameter
- 52 mm
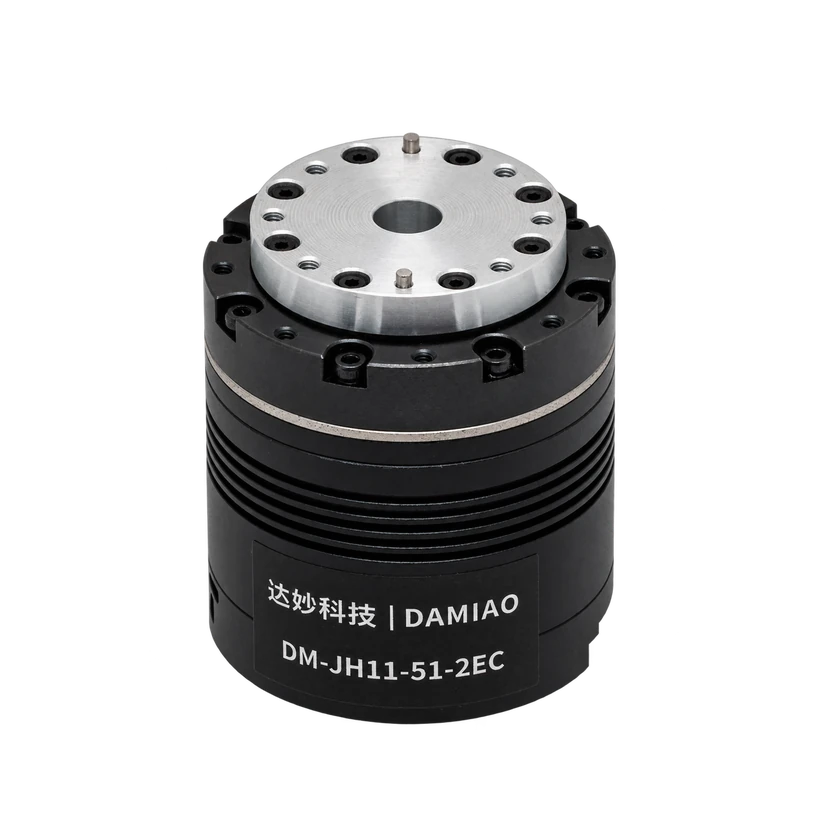
DM-JH11-51-2EC is an integrated harmonic joint motor from DAMIAO, with motor, driver and dual encoders. The official specification lists a 51:1 reduction, 3.2 N·m rated torque and 7.8 N·m peak torque. CAN provides speed, position, torque and motor-temperature feedback.
Technical specifications
Output & transmission
- Output torque · Rated
3.2 N·m
Scope not bound
- Output torque · Peak
7.8 N·m
Scope not bound
- Output speed · Rated
40 rpm
Scope not bound
- Output speed
60 rpm
Scope not bound
Dimensions & installation
- Outer diameter
52 mm
Scope not bound
- Axial length
60 mm
Scope not bound
- Hollow bore diameter
8.5 mm
Scope not bound
Electrical
- Operating current · Rated
2.23 A
Scope not bound
24 V DC
- Operating current · Rated
1.19 A
Scope not bound
24 V DC
- Operating current · Rated
2.23 A
Scope not bound
48 V DC
- Operating current · Rated
0.54 A
Scope not bound
48 V DC
- Operating current · Peak
4.26 A
Scope not bound
24 V DC
- Operating current · Peak
4.25 A
Scope not bound
24 V DC
- Operating current · Peak
4.26 A
Scope not bound
48 V DC
- Operating current · Peak
1.85 A
Scope not bound
48 V DC
Encoders & feedback
- Encoder type
Absolute encoder
Scope not bound
- Encoder turn mode
Single turn
Scope not bound
- Encoder resolution
17 bit
Scope not bound
Communication & control
- Communication interface
CAN
Scope not bound
- Communication protocol
CAN FD
Scope not bound
- Control mode
MIT mode / Velocity mode / Position mode / Force/position hybrid control / Cyclic synchronous position / Cyclic synchronous velocity / Cyclic synchronous torque
Scope not bound
Braking & environment
- Protection functions
Overtemperature protection / Overvoltage protection / Undervoltage protection / Overcurrent protection / Communication-loss protection
Scope not bound
Construction & components
- Motor integration
Integrated
Scope not bound
- Reducer integration
Integrated
Scope not bound
- Encoder integration
Integrated
Scope not bound
- Driver integration
Integrated
Scope not bound
Model-level records · configuration applicability unverified
- Weight
- ≈0.345 kg
- Gear Ratio
- 51:1
- Operating voltage
- 24–48 V
- Operating voltage · Rated
- 24 V
Source · 1
2026-11-17
Communication interface · can
Communication protocol · CAN FD
Control mode · mit
Control mode · velocity
Control mode · position
Control mode · impedance
Control mode · cyclic_synchronous_position
Control mode · cyclic_synchronous_velocity
Control mode · cyclic_synchronous_torque
Axial length · 60
Encoder resolution · 17
Encoder turn mode · single_turn
Encoder type · absolute
Hollow bore diameter · 8.5
Driver integration · integrated
Encoder integration · integrated
Motor integration · integrated
Reducer integration · integrated
Operating current · phase rated 2.23 A @ 24 V
Operating current · supply rated 1.19 A @ 24 V
Operating current · phase rated 2.23 A @ 48 V
Operating current · supply rated 0.54 A @ 48 V
Operating current · phase peak 4.26 A @ 24 V
Operating current · supply peak 4.25 A @ 24 V
Operating current · phase peak 4.26 A @ 48 V
Operating current · supply peak 1.85 A @ 48 V
Outer diameter · 52
Output speed · 40
Output speed · 60
Output torque · 3.2
Output torque · 7.8
Protection functions · overtemperature
Protection functions · overvoltage
Protection functions · undervoltage
Protection functions · overcurrent
Protection functions · communication_loss
Weight · 约345.0g
Gear Ratio · 51
Operating voltage · 24
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | DM-JH11-51-2ECDM-JH11-51-2EC | DM-JH11-101-2ECDM-JH11-101-2EC |
|---|---|---|
| Communication interface | CANScope not bound | CANScope not bound |
| Communication protocol | CAN FDScope not bound | CAN FDScope not bound |
| Outer diameter | 52 mmScope not bound | 52 mmScope not bound |
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseDM-JH11-51-2EC