
 CubeMars
 AK
- Output torque · Rated
- 48 N·m
- Outer diameter
- 98 mm
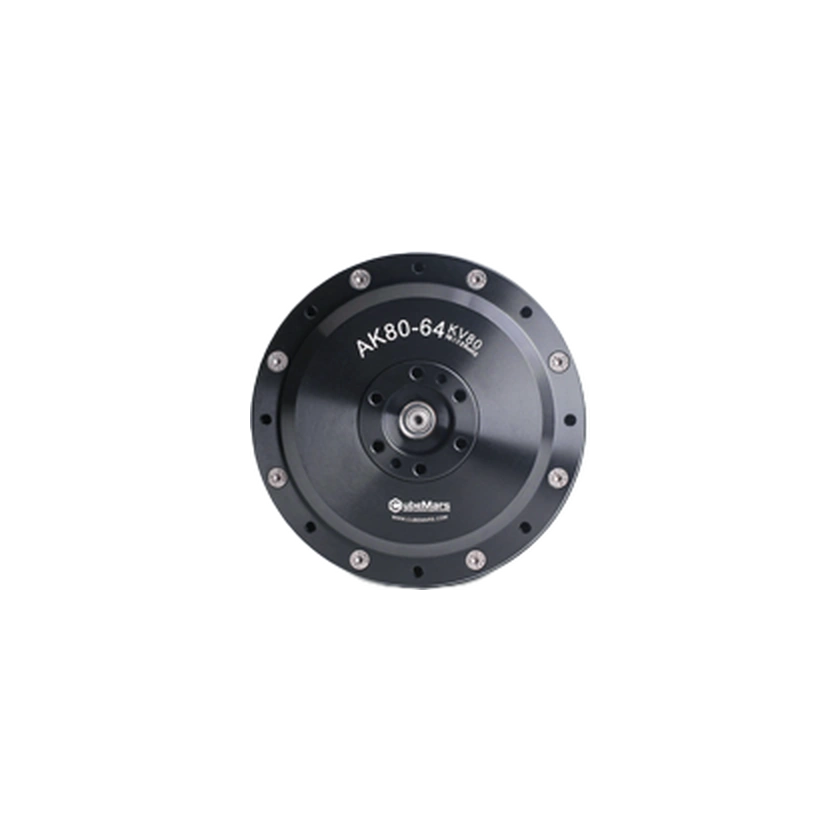
AK80-64 KV80 is a CubeMars AK series robotic actuator. Official model information provides mechanical dimensions and performance specifications for checking integration space, output capability and drive configuration. Refer to the linked source for operating conditions.
Technical specifications
Output & transmission
- Output torque · Rated
48 N·m
Scope not bound
- Output torque · Peak
120 N·m
Scope not bound
- Output speed · Rated
23 rpm
Scope not bound
24 V DC
- Output speed · Rated
48 rpm
Scope not bound
48 V DC
- Output speed · No load
37 rpm
Scope not bound
24 V DC
- Output speed · No load
75 rpm
Scope not bound
48 V DC
- Backdrive torque
4.7 N·m
Scope not bound
- Backlash
10.8 arcmin
Scope not bound
Dimensions & installation
- Outer diameter
98 mm
Scope not bound
- Axial length
61.9 mm
Scope not bound
Electrical
- Operating current · Rated
7 A
Scope not bound
- Operating current · Peak
19 A
Scope not bound
Encoders & feedback
- Encoder type
Single encoder
Scope not bound
- Encoder resolution
14 bit
Scope not bound
Construction & components
- Driver integration
Integrated driver board
Scope not bound
Model-level records · configuration applicability unverified
- Development access
- Conditional support
- Country/Region
- China
- Positioning / Application
- Robotic joint actuator with motor and planetary reduction
- Positioning / Application
- Legged robots, exoskeletons and AGVs
- Weight
- 0.85 kg
- Actuator Model
- AK80-64 KV80
- Gear Ratio
- 64:1
- Operating voltage · Rated
- 48 V
- Operating voltage · Rated
- 24 V
- Rated power
- 220 W
- Operating temperature
- -20–50 °C
- Configuration Options
- With drive board
- Configuration Options
- Without drive board
Source · 4
2026-11-14
Axial length · 61.9
Backdrive torque · 4.7
Backlash · Backlash (°) · 0.18
Encoder resolution · 14bit
Encoder type · Single
Driver integration · Yes
Operating current · 7 A
Operating current · 19 A
Outer diameter · 98
Output speed · 23/48
Output speed · 37/75
Output torque · 48
Output torque · 120
Weight · 850 g
Operating voltage · 24/48 V
Rated power · 220 W
2026-10-14
Positioning / Application · 产品描述 CubeMars AK80-64 KV80 机器人动力模组将无刷直流电机、自研行星减速器、编码器与驱动器高度集成于一体,结构紧凑、安装便捷。它采用 64:1 行星减速结构,在低速高扭矩场景下表现出色,同时仍兼顾控制精度与响应性能。该模组支持伺服控制与 MIT 混合控制模式,具备自适应 PID 参数识别功能,并集成过流、过压/欠压、过温等保护机制,确保模块在复杂环境下的稳定运行。
Positioning / Application · 应用领域 足式机器人,外骨骼,AGV
Actuator Model · AK80-64 KV80
Gear Ratio · 减速比 64:1
Operating temperature · 工作环境温度 -20℃~50℃
Configuration Options · 驱动板 有
Configuration Options · 驱动板 没有
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | AK80-64 KV80With drive board | AK10-9 V3.0 KV60With driver board |
|---|---|---|
| Backlash | 10.8 arcminScope not bound | — |
| Outer diameter | 98 mmScope not bound | 98 mmScope not bound |
Development support
AK80-64 KV80Current model
Conditional accessExact existing AK80-64 KV80, explicitly listed in official AK2.0 driver manual v1.0.18. Match the delivered AK driver revision, firmware, calibration and controller mode. Servo and MIT use distinct protocols; mode change is a stopped/power-cycle configuration workflow per manual, not a live runtime handoff. Generic AK code constants do not establish this model encoding.
AK80-64 MIT native standard-CAN profile: enable/disable/zero frames are separate; position16bit rad, velocity12bit rad/s, Kp/Kd12bit and additive torque12bit Nm. Manual page42 diagram adds target torque to PD terms, and explicit torque mode is documented. Exact AK80-64 table gives ±12.5rad, ±8rad/s and ±144Nm encoding ranges; generic pack/unpack examples instead hardcode ±30rad/s and ±18Nm and must not be used unchanged. Encoding ranges are not physical ratings/allowable motion limits; verify delivered revision and firmware with supplier. Kp/Kd gains, zero/limits, bus ID/termination and fault/temperature feedback require deliberate handling; current/temperature feedback is not a reach guarantee. Manual snippets do not establish a supported host C++/Python SDK or license. No motor command/firmware change executed.
Development capabilities
Sources · 1
- Officialwww.cubemars.com ↗Verified: 2026-11-06
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseAK80-64 KV80