
 CubeMars
 AK
- Output torque · Rated
- 18 N·m
- Outer diameter
- 98 mm
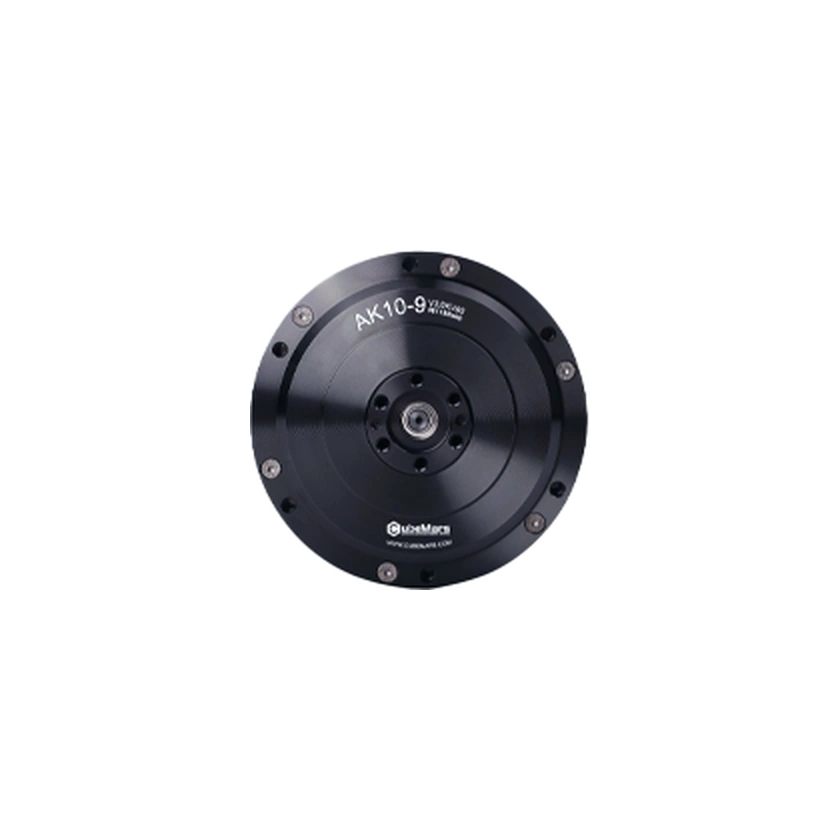
AK10-9 V3.0 KV60 is a CubeMars AK series robotic actuator. Official model information provides mechanical dimensions and performance specifications for checking integration space, output capability and drive configuration. Refer to the linked source for operating conditions.
Technical specifications
Output & transmission
- Output torque · Rated
18 N·m
Scope not bound
- Output torque · Peak
53 N·m
Scope not bound
- Output speed · Rated
235 rpm
Scope not bound
- Output speed · No load
320 rpm
Scope not bound
Dimensions & installation
- Outer diameter
98 mm
Scope not bound
- Axial length
61.7 mm
Scope not bound
Electrical
- Operating current · Rated
10.7 A
Scope not bound
- Operating current · Peak
31.9 A
Scope not bound
Encoders & feedback
- Encoder type
Dual encoders
Scope not bound
- Encoder resolution
21 bit
Scope not bound
Construction & components
- Driver integration
Integrated driver board
Scope not bound
Model-level records · configuration applicability unverified
- Weight
- 0.94 kg
- Gear Ratio
- 9:1
- Operating voltage · Rated
- 48 V
- Rated power
- 442 W
Source · 1
2026-11-14
Axial length · 61.7
Encoder resolution · 21bit
Encoder type · Dual
Driver integration · Yes
Operating current · 10.7 A
Operating current · 31.9 A
Outer diameter · 98
Output speed · 235
Output speed · 320
Output torque · 18
Output torque · 53
Weight · 940 g
Gear Ratio · 9:1
Operating voltage · 48 V
Rated power · 442 W
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | AK80-64 KV80With drive board | AK10-9 V3.0 KV60With driver board |
|---|---|---|
| Backlash | 10.8 arcminScope not bound | — |
| Outer diameter | 98 mmScope not bound | 98 mmScope not bound |
Development support
AK80-64 KV80
Conditional accessExact existing AK80-64 KV80, explicitly listed in official AK2.0 driver manual v1.0.18. Match the delivered AK driver revision, firmware, calibration and controller mode. Servo and MIT use distinct protocols; mode change is a stopped/power-cycle configuration workflow per manual, not a live runtime handoff. Generic AK code constants do not establish this model encoding.
Sources · 1
- Officialwww.cubemars.com ↗Verified: 2026-11-06
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseAK10-9 V3.0 KV60