AGIBOT logoAGIBOT

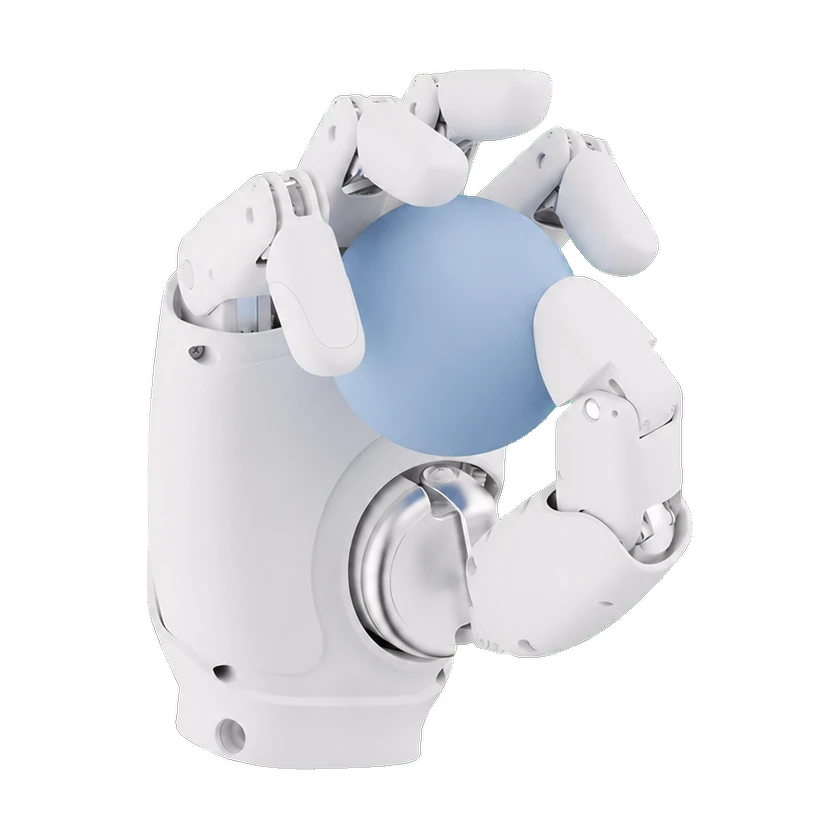
AGIBOT OmniHand 2025

Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-11-01
10 DoF
Active degrees of freedom
5 N
Fingertip force
≤0.51 kg
Hand weight
5 fingers
Finger count

OmniHand 2025 is a five-finger dexterous hand for embodied-AI interaction, with 10 active and 16 total degrees of freedom. Its compact lightweight linkage design suits humanoid robots, robotic arms, research, education, and interactive services, with multiple control modes and secondary development support.

1 / 1OmniHand 2025

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5 fingers
Actuator technology
Motor and gear
Active degrees of freedom
10 DoF
Active degrees of freedom
10 active DOF per hand
Materials
PA + Silicone
Total degrees of freedom
16 DoF
Total degrees of freedom
16 total DOF
Transmission mechanism
Linkage mechanism
Actuator Model
Motor + Gear

Mechanical and mounting

Depth
3.85 cm
Dimension reference frame
Main unit
Dimension included components
Dimension inclusion not specified

The source excludes end cap/screws specifically from mass, not from the stated dimensions. The prior dimension-scope assertion is withdrawn; raw wording/source/date are retained as history.

Length
18 cm
Minimum grip diameter
0.5 cm
Hand weight
≤0.51 kg

The current standard-column bound≤510g excludes the wrist end cap and screws. The tactile column is≤520g; neither the old≤500g web overview nor the tactile value replaces this standard record.

Width
8.5 cm

Electrical and integration

Joint Limit
Four-finger flexion 80°; abduction ±10°; thumb flexion 50°; abduction 100°; rotation 60°
Joint Name
Thumb; index; middle; ring; pinky
Joint Type
Coupled distal finger joints
Maximum current
3.5 A
Operating voltage
18–27 V

The explicit current technical sheet gives an operating range; the older overview listed24 V nominal.

Static current
0.2 A

Communication and control

Communication interface
CAN-FD / RS485
Control mode
Position/Angle, torque, hybrid PtA, velocity
Feedback rate
1 kHz
Feedback signals
Position, angle, torque, speed, temperature, voltage/current

Software and resources

SDK languages
Windows; secondary development supported

Performance and tasks

Fingertip force
5 N
Open-close time
0.7 s
Operating System
Windows
Repeatability
0.3 mm

The technical sheet reports typical fingertip repeat positioning accuracy0.3mm; the public overview reports0.5mm. The sheet value is retained as reported, without adding± or claiming guaranteed absolute accuracy. Effective revision/conditions are not established.

Vertical grasp payload
1 kg typical; 2 kg maximum

Reliability and environment

Operating temperature
0–45 °C

The model-specific technical sheet states0–45°C, while the still-public overview says−10–45°C. The sheet value is displayed as reported; neither source identifies an effective hardware revision, so the discrepancy remains unresolved for a delivered unit.

Pinch Protection
Anti-pinch design

Interaction and Communication

Communication
CANFD/RS485
OTA Update
Supports OTA upgrade
Tactile Feedback
Historical touch claim; standard variant unconfirmed

Older generic marketing mentions back-of-hand touch, while the variant table reserves quantified force arrays for the tactile edition. This does not establish the installed standard hardware; neither true nor false is inferred.

Commercial availability

Operating Modes
Position/Angle, Torque, Hybrid Position-Torque, Velocity
Package Contents
OmniHand; RS485 cable; CANFD cable; power cable; Type-C data cable; certificate
Purchase route
Online store
Purchase URL
Official store
Secondary Development (SDK)
Secondary development supported

Configurations

Standard

Communication and control

Communication interface
CAN FD

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. Bus bit rates are not the control-loop frequency. The manual explicitly excludes classic CAN responses.

Communication interface
RS485

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts.

Communication interface
USB (HMI/virtual serial port)

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. The native board USB link is documented for HMI/virtual serial communication; this does not promise an unrestricted application SDK or USB data rate.

Communication protocol
OmniHand 2025 command protocol

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts.

Control mode
Position/angle control

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. Mode names do not prove calibrated joint torque sensing; tactile mode is not assigned to the standard configuration.

Control mode
Torque mode

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. Mode names do not prove calibrated joint torque sensing; tactile mode is not assigned to the standard configuration.

Control mode
Hybrid position and torque

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. Mode names do not prove calibrated joint torque sensing; tactile mode is not assigned to the standard configuration.

Control mode
Velocity mode

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. Mode names do not prove calibrated joint torque sensing; tactile mode is not assigned to the standard configuration.

Sensing

Proprioceptive feedback
Joint position, angle, torque, speed, temperature, voltage and current readback

Only the existing OmniHand 2025 standard configuration. Not OmniHand Pro or OmniHand 3; the old store link now redirects to a newer product. Legacy model-level interface/control text remains an equivalent historical presentation, while these are the canonical configuration facts. Reported feedback channels, not a physical-accuracy, torque-sensor or tactile-hardware claim.
Commercial Status

Status
Commercial
Price
Unknown
Release Date
Unknown
Submit a source or correction