
X-Hand M1
Communication and control
Communication interface
Ethernet
Sensing
Has tactile sensing
Supported
 Yuequan Bionics
Rigid dexterous hand; not the Y-Hand series.
X-Hand M1 is Yuequan Bionics’ rigid dexterous hand for standardized industrial tasks. The official product page lists five-finger closure in 0.4 s, 100 N five-finger grip force, ±0.1 mm fingertip repeatability and 472 sensing units. Yuequan also describes an 11-DOF tactile bionic hand. Public sources do not establish price, availability, supported software interfaces, dimensions, power requirements or a released datasheet.
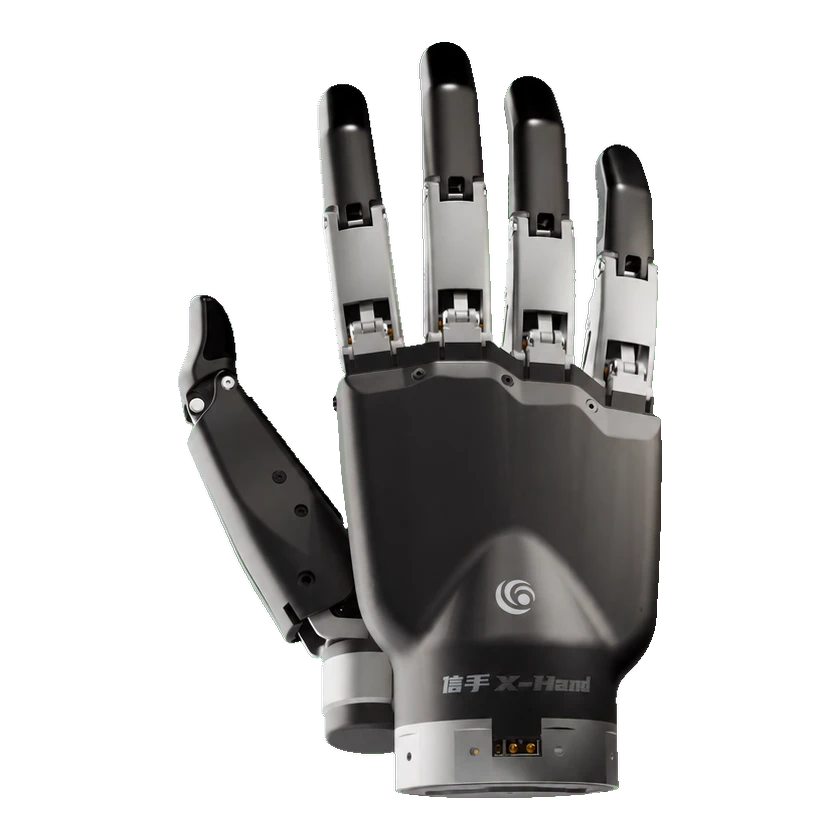
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Examples or supporting tools are available; this does not establish access to the core system.
There is not enough verified evidence to establish this dimension.
There is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | X-Hand M1 official ROS 2 bridge and examples GitHub · yuequanbionics/devices_pkg Apache-2.0 wrapper for control, motor feedback and tactile topics. Match hardware SN/configuration; separate YQ_SDK libraries retain their own terms. The controller term MIT-PD is not a software license. Not complete hand firmware or manufacturing data. | Apache-2.0 | X-Hand M1 (SN-matched ROS 2 configuration) | Open GitHub |
No related products recorded yet.