
Yale University
Sphinx Hand
Yale OpenHand Version 1.0 research hand
Version 1.0
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Research prototype
Availability
Not disclosed
Release Date
Unknown
Country/Region
United States
Latest parameter verificationLatest individual parameter check, not a full-model review or edit date.
2026-10-30
0.645 kg
Hand weight
3 fingers
Finger count
Sphinx Hand is Yale OpenHand's three-finger spherical-parallel research hand. It combines grasping with object rotation about a fixed point near the object, reducing parasitic translation and reliance on arm-wrist motion. The v1.0 build uses six Dynamixel servos and offers open CAD and assembly instructions.
1 / 1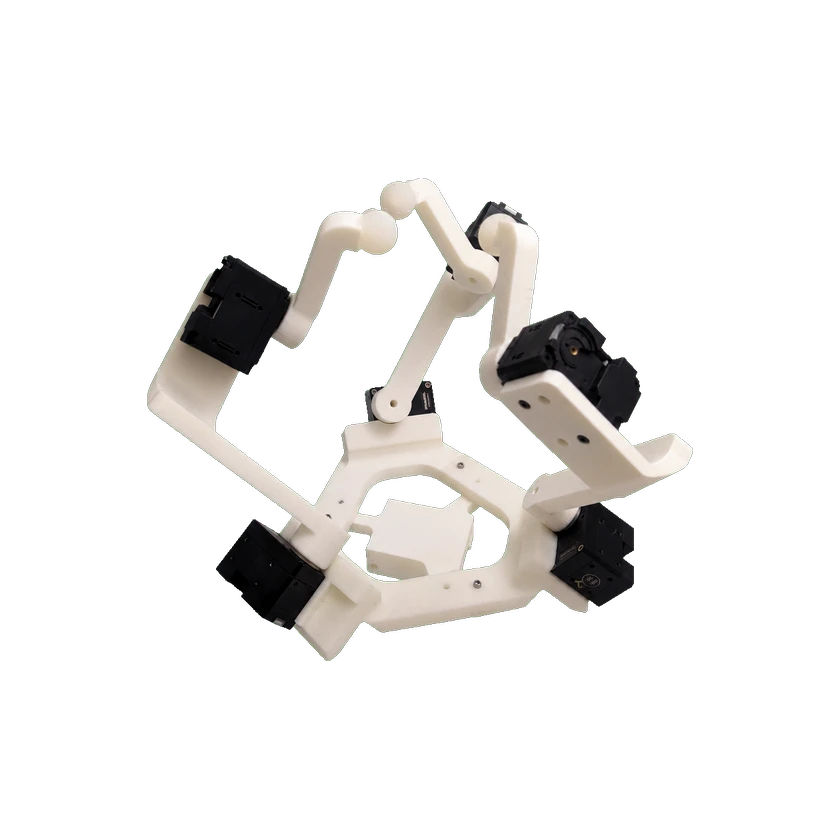
Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Degrees of freedom and drive
Finger count
3 fingers
Actuator count
6
Mechanical and mounting
Hand weight
0.645 kg
Commercial Status
Status
Research prototype
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction