Yale GRAB Lab

iHY Hand

Research prototype; distinct from later commercial derivatives.

iRobot-Harvard-Yale iHY Hand

Price
Not disclosed
Type
Components · Dexterous Hands
Status
Research prototype
Availability
Not released
Release Date
2014
Country/Region
United States
Latest parameter verification
2026-10-30
5 DOF
Active degrees of freedom
1.35 kg
Hand weight
3
Finger count

The iHY Hand is a three-finger, five-actuator underactuated research hand created by iRobot, Harvard, and Yale. Its compliant fingers support power and fingertip grasps, reconfiguration, and basic in-hand manipulation; it is not represented as a current commercial product.
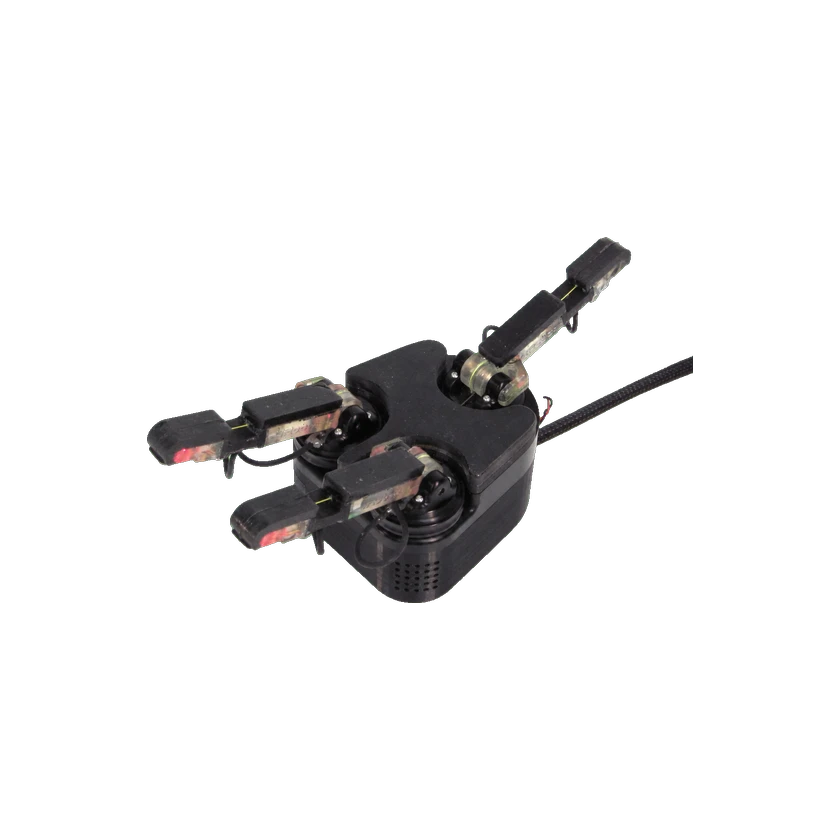
1 / 1iRobot-Harvard-Yale iHY Hand

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
3
Actuator count
5
Actuator technology
Direct-current motors (Maxon EC-20)
Active degrees of freedom
5 DOF
Materials
Glass-filled epoxy resin; elastomeric pads and flexure joints
Transmission mechanism
Non-backdriveable worm-gear transmission

Mechanical and mounting

Hand weight
1.35 kg

Mechanical Structure

Dexterous Hand
Three-finger underactuated research hand
Joint Sensor Type
Magnetic encoders; optical flexure-deformation sensors

Sensors

Tactile Sensor
MEMS barometer tactile arrays; 10 mN sensitivity, 4.9 N range

Configurations

iHY Hand — published 2014 prototype

Sensing

Has tactile sensing
Supported

Commercial Status

Status
Research prototype
Price
Not disclosed
Release Date
2014
Submit a source or correction