
Xynova Prima 1
Sensing
Has tactile sensing
Supported
 Xynova
 Prima 1
Xynova Prima 1 is a five-finger, fully direct-drive dexterous hand developed by Xynova for embodied-AI research, data collection, and algorithm training. According to company materials, its 22 active DoF use independent closed-loop joint control and zero-backlash direct drive, while five-finger visuo-tactile sensing closes the perception-to-action loop. It completes one open-close cycle in 0.08 s, delivers 15 N fingertip force across four fingers, lifts up to 20 kg, and provides 0.5 N force-control accuracy. It supports hybrid force-position control plus MuJoCo, Isaac Lab, and ROS 1/2 development.
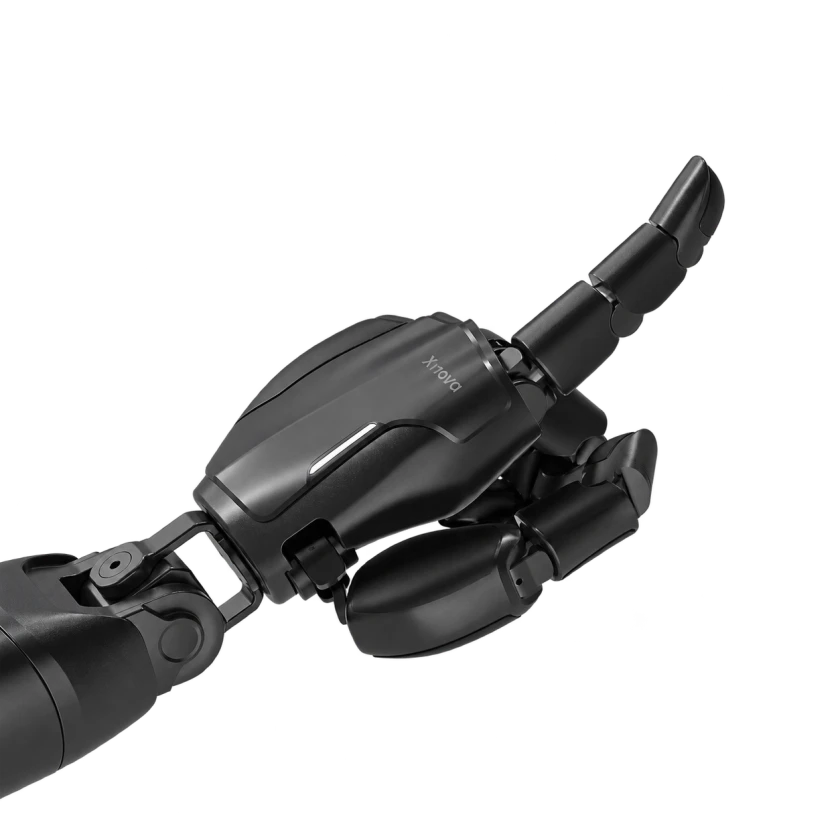
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
No related products recorded yet.