Wonik RoboticsAllegro Hand V5
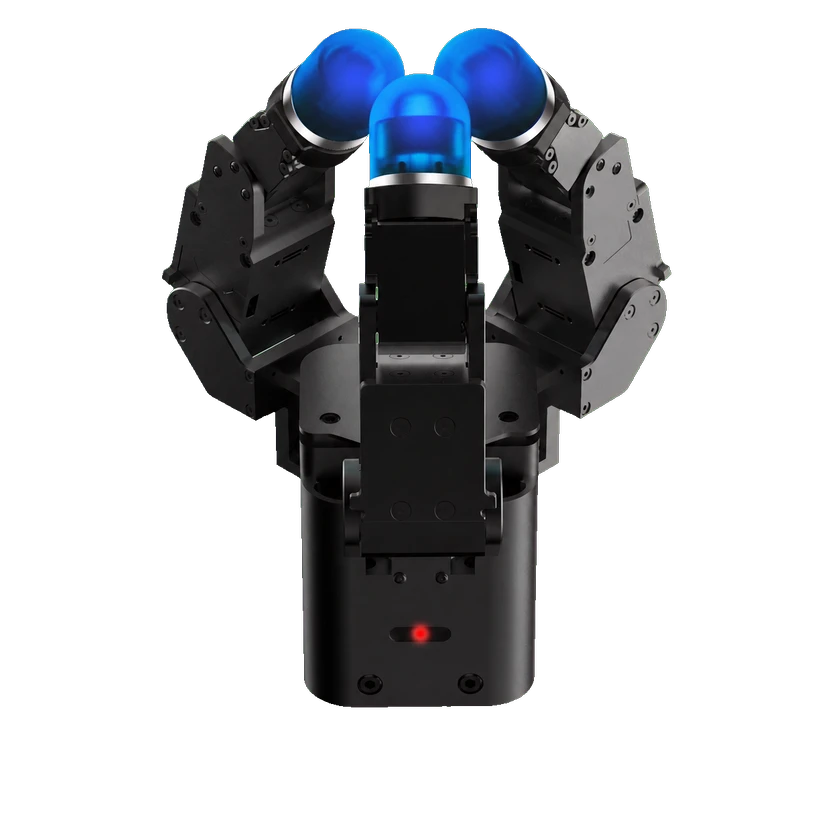
Allegro Hand V5 is a 3-finger dexterous hand with 9 active degrees of freedom, 1.05 kg weight, tactile pressure sensing and CAN communication.

Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Degrees of freedom and drive
Official product overview explicitly identifies independently current-controlled joints and active degrees of freedom.
Mechanical and mounting
Electrical and integration
Communication and control
Official source: 9 independent current-controlled joints (3 fingers × 3 DOF ea.)
Performance and tasks
Reliability and environment
Manufacturer lists SZUTEST attestation SZT-25MA36171-1, issued 2025-02-24.
Sensing
Official source: equipped with 360° omnidirectional pneumatic tactile sensors that detect pressure.
Official source: Sensor Fingertip Pressure Sensor A 360° omnidirectional pressure-sensitive tactile sensor in the shape of a finger