Wonik Robotics logoWonik Robotics

Allegro Hand V5 Plus

Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
South Korea
Latest parameter verification
2026-10-30
16 DOF
Active degrees of freedom
16
Mechanical joint count
1.024 kg
Hand weight
4
Finger count

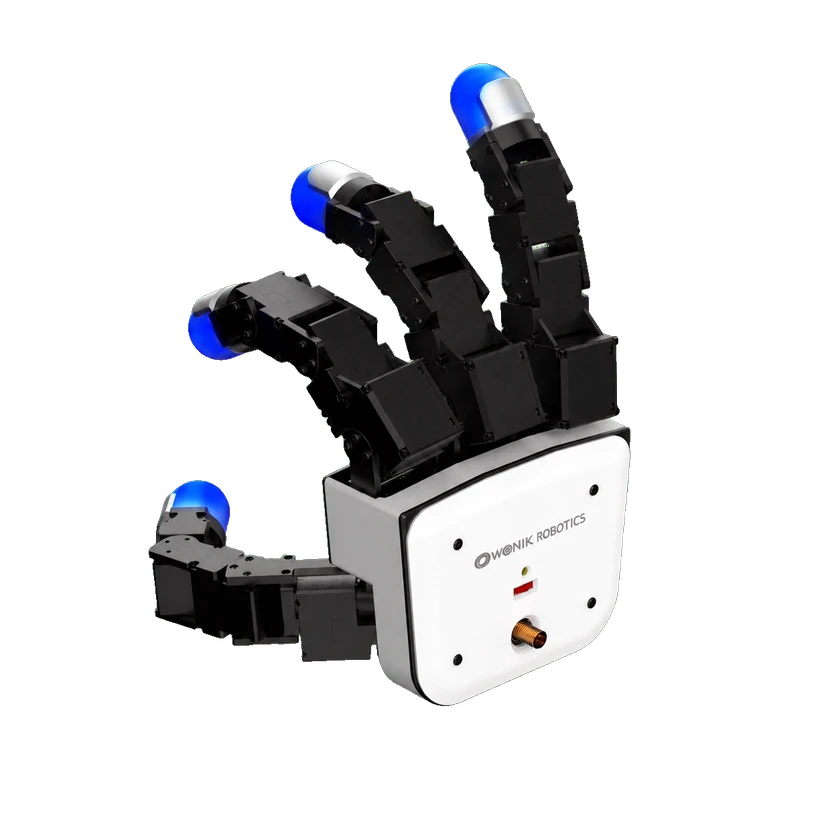
Allegro Hand V5 Plus is a 4-finger dexterous hand with 16 active degrees of freedom, 1.024 kg weight, tactile pressure sensing and CAN communication.

1 / 1Allegro Hand V5 Plus

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
4
Actuator count
16
Actuator technology
DC motor
Active degrees of freedom
16 DOF
Mechanical joint count
16
Total degrees of freedom
16 DOF

Official product overview explicitly identifies independently current-controlled joints and active degrees of freedom.

Mechanical and mounting

Hand weight
1.024 kg

Electrical and integration

Maximum current
5 A
Operating voltage
24 V
Rated current
5.0 A

Official source: Power Requirement 24.0 V / 5.0 A / 120 W

Rated power
120 W

Official source: Power Requirement 24.0 V / 5.0 A / 120 W

Communication and control

Command rate
500 Hz (CAN)

Official source: Frequency 500 Hz (CAN)

Communication interface
CAN
Communication protocol
CAN
Control mode
current-controlled

Official source: 16 independent current-controlled joints (4 fingers × 4 DOF ea.)

Feedback rate
500 Hz

Performance and tasks

Power grasp payload
15 kg

Reliability and environment

Certifications
CE

Manufacturer lists SZUTEST attestation SZT-25MA37567-1, issued 2025-02-24.

Sensing

Has tactile sensing
true

Official source: equipped with 360° omnidirectional pneumatic tactile sensors that detect pressure.

Proprioceptive feedback
Joint resolution 0.088°
Tactile configuration
A 360° omnidirectional pressure-sensitive tactile sensor in the shape of a finger

Official source: A 360° omnidirectional pressure-sensitive tactile sensor in the shape of a finger

Configurations

Standard

Communication and control

Communication interface
CAN
Control mode
Current control

Sensing

Has tactile sensing
Supported
Tactile configuration
Fingertips use 360° omnidirectional pressure-sensitive tactile sensors with capacitive air-pressure measurement. Type A is the default fingertip; types B, C and D are alternative fingertip options sold separately.

Commercial Status

Status
Commercial
Price
Unknown
Release Date
Unknown
Submit a source or correction