TorchKernel Robotics logoTorchKernel Robotics

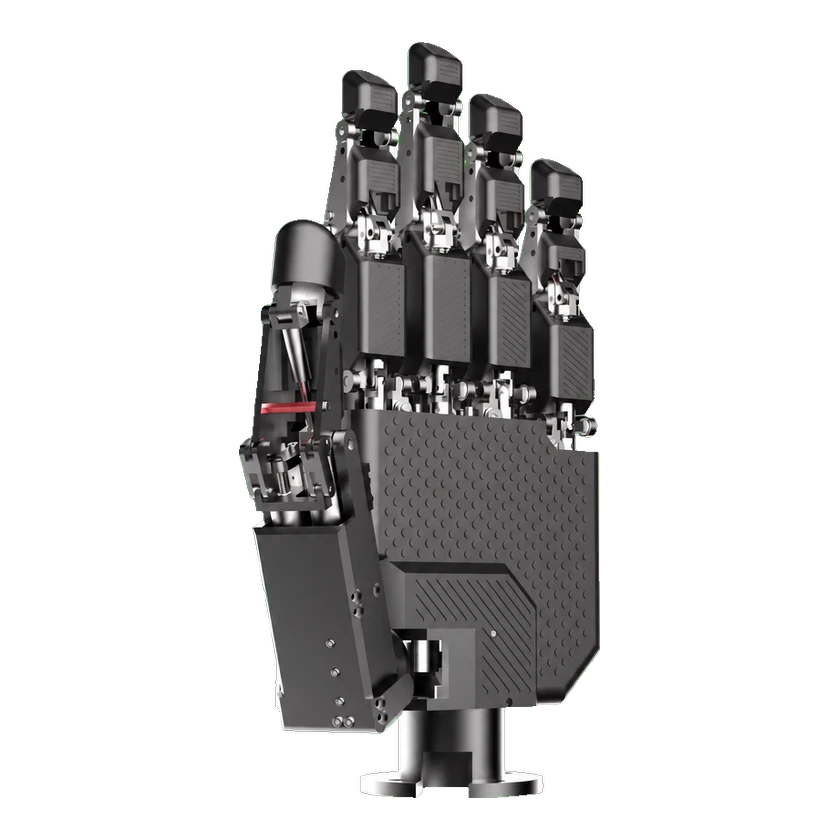
Torch Hand 1

Industrial five-finger dexterous hand released by TorchKernel Robotics.

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Pilot stage; not commercially released; quote inquiries available
Availability
Not released
Release Date
May 21, 2026
Country/Region
China
Latest parameter verification
2026-10-30
16 DOF
Active degrees of freedom
1.1 kg
Hand weight
5
Finger count

Torch Hand 1 is an industrial five-finger hand developed by TorchKernel Robotics, combining spatial decoupling–coupling with quasi-direct, leadscrew and linkage transmission. It has 21 total degrees of freedom, 16 active and 5 passive. Official specifications list a 20 kg rated and 40 kg maximum payload, plus piezoresistive sensing at fingertips and palm. Company material lists chip placement, screw assembly and tool holding, with CAN, RS485 and an SDK for robot integration.

1 / 1Torch Hand 1

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator technology
Self-developed coreless motors
Active degrees of freedom
16 DOF
Passive degrees of freedom
5 DOF
Total degrees of freedom
21 DOF
Transmission mechanism
Hybrid drive (quasi-direct drive, lead screw, and linkage)
Joint Motion Range
30°
Joint Motion Range
90°
Joint Motion Range
90°
Joint Motion Range
90°
Joint Motion Range
70°
Joint Motion Range
60°
Joint Motion Range
80°
Joint Motion Range
90°
Joint Motion Range
90°

Motion and coordination

Coordination architecture
Multimodal perception with intelligent control
Energy domain
Electric
Hand Payload
40 kg
Hand Payload
20 kg

Mechanical and mounting

Length
16.7 cm
Length
11.3 cm
Length
12.8 cm
Length
10.2 cm
Hand weight
1.1 kg

Electrical and integration

Dexterous Hand
Industrial five-finger dexterous hand
Dexterous Hand Model
Torch Hand 1
Joint Type
Human-hand-like joints supporting flexion, finger lateral motion, thumb opposition, finger spreading and closing, and in-hand manipulation
Maximum current
6 A

Manufacturer specification; additional measurement conditions are not given.

Operating voltage
24 V
Static current
< 0.3 A

Manufacturer specification; additional measurement conditions are not given.

Sensors

Sensors
Multimodal perception with fingertip and palm piezoresistive sensing
Tactile Sensor
Piezoresistive tactile sensors on fingertips and palm

Battery and Runtime

Power Supply
24 V rated supply

Performance and tasks

Repeatability
±0.02 mm
Software Algorithm
Multimodal perception and intelligent control

Safety and Protection

Human-Robot Safety
Elastic elements combine compliance and rigidity for safer contact interaction

Interaction and Communication

Communication
CAN or RS485
Tactile Feedback
Fingertip and palm piezoresistive tactile feedback

Development and Expansion

Integration Interface
CAN or RS485
Secondary Development (SDK)
SDK and URDF model provided

Configurations

Torch Hand 1 — CAN interface

Communication and control

Communication interface
CAN

Official specification lists CAN or RS485 alternatives, with piezoresistive tactile sensors on fingertips and palm. Simultaneous use is not claimed.

Sensing

Has tactile sensing
Yes

Official specification lists CAN or RS485 alternatives, with piezoresistive tactile sensors on fingertips and palm. Simultaneous use is not claimed.

Torch Hand 1 — RS485 interface

Communication and control

Communication interface
RS485

Official specification lists CAN or RS485 alternatives, with piezoresistive tactile sensors on fingertips and palm. Simultaneous use is not claimed.

Sensing

Has tactile sensing
Yes

Official specification lists CAN or RS485 alternatives, with piezoresistive tactile sensors on fingertips and palm. Simultaneous use is not claimed.

Commercial Status

Status
Pilot stage; not commercially released; quote inquiries available
Price
Price not disclosed
Release Date
May 21, 2026
Submit a source or correction