Tesollo logoTesollo

DG-5F-M

Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
South Korea
Latest parameter verification
2026-10-30
20 DOF
Active degrees of freedom
20
Mechanical joint count
1.763 kg
Hand weight
5
Finger count

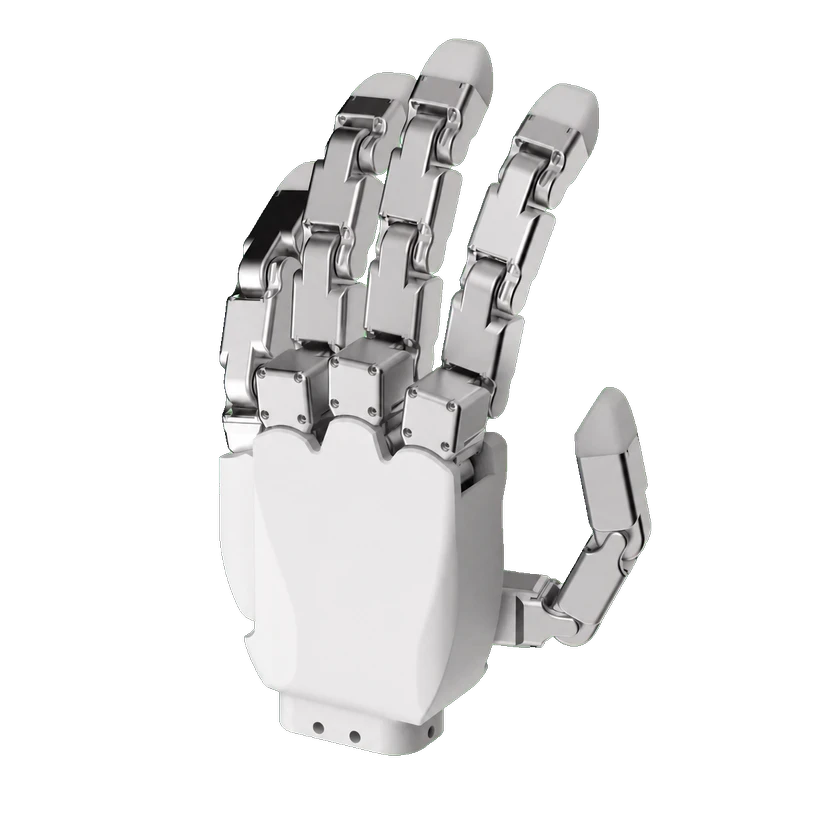
The DG-5F-M is TESOLLO’s fully actuated five-finger dexterous hand with 20 degrees of freedom and independently controlled joints. Its high-torque actuation supports complex grasping and precise object handling, with Modbus and Ethernet communication plus optional 6-axis force/torque, 3-axis force, and tactile fingertip sensors for robotics research, industrial automation, and service robotics.

1 / 1DG-5F-M

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator count
20
Active degrees of freedom
20 DOF
Active degrees of freedom
20 count
Mechanical joint count
20
Total degrees of freedom
20 DOF
Total degrees of freedom
20 DoF (4 DoF per finger)

Official source: Degrees of Freedom 20 DoF (4 DoF per finger)

Transmission mechanism
No inter-joint mechanical coupling

Mechanical and mounting

Hand weight
1.763 kg

Electrical and integration

Joint Encoder
Absolute encoder
Joint Encoder Resolution
12-bit absolute encoder
Maximum current
Max. 10 A

Official source: Max. Current Consumption Max. 10 A

Motor Peak Torque
2 N·m
Operating voltage
24 V

Sensors

Communication interface
Ethernet / serial
Communication protocol
Modbus (RTU, TCP), Ethernet (TCP/IP)

Official source: Communication Modbus (RTU, TCP), Ethernet (TCP/IP)

Control loop rate
250 Hz
Feedback rate
250 Hz
Feedback signals
Absolute Encoder

Official source: Encoder Absolute Encoder

Tactile Sensor
Optional 6-axis F/T, 3-axis force, and tactile fingertip sensors

Software and resources

ROS compatibility
ROS 2

Official source: Provides a user-friendly control interface and ROS 2 integration support

Performance and tasks

Pinch payload
2.5 kg (rated)
Pinch payload
5 kg (maximum)
Pinch payload
Rated / Max : 2.5 / 5 kg

Official source: Pinching Payload (Rated / Max) : 2.5 / 5 kg

Power grasp payload
10 kg (rated)
Power grasp payload
20 kg (maximum)
Power grasp payload
20 kg

Sensing

Communication
Modbus (RTU); Modbus (TCP); Ethernet (TCP/IP)
Proprioceptive feedback
Absolute encoder
Tactile configuration
Optional 6-axis F/T, 3-axis force, or tactile fingertip sensors

Configurations

Standard

Communication and control

Communication interface
Ethernet
Communication protocol
Modbus (RTU)
Communication protocol
Modbus (TCP)
Communication protocol
Ethernet (TCP/IP)
Control mode
Operator mode
Control mode
Developer mode
Feedback signals
Absolute encoder

Software and resources

ROS compatibility
ROS 2

Tactile fingertips (optional)

Sensing

Has tactile sensing
Supported

Commercial Status

Status
Commercial
Price
Unknown
Release Date
Unknown
Submit a source or correction