Tesollo logoTesollo

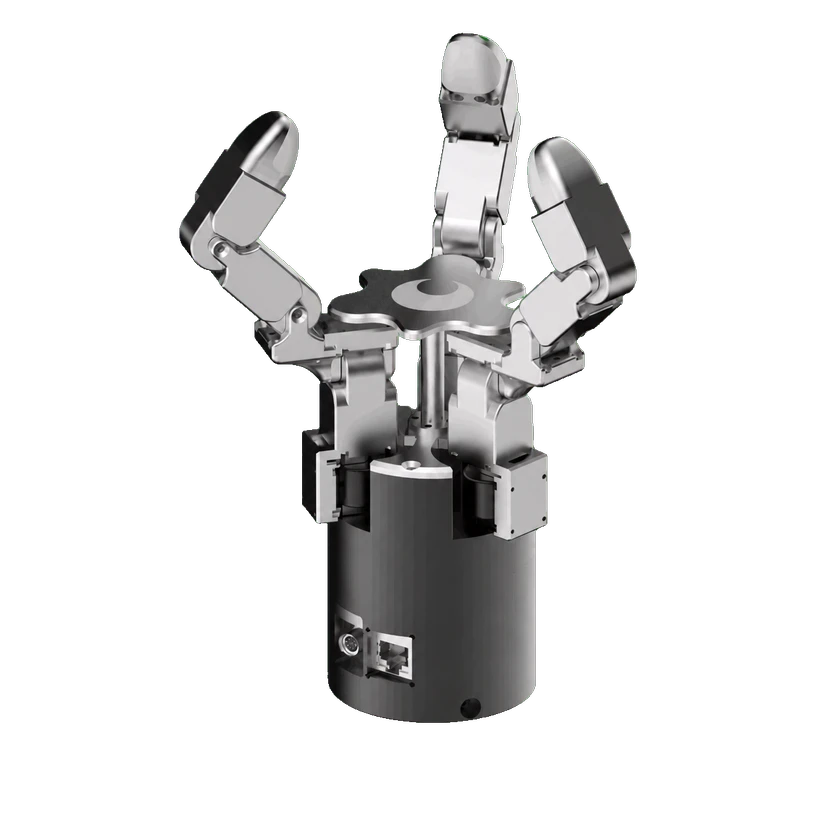
DG-3F-M

Price
Unknown
Type
Components · Dexterous Hands
Status
Commercial
Availability
Not disclosed
Release Date
Unknown
Country/Region
South Korea
Latest parameter verification
2026-10-30
12 DOF
Active degrees of freedom
12
Mechanical joint count
1.114 kg
Hand weight
3
Finger count

Tesollo DG-3F-M is a three-finger gripper with 12 independently controlled degrees of freedom, Ethernet communication and ROS 2 integration. Tactile fingertips are optional.

1 / 1DG-3F-M

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
3
Actuator count
12
Actuator technology
BLDC motors

Official source: High-efficiency BLDC motors and reinforced high-strength gears provide precise control

Active degrees of freedom
12 DOF
Mechanical joint count
12
Total degrees of freedom
12 DOF

Official source: Degrees of Freedom 12 DoF (4 DoF per finger)

Transmission mechanism
Gear transmission

Mechanical and mounting

Hand weight
1.114 kg

Electrical and integration

Maximum current
Max. 10 A

Official source: Max. Current Consumption Max. 10 A

Operating voltage
24 V

Official source: Input Voltage 24 V

Communication and control

Communication interface
Ethernet
Communication protocol
Modbus (RTU, TCP), Ethernet (TCP/IP)

Official source: Communication Modbus (RTU, TCP), Ethernet (TCP/IP)

Control loop rate
333 Hz

Software and resources

SDK languages
C/C++

Official source: Provides a C/C++ SDK for integration with a wide range of robotic platforms

Performance and tasks

Pinch payload
Pinching Payload (Rated / Max): 2.5 / 5 kg

Official source: Pinching Payload (Rated / Max): 2.5 / 5 kg

Pinch payload
2.5 kg (rated)
Pinch payload
5 kg (maximum)
Power grasp payload
10 kg (rated)
Power grasp payload
15 kg (maximum)

Reliability and environment

Mechanical cycle life
more than 3 million operating cycles

Official source: drivetrain is designed to withstand more than 3 million operating cycles under industrial-use conditions.

Sensing

Proprioceptive feedback
Absolute encoder
Tactile configuration
Optional fingertip sensor (6-axis force/torque sensor)

Configurations

Standard

Communication and control

Communication interface
Ethernet

Software and resources

ROS compatibility
ROS 2
SDK languages
C/C++
Tactile fingertips (optional)

Sensing

Has tactile sensing
Supported

Commercial Status

Status
Commercial
Price
Unknown
Release Date
Unknown
Submit a source or correction