Shadow Robot logoShadow Robot

Shadow Dexterous Hand Super Lite

Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
United Kingdom
Latest parameter verification
2026-10-30
7 DOF
Active degrees of freedom
8
Mechanical joint count
1.8 kg
Hand weight
2
Finger count

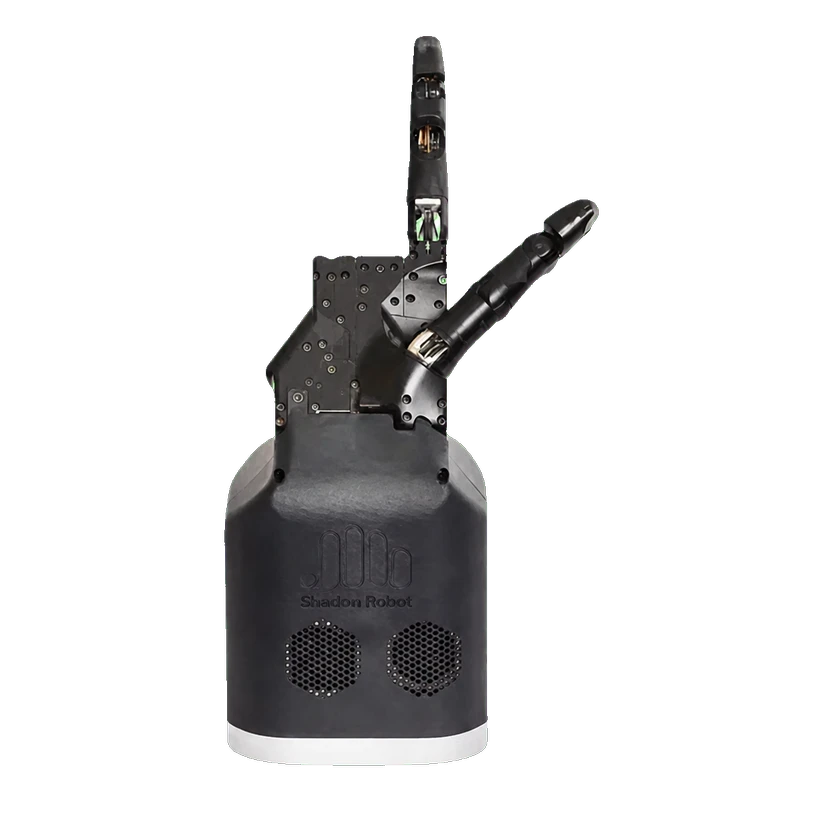
Shadow Dexterous Hand Super Lite is Shadow Robot’s lightweight two-finger dexterous hand for precision manipulation and research. Its tendon-driven mechanism combines seven DC motors, seven active degrees of freedom and eight mechanical joints in a 1.8 kg assembly. The hand includes one IMU and one Shadow Tactile Fingertip as standard, with support for up to two. It runs a 1 kHz host control loop over EtherCAT, is ROS compatible, and is suited to mobile robot arms where low mass matters.

1 / 1Shadow Dexterous Hand Super Lite

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
2
Actuator count
7
Actuator technology
DC motors
Active degrees of freedom
7 DOF
Mechanical joint count
8
Total degrees of freedom
7 DOF

Mechanical and mounting

Mounting interface
Designed for robot-arm integration
Hand weight
1.8 kg

Sensors

Force/Torque Sensor
14 tendon load sensors
IMU
1 IMU
Sensors
1 IMU; 14 tendon load sensors; 1 Shadow Tactile Fingertip standard, up to 2
Tactile Sensor
1 Shadow Tactile Fingertip standard; up to 2 supported

Development and Expansion

Integration Interface
Easily integrated on robot arms

Configurations

Standard

Communication and control

Communication interface
EtherCAT
Control loop rate
1000 Hz

Software and resources

ROS compatibility
Supported

Sensing

Has tactile sensing
Yes
Tactile configuration
1 Shadow Tactile Fingertip standard; up to 2 supported

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Unknown
Submit a source or correction