Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Commercial
Availability
On sale
Release Date
Unknown
Country/Region
Germany
Latest parameter verification
2026-09-15
9 DOF
Active degrees of freedom
20
Mechanical joint count
1.3 kg
Hand weight
5
Finger count

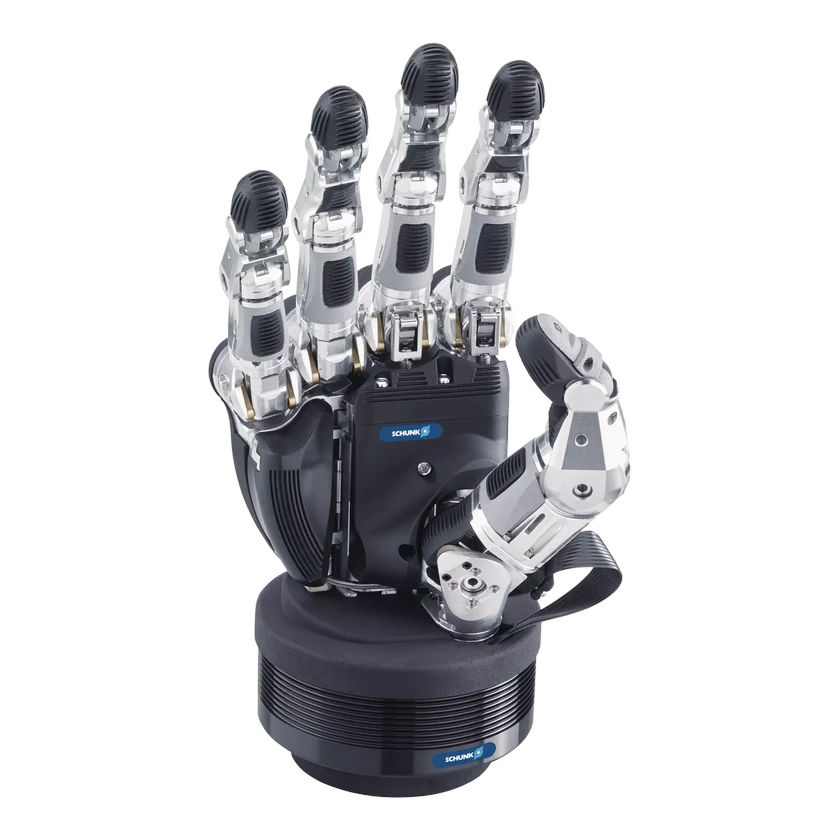
SCHUNK SVH, also called S5FH in research, is a servo-electric five-finger robotic hand. Nine drives move 20 joints, with control electronics integrated into the wrist. It uses 24 V DC power and RS-485 communication, offers left and right versions, and supports ROS1 and ROS2 for grasping and manipulation.

1 / 1SVH

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Actuator count
9
Actuator technology
Servo-electric
Active degrees of freedom
9 DOF
Ingress Protection (IP)
IP20
Mechanical joint count
20
Materials
Coated aluminum-alloy housing; aluminum-alloy fingers

Motion and coordination

Coordination architecture
Nine drive motors control finger and thumb movements; control and power electronics are integrated into the wrist.
Energy domain
DC electric
Hand Payload
Maximum 0.85 kg for human-robot collaboration

Mechanical and mounting

Dimension reference frame
Outer dimensions; identical for right and left hands.
Dimension measurement pose
Right and left hands are laterally inverted.
Length
24.25 cm
Mounting flange standard
FWA115 flat change system
Mounting interface
Bottom connection to the FWK change system; FWK required for operation.
Hand weight
1.3 kg
Width
9.2 cm

Mechanical Structure

Dexterous Hand
5-finger gripping hand
End-Effector
Servo-electric gripping module
Internal Wiring
Power and control cables connect through spring contacts and flat-change adapter boards.
Joint Encoder
Relative joint-angle measurement
Joint Limit
Software end stop recommended just before the mechanical end stop
Maximum current
3.5 A
Operating voltage
24 V

Sensors

Calibration
Homing after each startup; calibrate each degree of freedom separately
Sensors
Relative joint-angle measurement

Battery and Runtime

Power Supply
24 V DC ±5%

Reliability and environment

Operating temperature
10–40

Interaction and Communication

Communication
RS-485
External Port
RS485/USB interface converter (Brainbox)

Development and Expansion

Configuration Options
Right-hand and left-hand versions
Integration Interface
SCHUNK flat change system; RS-485
Operating Modes
No operable elements; operation depends on the software used
Package Contents
Ordered SVH version; translated operating manual; Zarges boxes
Secondary Development (SDK)
ROS1/ROS2 driver and library; Raspberry Pi 4 setup guide

Configurations

Standard

Electrical and integration

Connector type
Spring-loaded pins

Communication and control

Communication interface
RS-485

Software and resources

ROS compatibility
ROS1 and ROS2
Commercial Status

Status
Commercial
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction