qbrobotics logoqbrobotics

qb SoftHand2 Research

Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
Italy
Latest parameter verification
2026-10-30
2 DOF
Active degrees of freedom
19
Mechanical joint count
0.94 kg
Hand weight
5
Finger count

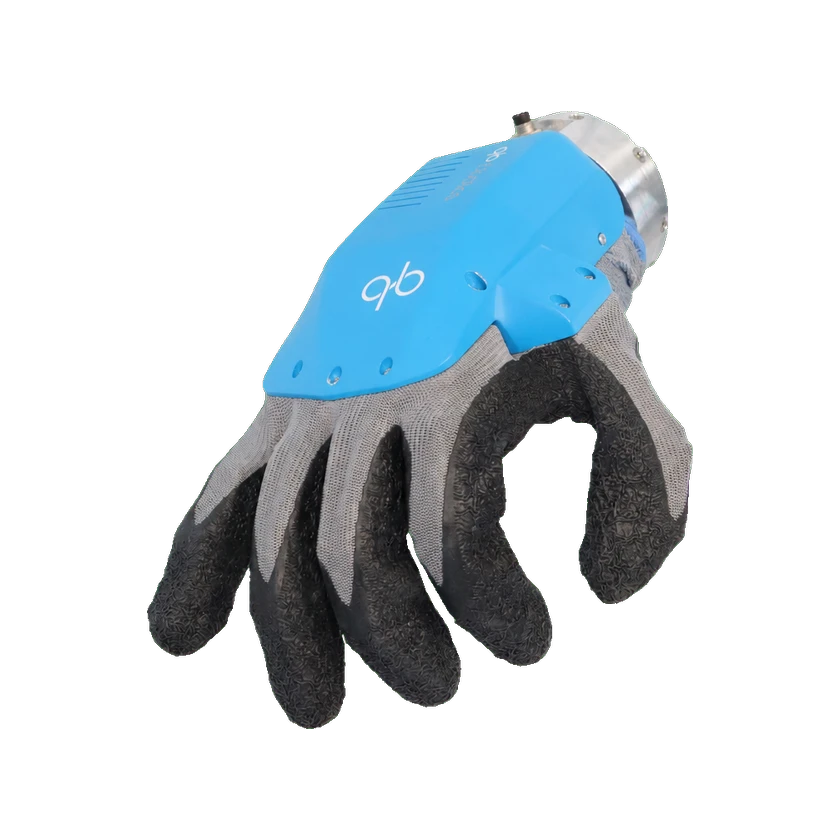
qb SoftHand2 Research is an anthropomorphic soft robotic hand by qbrobotics for research and education. Two motors control 19 anthropomorphic degrees of freedom through two synergies. It supports precision and power grasps and in-hand manipulation, with USB/RS485 connectivity, ROS/ROS2 compatibility, and self-repositioning finger joints.

1 / 1qb SoftHand2 Research

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator count
2
Active degrees of freedom
2 DOF
Mechanical joint count
19
A-weighted Noise Level
62 dB(A)
Total degrees of freedom
19 DOF

Motion and coordination

Synergy count
2

Mechanical and mounting

Height
25.3 cm
Length
19.1 cm
Mounting interface
ISO 9409-1-50-4-M6
Hand weight
0.94 kg
Width
7.7 cm

Electrical and integration

Operating voltage
23.1–24.8 V
Rated power
22 W

Battery and Runtime

Max Power
38 W

Reliability and environment

Operating temperature
-5–50 °C

Configurations

Standard

Electrical and integration

Connector type
M8 8-pin, A-coded circular connector

Communication and control

Communication interface
USB / RS485
Communication protocol
RS485
Feedback signals
Motor position and motor current

Software and resources

CAD availability
Simplified CAD models available
ROS compatibility
ROS and ROS2 compatible

Sensing

Proprioceptive feedback
Motor position and motor current

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Unknown
Submit a source or correction