OceanTrix Robotics logoOceanTrix Robotics

Dexterous Hand

Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
Unknown
Latest parameter verification
2026-10-30
6 DOF
Active degrees of freedom
5
Finger count

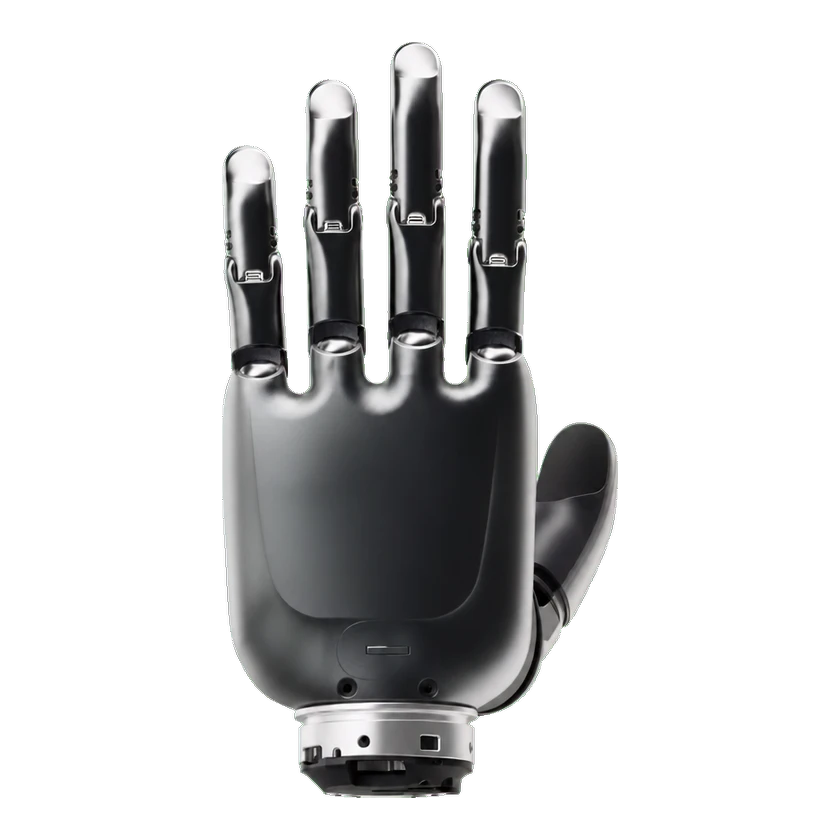
OceanTrix Robotics Hand R1 is a five-finger dexterous hand for research, education and industrial automation. It uses aviation-grade aluminum and food-grade plastic, supports Python/C++ control over 485/CANfd, offers six degrees of freedom and up to 30 kg whole-hand load, with an optional 13-point tactile sensor upgrade.

1 / 1Hand R1

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Actuator count
6
Frame Material
Aviation-grade aluminum components for key parts
Active degrees of freedom
6 DOF
Materials
Aviation aluminum alloy and food-grade plastic

Mobility & Payload

Absolute Position Accuracy
0.1 mm

Manufacturer states accuracy; repeatability and measurement method are not specified / 厂商标注精度,未给重复精度或测量方法 / メーカー公称精度、繰返し精度・測定方法は未記載

Hand Payload
One finger: 6 kg

Maximum load per finger.

Hand Payload
Whole hand: 30 kg

Maximum load per hand.

Mechanical and mounting

Grip stroke
0–11.3 cm

Distance from index finger to thumb / 食指至拇指距离 / 人差し指と親指の間隔

Mechanical Structure

Dexterous Hand
All-in-one dexterous hand
Dexterous Hand Model
Robotic Hand R1
Joint Type
Motor-actuated
Operating voltage
9.5–28 V

Sensors

Tactile Sensor
Optional tactile upgrade with 13 touch sensors

The product heading and technical table identify touch sensing as optional.

Reliability and environment

Operating temperature
-10–40 °C

Interaction and Communication

Communication
RS485 and CAN FD
External Port
Serial port
OTA Update
Firmware OTA update
System Response Time
Control interval: ≤0.01 s

Development and Expansion

Configuration Options
Optional touch sensor upgrade
Integration Interface
Connect easily to your current setup
Operating Modes
Independent motor position commands, normalized 0–100 from fully open to fully closed
Secondary Development (SDK)
Python and C++ control interfaces
Secondary Development (SDK)
Windows 10/11, macOS 10.15 or later, Ubuntu 20/22; Python 3.9–3.12
Workflow Integration
Educational robot; Go-playing robot; factory automation

Configurations

Hand R1

Communication and control

Communication interface
RS485
Communication interface
CAN FD
Hand R1 — optional tactile sensing

Communication and control

Communication interface
RS485
Communication interface
CAN FD

Sensing

Has tactile sensing
Supported (optional tactile sensing)

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Unknown
Submit a source or correction