Neurocean Technologies Inc. logoNeurocean Technologies Inc.

Industrial Dexterous Hand

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Prototype
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-10-30
25 DOF
Active degrees of freedom
5
Finger count

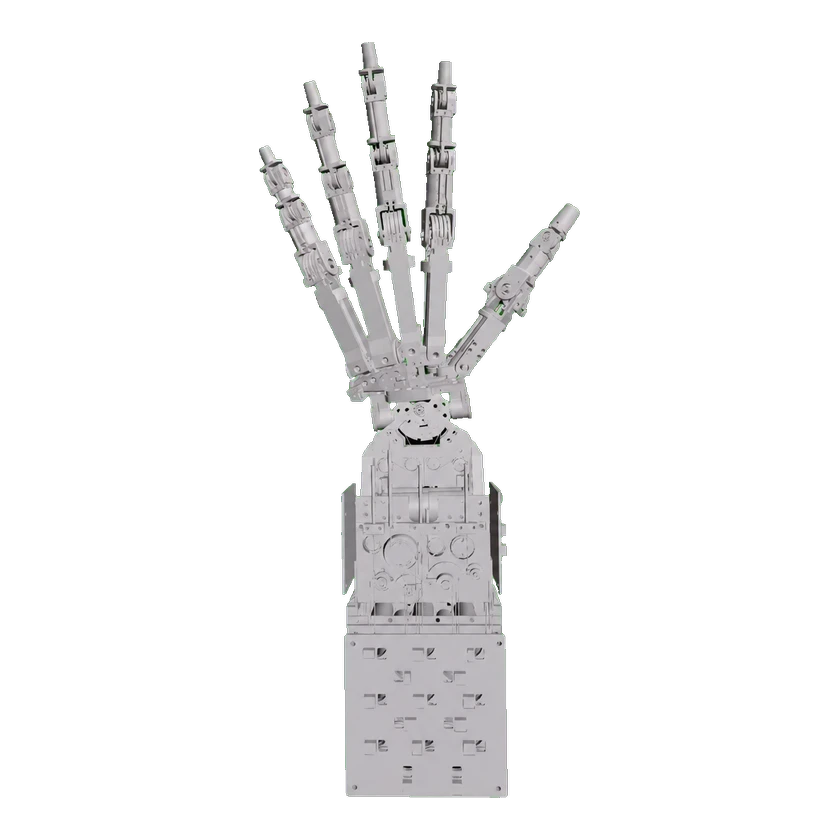
Neurocean's 25-DOF Industrial Dexterous Hand is a five-finger active hand for robot manipulation, laboratory, production-line and hazardous-environment automation. The basic version supports programmed, remote, teach-and-playback and neuromorphic control, with TCP/IP asynchronous communication and a multilingual SDK.

1 / 125-DOF Industrial Dexterous Hand

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator technology
Coreless motors
Active degrees of freedom
25 DOF
Total degrees of freedom
25 DOF

Motion and coordination

Coordination architecture
Host and lower-controller architecture with core control, actuator-drive and information-acquisition submodules

Mechanical and mounting

Mounting interface
Mechanical interface and SDK

Mechanical Structure

Dexterous Hand
Five-finger dexterous hand
Dexterous Hand Model
Basic version
End-Effector
Five-finger active dexterous hand
Joint Sensor Type
Joint position sensing
Load Cycles
1000000

Manufacturer transmission-cycle claim; test conditions unspecified / 厂商传动循环标称,未披露试验条件 / メーカー公称の伝達機構サイクル、試験条件は未記載

Sensors

Force/Torque Sensor
Force/torque information acquisition
Sensors
Joint position, force/torque and tactile information acquisition; no tactile sensing in the basic version
Tactile Sensor
No tactile sensing in the basic version

Interaction and Communication

Communication
TCP/IP with dedicated session-layer and application-layer protocols
Communication
Asynchronous communication with callbacks
Remote Controller
Remote control supported
Tactile Feedback
None (basic version)

Development and Expansion

App Platform
Windows/Linux
Configuration Options
Basic version: five fingers, active joints, no tactile sensing and no skin
Integration Interface
TCP/IP asynchronous communication, mechanical interface, and SDK
Operating Modes
Programmed, remote, demonstration and brain-inspired control
Operating Modes
Joint angle, angular velocity, stiffness and torque commands
Operating Modes
Motor voltage, current and direction commands
Operating Modes
Torque-priority or position-priority passthrough control
Operating Modes
Lower-controller open/closed-loop modes and host closed-loop control
Secondary Development (SDK)
C++, C#, Python and Java development interfaces
Secondary Development (SDK)
Windows and Linux host platforms
Secondary Development (SDK)
Online compilation and execution with real-time hand status monitoring
Teleoperation
Supported

Configurations

Basic Version

Communication and control

Communication interface
TCP/IP
Communication protocol
Proprietary session-layer and application-layer protocols
Control mode
Remote control
Control mode
Demonstration control
Control mode
Brain-inspired control
Control mode
Programmed control

Software and resources

SDK languages
C#
SDK languages
Python
SDK languages
Java
SDK languages
C++

Sensing

Has tactile sensing
No
Tactile configuration
None (basic version)

Commercial Status

Status
Prototype
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction