
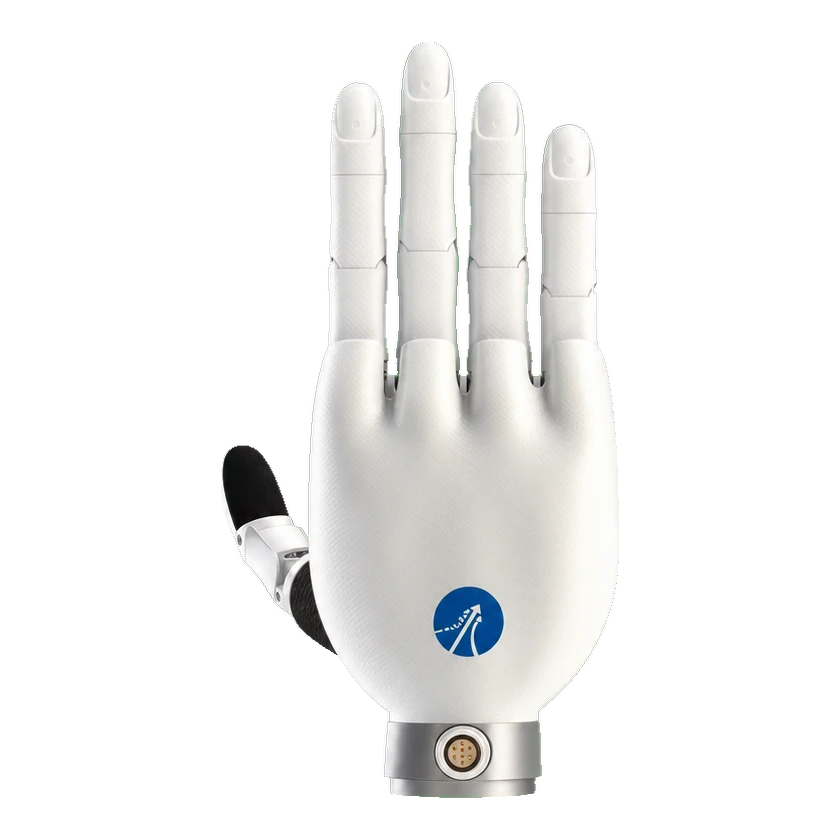
DH2015
Communication and control
Communication interface
EtherCAT
Control mode
Hybrid force-position control
Software and resources
ROS compatibility
ROS
SDK languages
C++
SDK languages
Python
Sensing
Has tactile sensing
Yes
Tactile configuration
508-point tactile sensor array