
Standard
Communication and control
Communication interface
CAN FD
Communication protocol
CAN FD
 HITBOT
 eHand-6 is a five-finger dexterous hand for industrial and embodied-intelligence applications. It offers six degrees of freedom, up to 10 N gripping force, a 5 kg pulling load, CAN FD communication, and optional five-channel tactile feedback for 3–10 N dynamic force control.
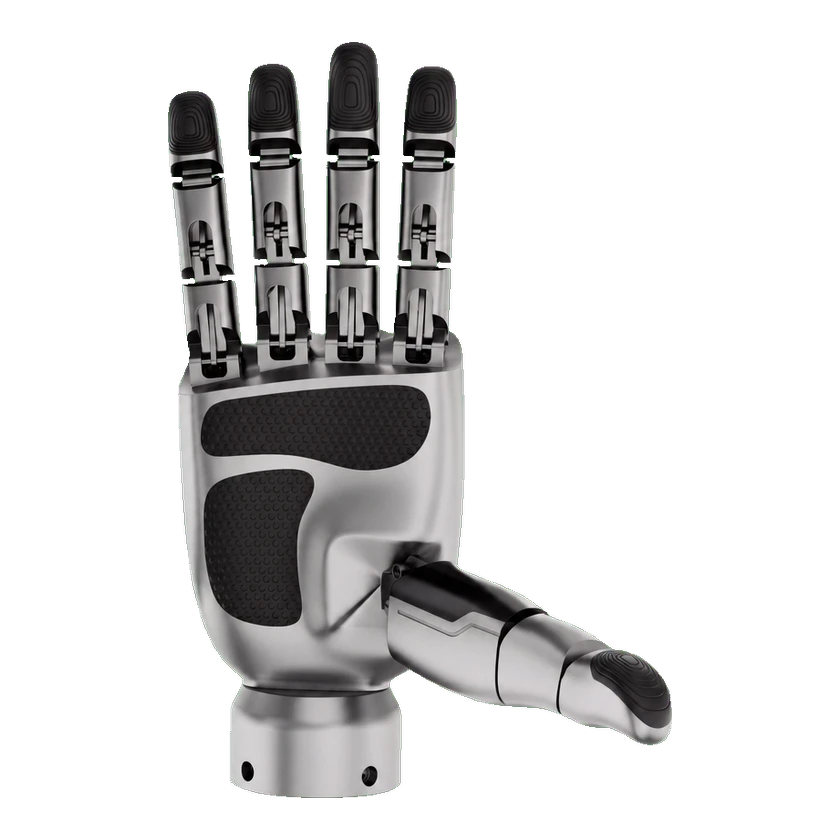
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
No related products recorded yet.