HITBOT logoHITBOT

HITBOT eHand-16

High-DOF model; not the eHand-6.

eHand-16

Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Publicly demonstrated prototype
Availability
Not disclosed
Release Date
Apr 22, 2026
Country/Region
China
Latest parameter verification
2026-10-31
16 DOF
Active degrees of freedom
5
Finger count

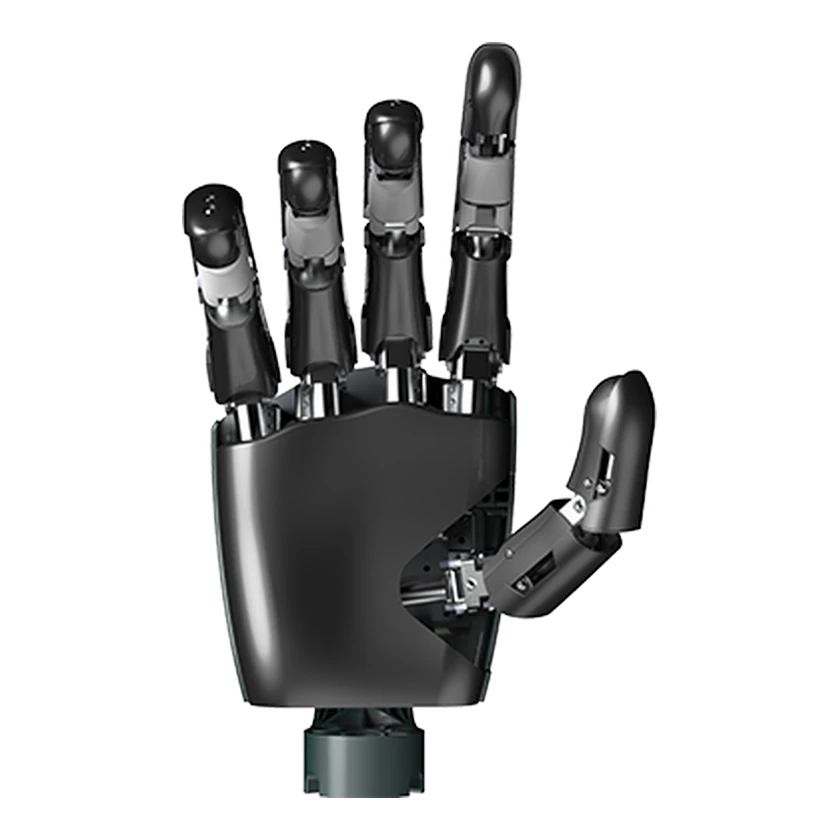
HITBOT eHand-16 is a five-finger hand with 20 DOF: 16 active and 4 passive. The manufacturer specifies embedded fingertip tactile arrays, joint torque and temperature sensors, CAN FD communication, and a maximum 15 kg payload for continuous gripping in self-locking mode.

1 / 1eHand-16

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Active degrees of freedom
16 DOF
Passive degrees of freedom
4 DOF
Total degrees of freedom
20 DOF

Mobility & Payload

Hand Payload
15 kg

Manufacturer maximum payload 15 kg, supporting continuous gripping in self-locking mode; not a general dynamic lifting condition.

Mechanical Structure

Dexterous Hand
Five-finger high-DOF dexterous hand
Dexterous Hand Model
eHand-16

Sensors

Force/Torque Sensor
Joint torque sensors
Sensors
Fingertip tactile arrays; joint torque sensors; temperature sensors
Tactile Sensor
Embedded fingertip tactile arrays

Battery and Runtime

Cycle Life
200000

Performance and tasks

Operating System
HITBOT OS
Repeatability
0.9 mm
Software Algorithm
Adaptive dexterous manipulation; multimodal posture control

Interaction and Communication

Tactile Feedback
Multimodal tactile feedback

Development and Expansion

Operating Modes
Self-locking continuous grasping; adaptive dexterous manipulation; multimodal posture control
Secondary Development (SDK)
Multiple APIs; documentation and example programs

Configurations

Standard configuration

Communication and control

Communication protocol
CAN FD

Manufacturer labels CANFD as a communication protocol; the brochure does not specify connector, pinout or a separate physical-interface variant.

Software and resources

Simulation formats
MuJoCo

Sensing

Has tactile sensing
Yes
Tactile configuration
Embedded fingertip tactile arrays; joint torque and temperature sensors

Commercial Status

Status
Publicly demonstrated prototype
Price
Price not disclosed
Release Date
Apr 22, 2026
Submit a source or correction