
 HighTorque Robotics
HTCP-4531-06-CYC
- Output torque · Rated
- 2 N·m
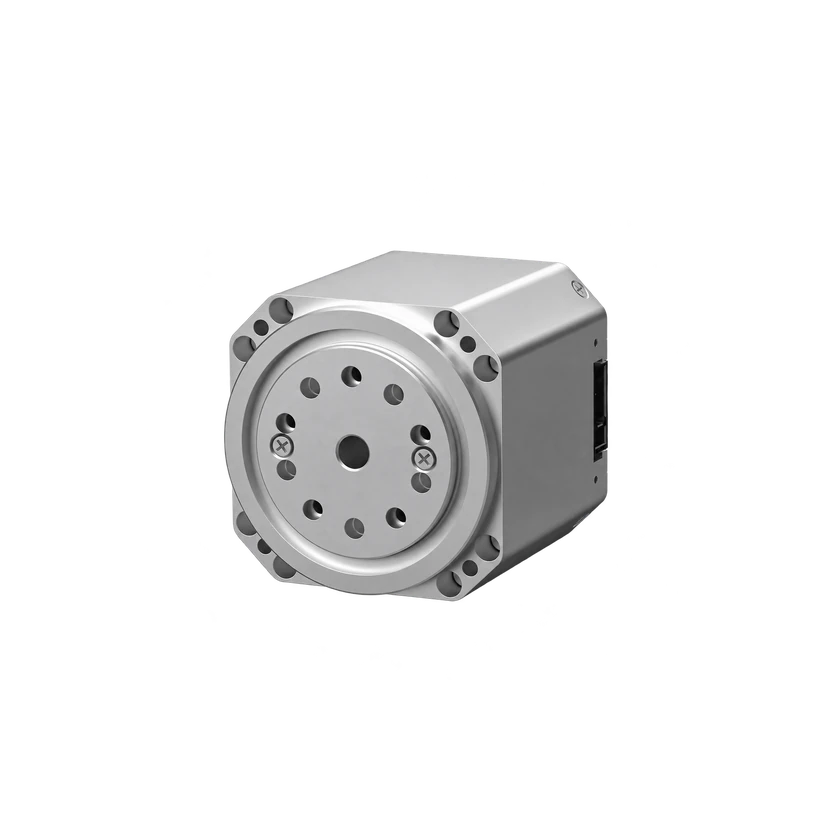
HTCP-4531-06-CYC is a HighTorque hollow cycloidal joint module with a reduction ratio of 31, rated output torque of 2 N·m and mass of 237 g. It uses a brushless DC motor and dual absolute encoders, supports CAN/CAN-FD communication. The module can be ordered from the official HighTorque store.
Technical specifications
Output & transmission
- Output torque · Rated
2 N·m
Scope not bound
- Output torque
10 N·m
Scope not bound
- Output speed · Rated
40 rpm
Scope not bound
- Output speed · No load
160 rpm
Scope not bound
- Backlash · Less than
≤10 arcmin
Scope not bound
Electrical
- Operating current · Rated
0.7 A
Scope not bound
- Operating current · Peak
10 A
Scope not bound
Encoders & feedback
- Encoder type
Dual absolute encoders
Scope not bound
- Encoder resolution
14 bit
Scope not bound
- Encoder resolution
14 bit
Scope not bound
Communication & control
- Communication interface
CAN-FD / CAN
Scope not bound
- Control loop rate
3000 Hz
Scope not bound
Construction & components
- Ordering code
HTCP-4531-06-CYC
Scope not bound
- Motor type
Brushless DC motor
Scope not bound
- Motor integration
Integrated
Scope not bound
- Reducer integration
Integrated
Scope not bound
- Encoder integration
Integrated
Scope not bound
Model-level records · configuration applicability unverified
- Height
- 4.49 cm
- Length
- 4.4 cm
- Weight
- 0.237 kg
- Width
- 4.4 cm
- Gear Ratio
- 31:1
- Operating voltage · Rated
- 24 V
- Operating voltage
- 12–50.4 V
- Rated power · Rated
- 8.5 W
- Reducer Type
- Cycloidal reducer
- System Response Time
- 0.00014 s
Source · 2
2026-11-14
Communication interface · CAN-FD · p. 14
Communication interface · CAN · p. 14
Control loop rate · 3000 Hz · p. 14
Backlash · ≤10 arcmin · p. 14
Encoder resolution · 14 bit · p. 14
Operating current · 0.7 A · p. 14
Operating current · 10 A · p. 14
Ordering code · HTCP-4531-06-CYC · p. 14
Output speed · 40 rpm · p. 14
Output speed · 160 rpm · p. 14
Output torque · 2 N·m · p. 14
Output torque · 10 N·m · p. 14
Height · 4.49 cm
Length · 4.4 cm
Weight · 0.237 kg
Width · 4.4 cm
Gear Ratio · 31:1
Operating voltage · 24 V
Operating voltage · 12–50.4 V
Rated power · 8.5 W
System Response Time · 0.00014 s
2026-11-14
Encoder type · Dual absolute encoders · HTCP series introduction
Encoder integration · Integrated · HTCP series introduction
Motor integration · Integrated · HTCP series introduction
Reducer integration · Integrated · HTCP series introduction
Motor type · Brushless DC motor · HTCP series introduction
Reducer Type · Cycloidal reducer
Compare family models
Choose 2–4 configurations
Compare selected configurations| Technical specifications | HTCP-5031-06-CYCStandard | HTCP-4531-06-CYCStandard |
|---|---|---|
| Communication interface | CAN-FDScope not bound | CAN-FDScope not bound |
| Communication interface | CANScope not bound | — |
| Backlash · Less than | ≤10 arcminScope not bound | ≤10 arcminScope not bound |
| Communication interface | — | CANScope not bound |
Commercial Status
Related Entities
No related products recorded yet.