Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-10-30
6 DOF
Active degrees of freedom
11
Mechanical joint count
≤ 1.25 kg
Hand weight
5
Finger count

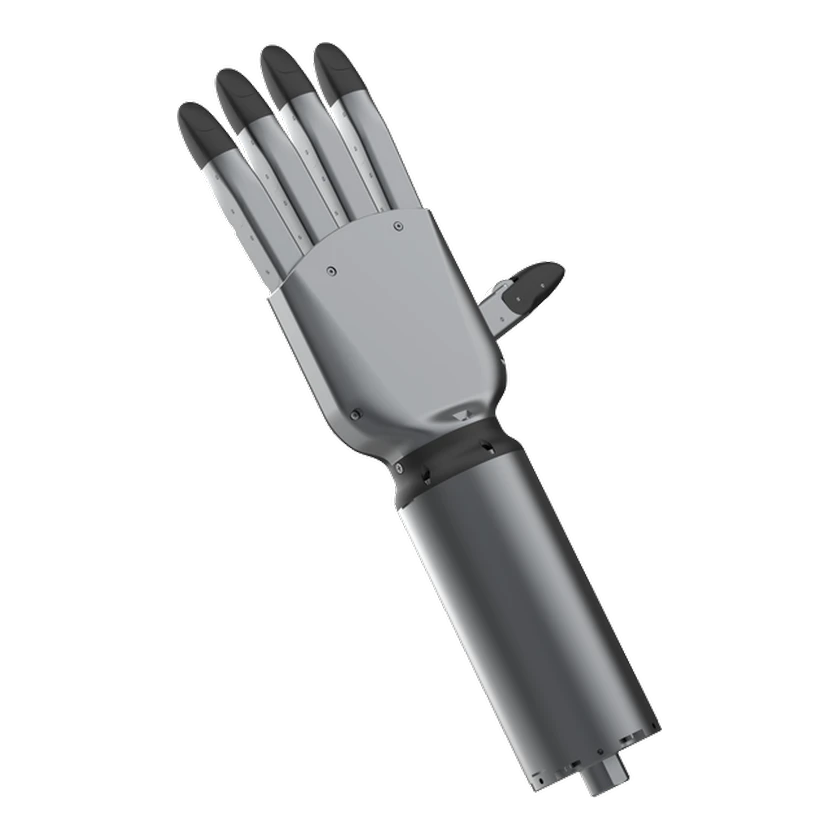
WA100 is a five-finger underwater robotic hand from HeymanDex with six active degrees of freedom, titanium and fluororubber construction, and position and current feedback. Its development tools support research and integration with underwater manipulators for sampling and wet-environment tasks.

1 / 1WA100

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Physical Specifications

Finger count
5
Active degrees of freedom
6 DOF
Ingress Protection (IP)
IP68+
Mechanical joint count
11
Materials
Titanium alloy; fluororubber
Joint Motion Range
0–90 °

Mechanical and mounting

Hand weight
≤ 1.25 kg

Fully sealed structure.

Electrical and integration

Operating voltage
12–36 V

Battery and Runtime

Power Supply
12–36 V / 5 A

Compute Platform

Software Algorithm
Control software with independent multi-joint actuation and millisecond-level feedback

Development and Expansion

App Platform
Windows / Linux
Integration Interface
Compatible with ROVs and underwater manipulators; watertight connectors
Secondary Development (SDK)
C++ / Python SDK
Teleoperation
Apple Vision Pro spatial mapping

Configurations

WA100

Communication and control

Communication interface
RS485

Variant not bound

The official source lists RS485 / CAN but does not bind interfaces to a specific hardware variant.

Communication interface
CAN

Variant not bound

The official source lists RS485 / CAN but does not bind interfaces to a specific hardware variant.

Feedback signals
Position
Feedback signals
Current

Standard version

Deep-sea engineering version

Commercial Status

Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction