Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-10-30
16 DOF
Active degrees of freedom
≤ 1.5 kg
Hand weight
5
Finger count

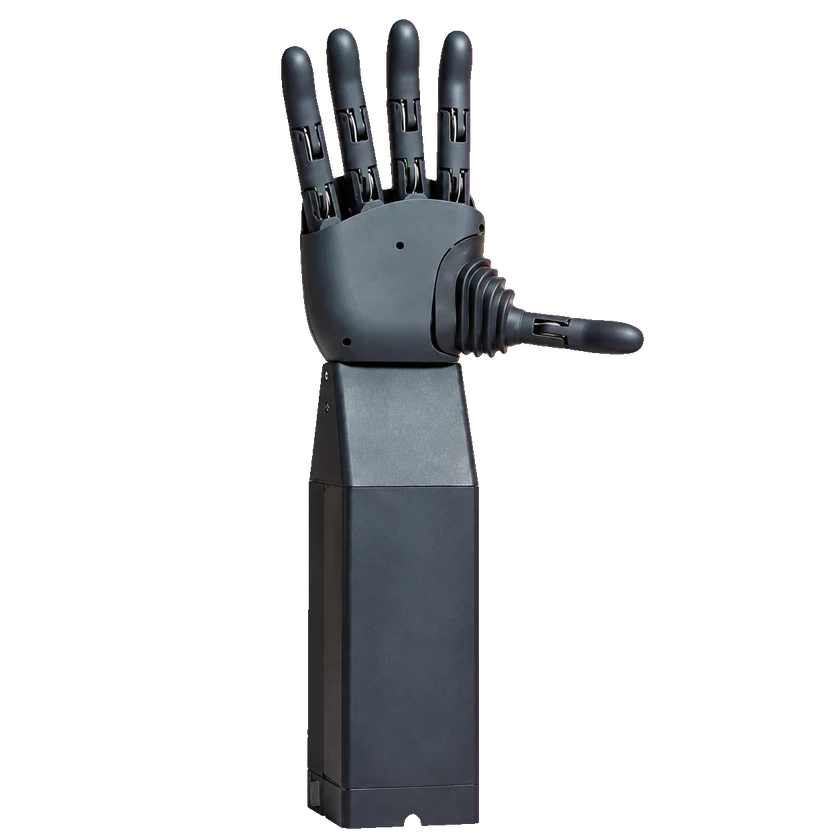
RE100 is a five-finger research and education hand from HeymanDex with sixteen active degrees of freedom and position and current feedback. It offers development tools, graphical programming and simulation integration, plus visual hand tracking and headset teleoperation for demonstrations and robot learning.

1 / 1RE100

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Active degrees of freedom
16 DOF
Materials
Aluminum alloy; POM

Mechanical and mounting

Hand weight
≤ 1.5 kg

Includes drive and housing.

Electrical and integration

Operating voltage
12–48 V

Software and resources

Teleoperation support
Supported: monocular hand tracking, Apple Vision Pro and Meta Quest 3

Performance and tasks

Repeatability
±0.5 mm

Reliability and environment

Operating temperature
-10–50 °C

Development and Expansion

App Platform
Windows / Linux (x86 / ARM)
Graphic Programming
RE100-Blockly
Integration Interface
ROS2 / URDF / MoveIt2
Secondary Development (SDK)
C++ / Python SDK
Teleoperation
Monocular hand tracking; Apple Vision Pro, Meta Quest 3

Configurations

RE100

Communication and control

Communication interface
RS485

Variant not bound

The official source lists RS485 / CAN but does not bind interfaces to a specific hardware variant.

Communication interface
CAN

Variant not bound

The official source lists RS485 / CAN but does not bind interfaces to a specific hardware variant.

Feedback signals
Position
Feedback signals
Current

Software and resources

ROS compatibility
ROS 2 (URDF, MoveIt 2)
SDK languages
C++
SDK languages
Python

Commercial Status

Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Submit a source or correction