
 Franka Robotics
Franka Research
Franka Research 3
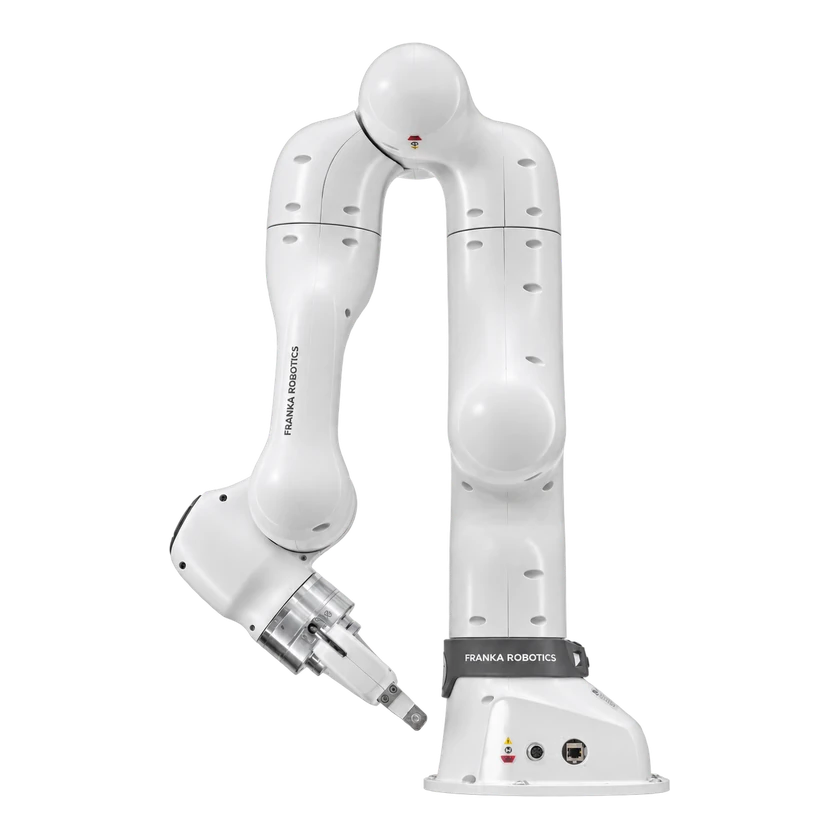
Franka Research 3 is a force-sensitive, seven-axis research arm with a 3 kg payload and 855 mm reach. Franka lists a DROID-based setup as a LABS data-collection reference.
Hardware Specification
Collection capabilities
Versions and commercial status
Software, export and openness
Degrees of freedom and drive
Mobility & Payload
Development support
Franka Research 3Current model
Conditional accessFR3 is explicitly listed in the manufacturer FCI compatibility matrix. Developer control requires the FCI feature installed, matching robot-system/libfranka/server versions, a real-time-capable Linux workstation and stable Ethernet. This pinned C++ profile is distinct from Desk/Apps and optional Python/ROS integrations; FCI control is exclusive.
Development configuration: FR3 FCI · pinned libfranka C++
FR3 is explicitly listed in the manufacturer FCI compatibility matrix. Developer control requires the FCI feature installed, matching robot-system/libfranka/server versions, a real-time-capable Linux workstation and stable Ethernet. This pinned C++ profile is distinct from Desk/Apps and optional Python/ROS integrations; FCI control is exclusive.
Development capabilities
Documented constraints
- The C++ API provides joint-position (rad), joint-velocity (rad/s), Cartesian pose/velocity and joint torque (N·m) commands. Torque excludes robot-side gravity/friction compensation. The pinned joint-impedance example computes PD position/velocity feedback plus model Coriolis torque in an external real-time callback; this is a software controller, not a motor MIT packet. Version compatibility and robot torque/velocity/acceleration/rate limits apply. No hardware or control example was executed.
- The supplied libfranka Torques vector excludes gravity and friction terms because the FCI torque interface is gravity/friction compensated. This describes the command convention; it does not mean compensation is absent. The pinned impedance example separately adds model Coriolis torque in its external PD controller.
Sources · 4
- Officialfrankarobotics.github.io ↗Verified: 2026-11-06
- Officialraw.githubusercontent.com ↗Verified: 2026-11-06
- Officialraw.githubusercontent.com ↗Verified: 2026-11-06
- Officialraw.githubusercontent.com ↗Verified: 2026-11-06
Open source & build resources
Software
Partially availableExamples or supporting tools are available; this does not establish access to the core system.
Hardware design
Not verifiedThere is not enough verified evidence to establish this dimension.
Build resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Code | frankarobotics/libfranka pinned source · Apache-2.0 GitHub · frankarobotics/libfranka License applies to the reviewed repository revision only. Robot firmware, hardware, FCI entitlement, third-party dependencies and other versions are separate. Auxiliary software resource; no whole-robot open-source claim. | Apache-2.0 | fr3_fci_libfranka_e88d08f6 | Open GitHub |
Commercial Status
Related Entities
No related products recorded yet.
Timeline
- Robot releaseFranka Research 3