
Standard configuration
Communication and control
Communication interface
RS485
Communication protocol
Modbus-RTU
 DH-Robotics
DH-5-6 is a modular five-finger hand from DH-Robotics for education, research, data collection and object handling. It has 6 active and 11 total degrees of freedom, a stated 0.8 s cycle time and Modbus-RTU/RS485 communication. Optional fingertip and palm tactile arrays support object recognition and adaptive grasping.
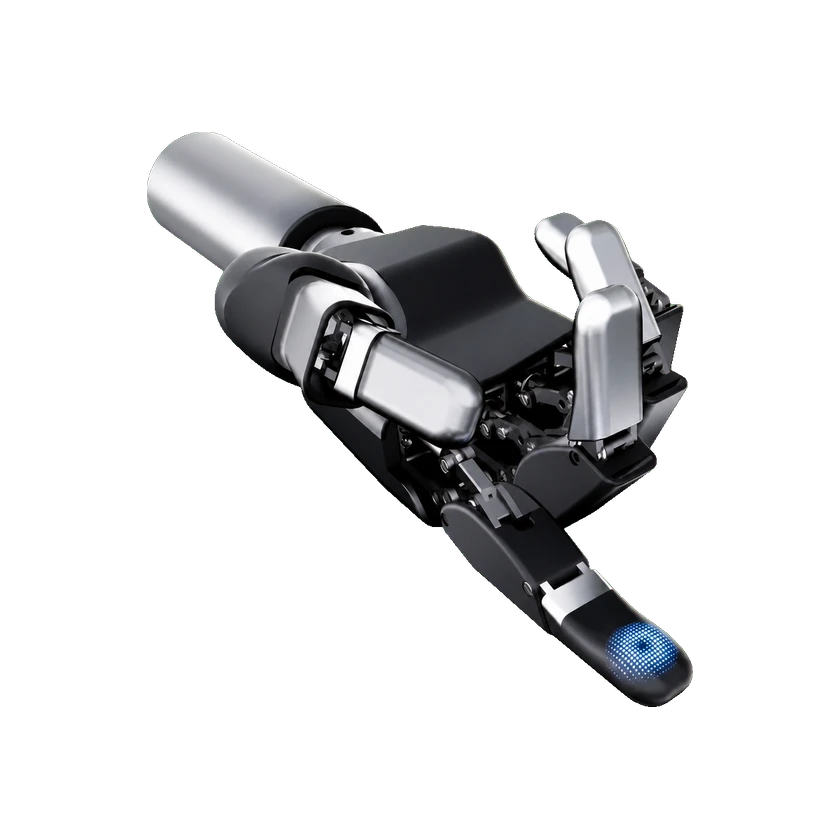
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Official DH-5-6 specification.
Official DH-5-6 specification.
Vertical dimension 236 mm in the official open-hand drawing; the 3.5 mm local dimension at the bottom is not added again.
Official DH-5-6 specification.
DH-5-6 model-wide communication specification; tactile sensing is an optional array configuration.
DH-5-6 model-wide communication specification; tactile sensing is an optional array configuration.
Sensor-specific figures; not whole-hand command latency or hand mechanical cycle life.
No related products recorded yet.