
 DEXROBOT
DexHand021 Concept
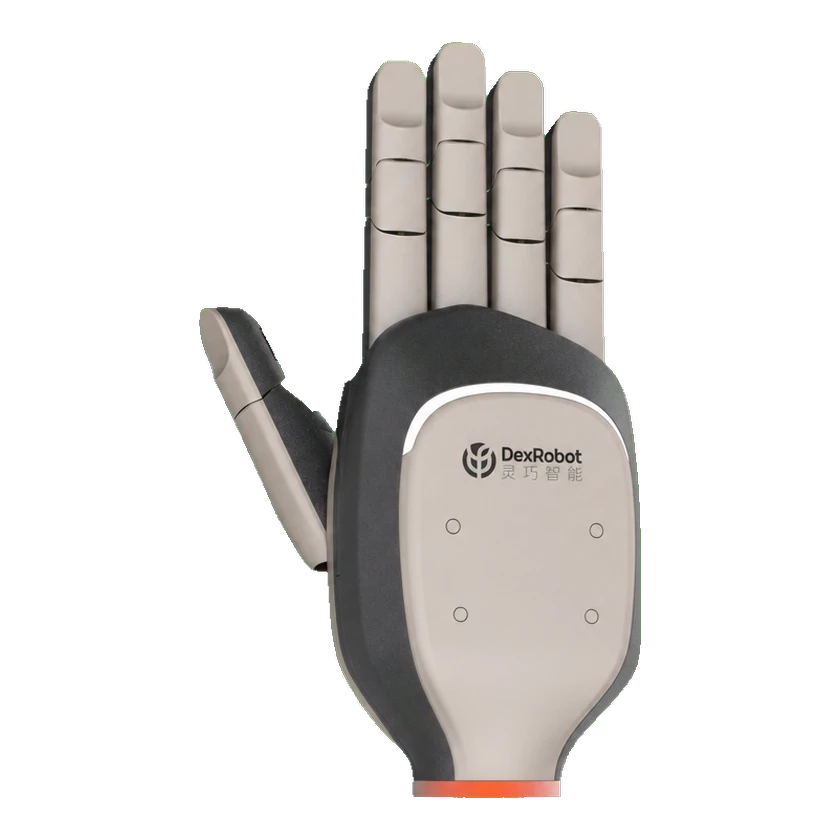
DexHand021 Concept is a five-finger robotic hand developed by DEXROBOT as a high-degree-of-freedom, multimodal open platform. Official materials specify 18 degrees of freedom and individually replaceable fingers for maintenance and development. The company also states that holding a posture requires no power and that the hand supports multiple robot protocols and data formats.
Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Degrees of freedom and drive
The official Concept page states 18 DOF without distinguishing active axes. The unsupported active-DOF number is withdrawn; its original raw value, source and date are retained. The separately recorded total remains 18.
Mechanical Structure
Sensors
Development and Expansion
Commercial Status
Related Entities
No related products recorded yet.