Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
On sale
Release Date
Apr 16, 2025
Country/Region
China
Latest parameter verification
2026-10-30
6 DOF
Active degrees of freedom
5
Finger count

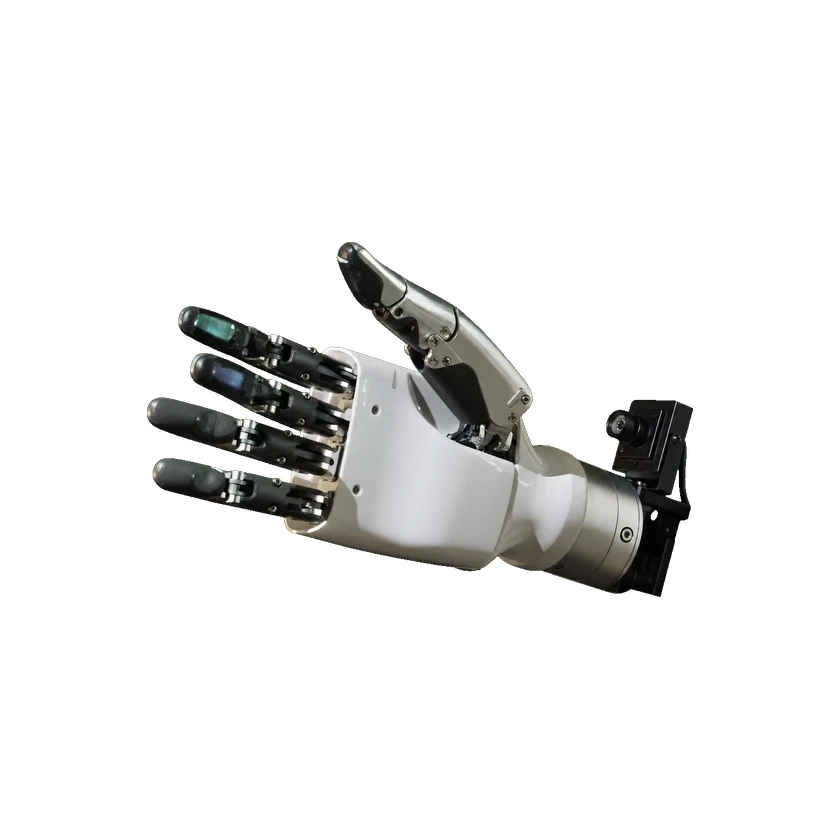
DM-Hand1 is a five-finger tactile-sensing hand developed by Daimon Robotics, integrating millimeter-thick vision-based tactile sensors at the fingertips with hybrid force-position control for grasping. According to company release material, it senses hardness, texture, contact-force distribution and contact events to inform grasp-force adjustment. The design combines anthropomorphic fingers with contact perception for compliant handling of fragile objects and precision-part assembly.

1 / 1DM-Hand1

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5

DM-Hand1 hardware documented in the manufacturer-issued April 2025 release. No numerical DOF or interface specification is inferred.

Active degrees of freedom
6 DOF
Total degrees of freedom
11 DOF

Motion and coordination

Coordination architecture
perception-operation-learning integration

Mechanical Structure

Dexterous Hand
five-finger dexterous hand with multidimensional tactile sensing
Dexterous Hand Model
DM-Hand1
End-Effector
human-like hand end effector

Sensors

Force/Torque Sensor
fingertip three-dimensional force-field sensing
Sensors
multidimensional vision-based tactile sensing
Tactile Sensor
millimeter-level-thickness vision-based tactile sensor
Vision Sensor
fingertip visual sensing

Compute Platform

Software Algorithm
hybrid position-force control

Interaction and Communication

Tactile Feedback
material properties, texture, distributed contact force and contact events
Visual Recognition
hardness, texture, distributed contact force and contact events

Development and Expansion

Operating Modes
adaptive gripping force control; delicate handling; precision assembly
Workflow Integration
perception-operation-learning integration

Configurations

DM-Hand1 — Documented launch specification

Communication and control

Control mode
Hybrid position-force control

DM-Hand1 hardware documented in the manufacturer-issued April 2025 release. No numerical DOF or interface specification is inferred.

Sensing

Has tactile sensing
Yes

DM-Hand1 hardware documented in the manufacturer-issued April 2025 release. No numerical DOF or interface specification is inferred.

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Apr 16, 2025
Submit a source or correction