Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
United States
Latest parameter verification
2026-10-30
8 DOF
Active degrees of freedom
4
Finger count

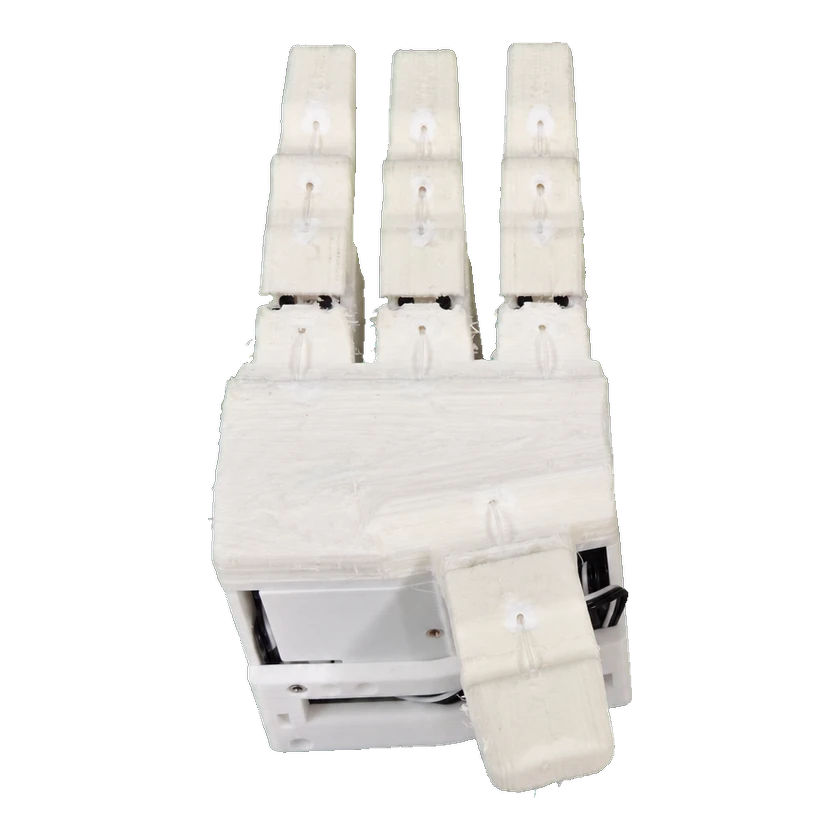
LEAP Hand V2 is a highly dexterous four-finger research hand with 8 degrees of freedom per hand; it is also specified with 16 total DOF and 8 powered motors. It uses Feetech SCServo servos, a 7.6 V supply, and USB-C serial connectivity. The hand offers tendon-based joint commands, PID control with a current limit, position, velocity, and motor-current feedback, and automatic current-based calibration saved to CSV. Python and ROS 2 APIs, a URDF with simulation examples, and Manus Glove motion-capture teleoperation connect the hand to robot-learning workflows.

1 / 1LEAP Hand V2

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
4
Actuator count
8
Actuator technology
Feetech SCServo servos
Active degrees of freedom
8 DOF
Materials
Hybrid rigid-soft; 3D-printed palm and fingers
Total degrees of freedom
16 DOF
Transmission mechanism
Under-actuated tendon-driven
Actuator Model
Feetech servos
Joint Motion Range
0–85.9437° per joint

Motion and coordination

Control channel count
8 control channels
Coordination architecture
LEAP Hand MCP joint
Energy domain
Electric power

Mechanical and mounting

Mounting interface
Gripper-style or wrist-style mount

Electrical and integration

Dexterous Hand
Highly dexterous robotic hand
End-Effector
Robotic hand
Joint Type
universal dexterous MCP joint
Operating voltage
7.6 V

Communication and control

Calibration method
Automatic current-based calibration saved to CSV
Sensors
Position, velocity, and motor current feedback

Software and resources

Power Supply
7.6 V power supply
Teleoperation support
Manus Glove motion-capture teleoperation

Compute Platform

Operating System
Ubuntu serial-by-id integration
Software Algorithm
Linear tendon control from summed finger-joint actuation

Interaction and Communication

Communication
USB-C serial via /dev/serial/by-id
External Port
USB-C

Development and Expansion

Integration Interface
USB serial via /dev/serial/by-id
Operating Modes
PID control with a current limit cap
Secondary Development (SDK)
Python and ROS 2 APIs
Workflow Integration
URDF with simulation examples for multiple engines

Configurations

Standard

Electrical and integration

Connector type
USB-C

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

Communication and control

Communication interface
USB

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

Software and resources

ROS compatibility
ROS 2

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

SDK languages
Python

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

LEAP Hand v2 — LEAP Touch resistive fingertips

Electrical and integration

Connector type
USB-C

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

Communication and control

Communication interface
USB

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

Software and resources

ROS compatibility
ROS 2

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

SDK languages
Python

Official v2 SDK hand-control connection; does not establish an additional tactile-board interface or driver.

Sensing

Has tactile sensing
Supported (LEAP Touch fingertip extension)

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Unknown
Submit a source or correction