Chundong Touch logoChundong Touch

Mozart 1.0

First-generation Mozart record; a current CDH-MO-5-16-E0 datasheet is not a confirmed revision mapping for every historical parameter.

Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verification
2026-10-31
6 DOF
Active degrees of freedom
0.84 kg
Hand weight
5
Finger count

Mozart 1.0 is Chundong Touch's bionic five-finger dexterous hand. It has 16 degrees of freedom—six active and ten passive—and 3D tactile sensing. The product targets precision operations in industrial automation, medical collaboration, and service robotics for embodied-intelligence applications.
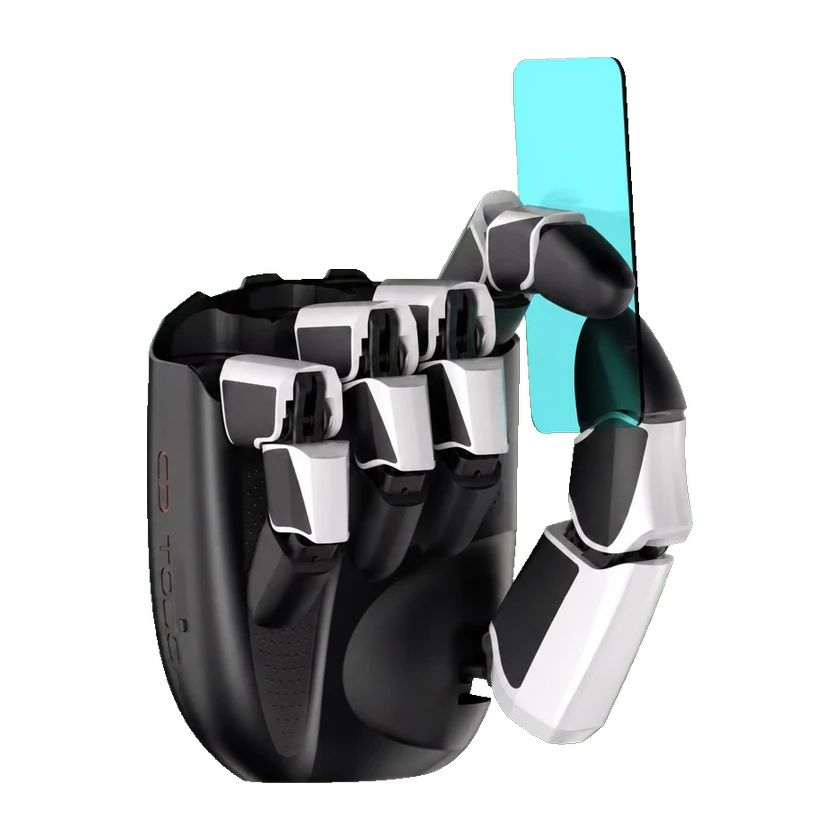
1 / 1Mozart 1.0

Technical specifications

Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.

Degrees of freedom and drive

Finger count
5
Actuator technology
Full-drive hollow-cup motors
Active degrees of freedom
6 DOF
Passive degrees of freedom
10 DOF
Dimensions (Standing)
15 cm
Dimensions (Standing)
20.12 cm
Dimensions (Standing)
0.45 cm

The historical report gives 4.5 mm thickness (stored as 0.45 cm); the current official CDH-MO-5-16-E0 table gives 41.5 mm. Its revision mapping to this first-generation record is unconfirmed. The old figure is retained as reported, not recertified as current.

Total degrees of freedom
16 DOF
Transmission mechanism
Backlash-free transmission

Mobility & Payload

Hand Payload
15 kg

Mechanical and mounting

Hand weight
0.84 kg

Electrical and integration

Dexterous Hand
Bionic five-finger dexterous hand
Dexterous Hand Model
Mozart
End-Effector
Robotic end-effector dexterous hand
Joint Type
6 active joints and 10 passive joints
Operating voltage
12–48 V

Sensors

Force/Torque Sensor
3D force/tactile sensing
Sensors
Five-finger 3D force/tactile sensing
Tactile Sensor
3D tactile sensing

Battery and Runtime

Power Supply
DC 12–48 V

Interaction and Communication

Communication
EtherCAT
System Response Time
≤0.01 s
Tactile Feedback
Recognizes grip force, slip, and surface texture

Development and Expansion

Integration Interface
EtherCAT industrial bus interface

Commercial Status

Status
Unknown
Price
Unknown
Release Date
Unknown
Submit a source or correction