
 Zhongke Guiji (Nanjing) Robot Co., Ltd.
Casia Hand
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Release Date
Unknown
Country/Region
China
Latest parameter verificationLatest individual parameter check, not a full-model review or edit date.
2026-10-30
21 DOF
Active degrees of freedom
5
Finger count
Casia Hand-H is the research-oriented anthropomorphic model of the Casia Hand family. The developer institute distinguishes 21 actuation degrees of freedom from 25 joint degrees of freedom; the latter is not the active-axis count.
1 / 1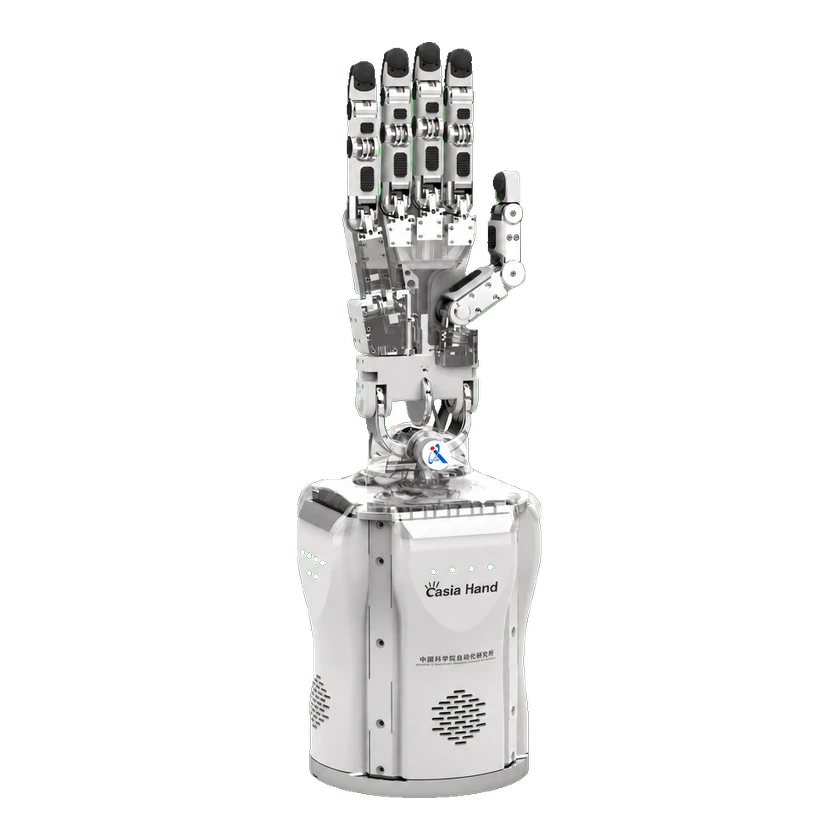
Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Degrees of freedom and drive
Finger count
5
Actuator count
21
Active degrees of freedom
21 DOF
The research institute distinguishes 21 actuation DOF from 25 joint DOF for the anthropomorphic class. The official company brochure identifies Hand-H as this class.
Total degrees of freedom
25 DOF
The research institute distinguishes 21 actuation DOF from 25 joint DOF for the anthropomorphic class. The official company brochure identifies Hand-H as this class.
Transmission mechanism
Tendon-driven
Mobility & Payload
Hand Payload
5 kg
Mechanical Structure
Dexterous Hand
Casia Hand
Dexterous Hand Model
Casia Hand-H
Sensors
Sensors
12×8 array fingertip tactile sensors
Tactile Sensor
12×8 array fingertip tactile sensors
Compute Platform
Software Algorithm
Deep-learning algorithms for perception, understanding, decision-making and dexterous manipulation
Development and Expansion
Teleoperation
Human-like dexterous teleoperation research
Commercial Status
Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Related Entities
No related products recorded yet.
Submit a source or correction