
 BXI Robotics
Joint Motors
- Output speed · No load
- 200 rpm
- Weight
- 0.5 kg
- Operating voltage · Nominal range
- 24–48 V
- Gear Ratio
- 19.5:1
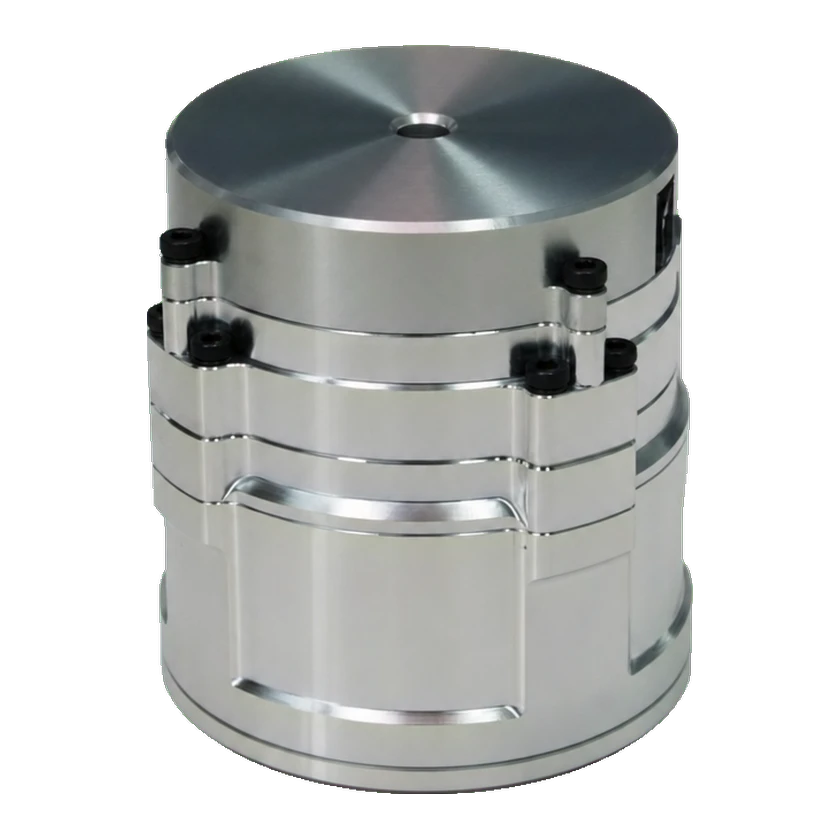
BXI5014-19 is a 0.5 kg integrated joint motor from BXI Robotics for humanoid neck, wrist and distal joints. It combines hollow-shaft planetary gearing, dual absolute encoders and a cross-roller bearing, with CAN/CAN-FD communication and MIT protocol compatibility. Pricing is available by inquiry.
Technical specifications
Values use consistent engineering units.
Output & transmission
- Output torque · Theoretical rated
7 N·m
Manufacturer labels this table theoretical; not eligible for confirmed rated-torque filtering.
- Output torque · Theoretical peak
25 N·m
- Output speed · No load
200 rpm
- Output speed · Theoretical rated
100 rpm
- Gear Ratio · Total
19.5:1
Dimensions & installation
- Weight · Manufacturer reportedNominal body specification
0.5 kg
- Axial length · Manufacturer reported
66.5 mm
- Hollow bore diameter · Manufacturer reported
6 mm
- Mounting interface · Manufacturer reportedMounting
Ø64 mm
Electrical
- Operating voltage · Nominal rangeDC power input
24–48 V
- Operating current · Theoretical peakMotor phase
30 A
- Operating currentMotor phase
17 A
Encoders & feedback
- Encoder type · Manufacturer reportedOutput-side encoder
Inductive
- Encoder type · Manufacturer reportedMotor-side encoder
Magnetic
- Encoder turn mode · Manufacturer reportedOutput-side encoder
Absolute
- Encoder turn mode · Manufacturer reportedMotor-side encoder
Absolute
- Encoder resolution · Manufacturer reportedMotor-side encoder
16 bit
Communication & control
- Communication interface · Manufacturer reported
CAN / CAN-FD
- Communication protocol · Manufacturer reported
MIT protocol
- Control mode · Manufacturer reported
Mixed torque / velocity / position control
Construction & components
- Transmission mechanism · Manufacturer reported
Planetary
- Motor integration · Manufacturer reportedMotor
Integrated
- Reducer integration · Manufacturer reportedReducer
Integrated
- Encoder integration · Manufacturer reportedEncoder
Integrated
Open source & build resources
Software
Not verifiedThere is not enough verified evidence to establish this dimension.
Hardware design
Partial hardware documentationOfficial BXI5014-19 page with an external dimension drawing, mounting holes and CAN/CANFD interface specifications. Drawing copyright is reserved; no open reuse grant was confirmed. This is integration reference, not editable manufacturing CAD, PCB source or firmware. Verify the delivered revision.
View explanationBuild resources
Not verifiedThere is not enough verified evidence to establish this dimension.
| Type | Resource | License | Applicable version | Open |
|---|---|---|---|---|
| Hardware | BXI5014-19 dimension drawing and interface specifications GitHub · bxirobotics/BXI_Wiki Official BXI5014-19 page with an external dimension drawing, mounting holes and CAN/CANFD interface specifications. Drawing copyright is reserved; no open reuse grant was confirmed. This is integration reference, not editable manufacturing CAD, PCB source or firmware. Verify the delivered revision. | — | BXI5014-19 | Open GitHub |
| Guide | BXI CAN/CANFD communication integration guide GitHub · bxirobotics/BXI_Wiki Official command/response frames, MIT-mode packing and multi-motor broadcast documentation for BXI actuators. Match parameter ranges to the actual motor configuration. MIT here names a control protocol, not an MIT software license. No open document license or firmware source confirmed; not a motor assembly tutorial. | — | BXI5014-19 | Open GitHub |
Commercial Status
Related Entities
No related products recorded yet.