
 AIDIN ROBOTICS Inc.
AIDIN-Hand Gen1
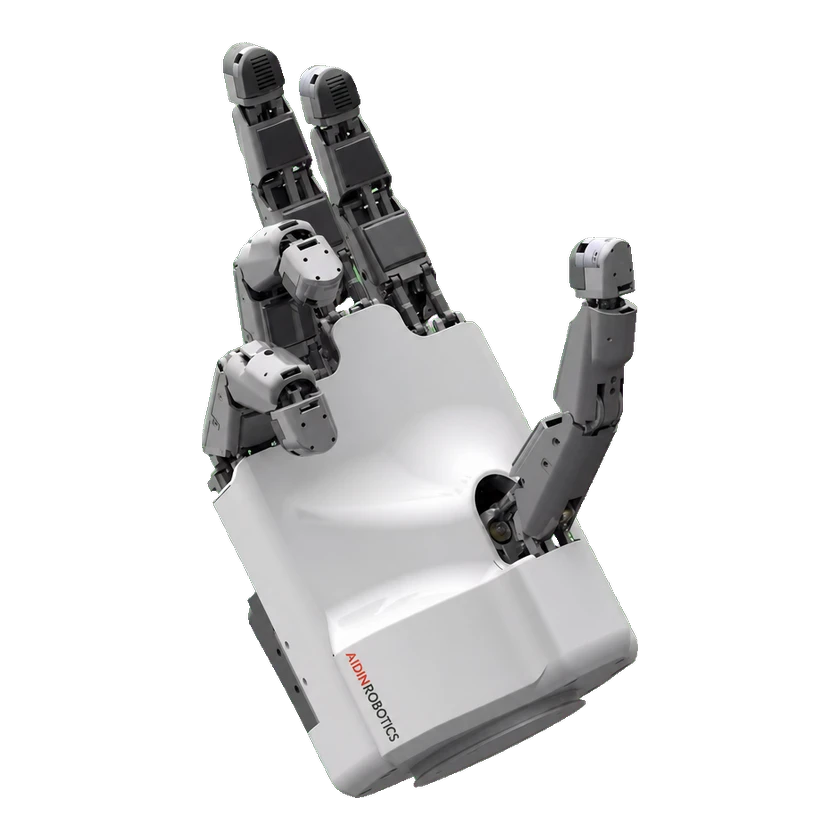
AIDIN-Hand Gen1 is a five-finger research robotic hand with a linkage-driven 15-DoF design and six-axis force/torque sensors at the fingertips. The manufacturer catalog lists 1.3 kg hand mass and 15 kg payload. Gen2’s 16-DoF design and ATT tactile sensing are separate generation-specific specifications.
Technical specifications
Model specifications are shown below. Configuration-specific values are listed separately; missing data does not mean zero or unsupported.
Physical Specifications
The older AIDIN Hand catalog photograph shows five fingers; its table lists five fingertip force/torque sensors. The next-generation ATT sensing video on the mixed product page is not evidence for Gen1 tactile sensing.
The manufacturer’s generation comparison explicitly identifies Gen1 as15 DoF and Gen2 as16 DoF. This corroborates the older15-DoF catalog platform; it does not establish a separate total-joint or actuator count.
The source lists 291×112×120 mm without naming the axes or a pose reference frame. The correspondence of these dimensions to individual axes remains unconfirmed pending a dimensioned drawing.
The source lists 291×112×120 mm without naming the axes or a pose reference frame. The correspondence of these dimensions to individual axes remains unconfirmed pending a dimensioned drawing.
The source lists 291×112×120 mm without naming the axes or a pose reference frame. The correspondence of these dimensions to individual axes remains unconfirmed pending a dimensioned drawing.
The catalog, PDF page12 (printed22–23), reports15 hand DoF without separating active, passive or coupled degrees of freedom. The historical15 is retained as reported, not independently verified as total. Do not replace it with20 merely from the communication manual’s joint-angle array.
The older15-DoF AIDIN Hand catalog explicitly describes a link-driven mechanism. The manufacturer generation comparison distinguishes that platform from the16-DoF Gen2; no gear ratio or zero-backlash claim is inferred.
Mobility & Payload
The manufacturer’s generation comparison attributes15 kg payload to Gen1, versus20 kg for Gen2. Grasp object, pose and test conditions are unspecified; this is not a fingertip force.
Mechanical and mounting
Mechanical Structure
Sensors
The catalog lists five miniature six-axis force/torque sensors at the fingertips. Distributed tactile or pressure sensing remains unconfirmed. Other integration documents use different sensor model labels, which do not establish a uniform sensor model for every Gen1 hand.
Software and resources
Interaction and Communication
Development and Expansion
Commercial Status
Related Entities
No related products recorded yet.