
 Wuji Technology
Wuji Hand
Price
Unknown
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Purchase
Not disclosed
Release Date
Unknown
Country/Region
Unknown
Last Verified
2026-09-12
20 DOF
Active degrees of freedom
20
Mechanical joint count
Excluding cables: 0.57–0.59 kg
Weight
5
Finger count
Wuji Hand is a five-finger dexterous robot hand with 20 active DOFs, direct-drive joints, FOC control and dual-encoder feedback for manipulation research and robot integration.
1 / 1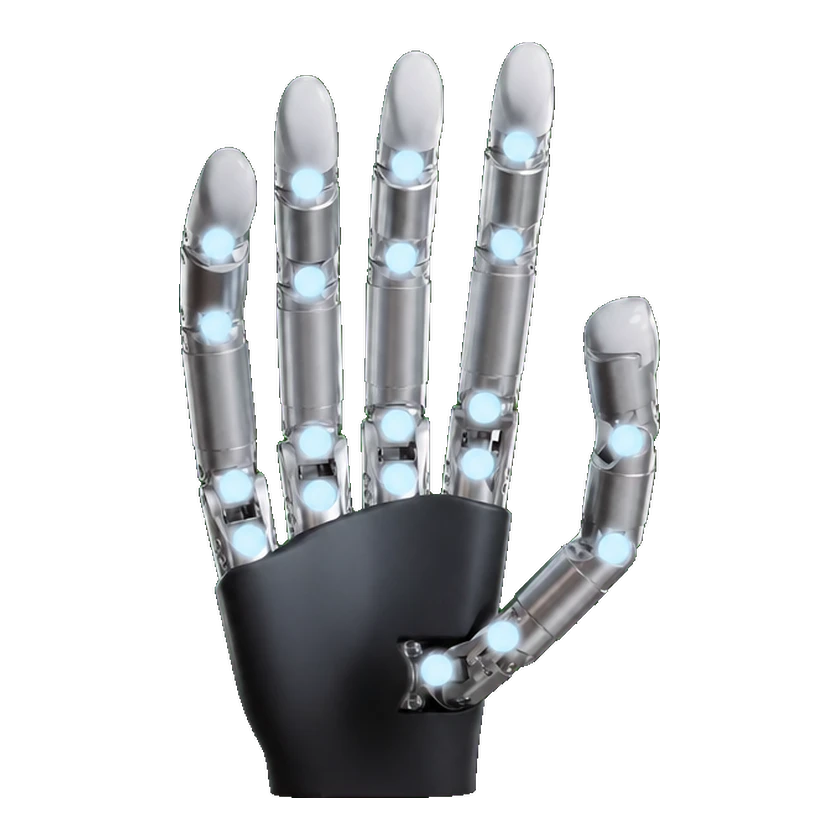
Hardware Specification
Physical Specifications
Actuator technology
Brushless motors
Active degrees of freedom
20 DOF
Ingress Protection (IP)
IP40
Mechanical joint count
20
Materials
Aluminum alloy shell
Total degrees of freedom
20 DOF
Transmission mechanism
Self-locking rotary direct drive
Mechanical and mounting
Depth
5.0 cm
Dimension reference frame
201 mm × 75 mm × 50 mm reference frame
Length
20.1 cm
Maximum grip diameter
10.0 cm
Mounting interface
Adapter for robot-arm flange mounting
Weight
Excluding cables: 0.57–0.59 kg
Width
7.5 cm
Mechanical Structure
Dexterous Hand
Biomimetic dexterous hand
Joint Sensor Type
Dual-encoder feedback
Joint Type
Serial direct-drive rotary joints
Load Cycles
Idle gripping: ≥300000
Operating voltage
12–20 V
Rated power
Not disclosed
Compute Platform
Repeatability
1 mm
Software Algorithm
FOC vector control
Interaction and Communication
Communication
USB 2.0
External Port
USB-C device port
Development and Expansion
Operating Modes
Position control
Payload Power Supply
12 V 20 A adapter; 420 W peak for 10 ms
Secondary Development (SDK)
Wuji SDK
Commercial Status
Status
Unknown
Price
Unknown
Release Date
Unknown
Related Entities
Robots related to “Wuji Hand”
Submit a source or correction