
 OYMotion
ROHand
Price
Price not disclosed
Type
Components · Dexterous Hands
Status
Unknown
Availability
Not disclosed
Purchase
Contact manufacturer
Release Date
Unknown
Country/Region
China
Last Verified
2026-09-12
6 DOF
Active degrees of freedom
11
Mechanical joint count
Including wrist: 0.452–0.462 kg
Weight
ROHand is a dexterous robotic hand family by OYMotion.
1 / 1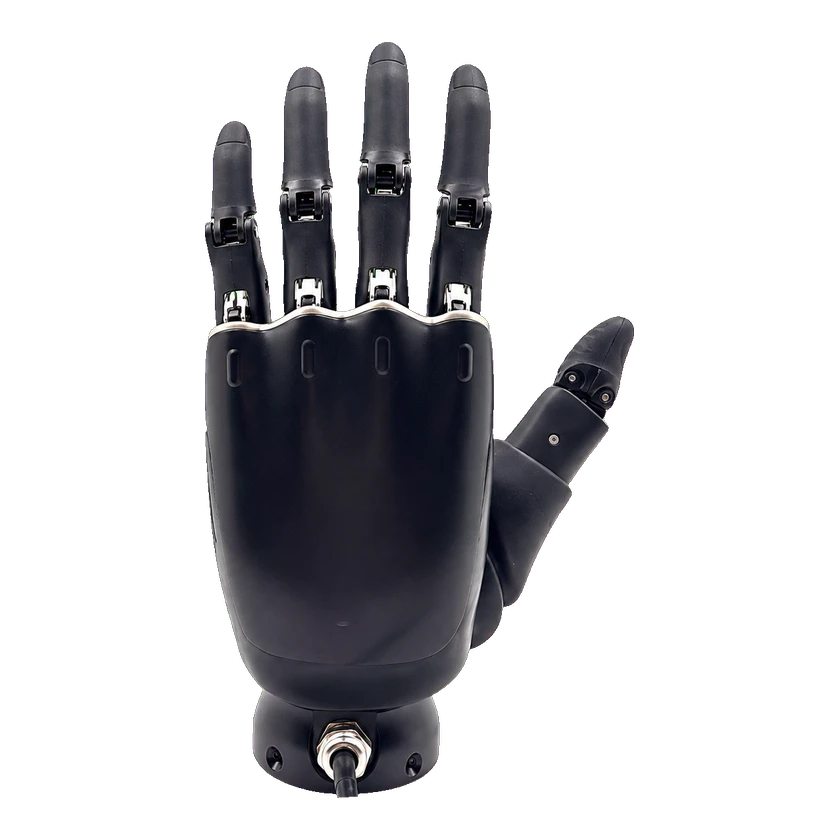
Hardware Specification
Degrees of freedom and drive
Actuator count
6
Active degrees of freedom
6 DOF
Ingress Protection (IP)
Not waterproof; prevent liquid ingress
Mechanical joint count
11
Materials
Aluminum alloy, zinc alloy, stainless steel, silicone and plastic
Mobility & Payload
Hand Payload
Passive load, four fingers flexed: 25 kg
Hand Payload
Passive load, one finger flexed: 8 kg
Hand Payload
Passive load, one finger extended: 5 kg
Mechanical and mounting
Height
Middle fingertip to wrist: 16.9 cm
Height
Thumb tip to wrist: 9.7 cm
Length
Thumb length: 11.0 cm
Weight
Including wrist: 0.452–0.462 kg
Width
Palm width: 7.5 cm
Mechanical Structure
Joint Motion Range
Thumb side opening: 0–31 °
Joint Motion Range
Thumb-to-palm opening: 0–50 °
Joint Motion Range
Thumb lateral rotation: 0–90 °
Rated power
48 W
Compute Platform
Software Algorithm
Built-in PID motor control
Reliability and environment
Operating temperature
-10–40 °C
Interaction and Communication
Communication
UART, RS485 or CAN depending on interface version; SerialCtrl, ModBus-RTU or CAN protocol
Development and Expansion
Mounting Dimensions
Wrist diameter: 4.9 cm
Secondary Development (SDK)
SDK for ROS and ROS 2 platforms
Commercial Status
Status
Unknown
Price
Price not disclosed
Release Date
Unknown
Related Entities
Robots related to “ROH-LiteS001”
Submit a source or correction